本指标通过监测边缘梯度的演化,评估生成视频中细节稳定性。成功产生的数值结果为 official:会进入 quality 维度和公开 leaderboard 向量。该实现采用向量化 Tenengrad 方法:分别计算水平方向(Gx)与竖直方向(Gy)Sobel 梯度的绝对值之和,构造二维清晰度向量以刻画纹理方向特征:
gt=(∑∣Gx∣∑∣Gy∣)(6)
其中 Gx,Gy 为第 t 帧灰度图经 3×3 Sobel 算子得到的梯度响应。
引入噪声感知熔断机制以区分真实细节与高频伪影:记 nt 为第 t 帧 BRISQUE 噪声分数,τ 为噪声阈值;当连续 5 帧满足 nt>τ 时,触发状态 Itrig=1。融合惩罚逻辑 M 将纹理相似度与熔断状态结合(相似度 S(⋅,⋅) 采用余弦内积,定义同式 (3)):
BRISQUE 对零方差帧没有定义。实现会给这类帧赋予配置中的最差值 brisque_bad,并继续把它计入聚合,因此纯色或黑帧坍缩会受到惩罚,而不会作为缺失分数被静默排除。
M(xt)={S(gt,g1),clip(1−S(gt,g1),0,0.2),Itrig=0∧nt<τotherwise(11)
对低–中分段细节增强,采用上凸对数变换 L(⋅)(x∈[0,1],避免无意义对数并归一化):
L(x)=ln(1+k)ln(1+k⋅x),k>0(10)
其中 k 控制上凸程度,视觉领域常用 k∈[10,20];分子保证 x=0⇒L(x)=0,分母保证 x=1⇒L(x)=1。
时序聚合采用归一化指数衰减权重 w^(d)(定义同亮度一致性指标式 (5),d∈[1,T−1] 为帧距)。综合得分为:
SSharpness=d=1∑T−1w^(d)⋅L(M(xd+1))(12)
其中 S(gt,g1) 为第 t 帧与首帧清晰度向量的余弦相似度。该机制可在区分真实细节与高频噪声的同时,对系统性视觉崩塌施加惩罚。
Audit manifest: docs/assets/metric_examples/curated_same_case_manifest.json.
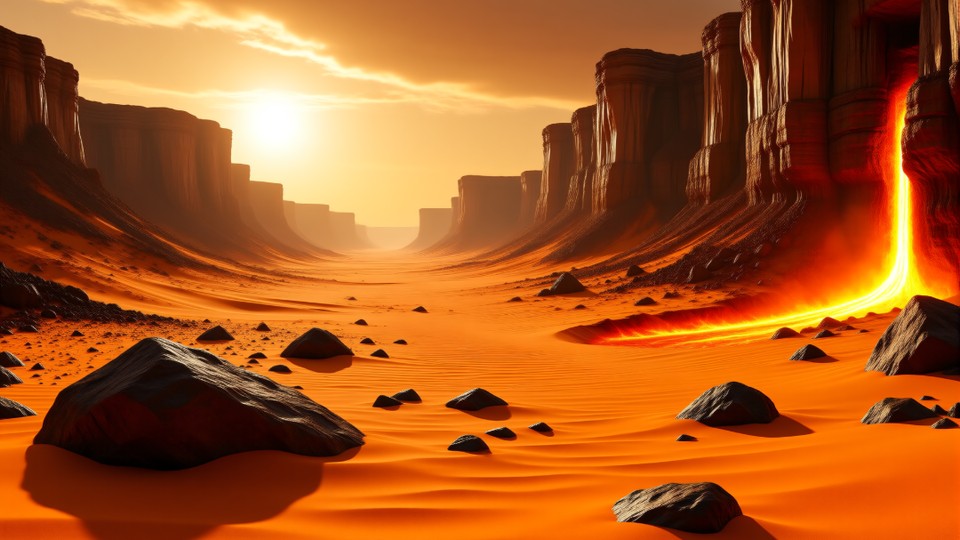 输入图像
输入已核验 · 同一 benchmark case · gap 0.8467
image_static_photorealistic_terrestrial_landscape_0152
套件: image_static场景: photorealistic / outdoor / terrestrial_landscape
基准 prompt target
Camera pan right. A desert canyon with rock formations, distant horizon, and sand.
prompt source: prompt_target
两条视频的首帧都已通过与展示输入的几何匹配核验;高低标签只比较当前 metric。
较高指标分分数 0.9725
较低指标分分数 0.1258
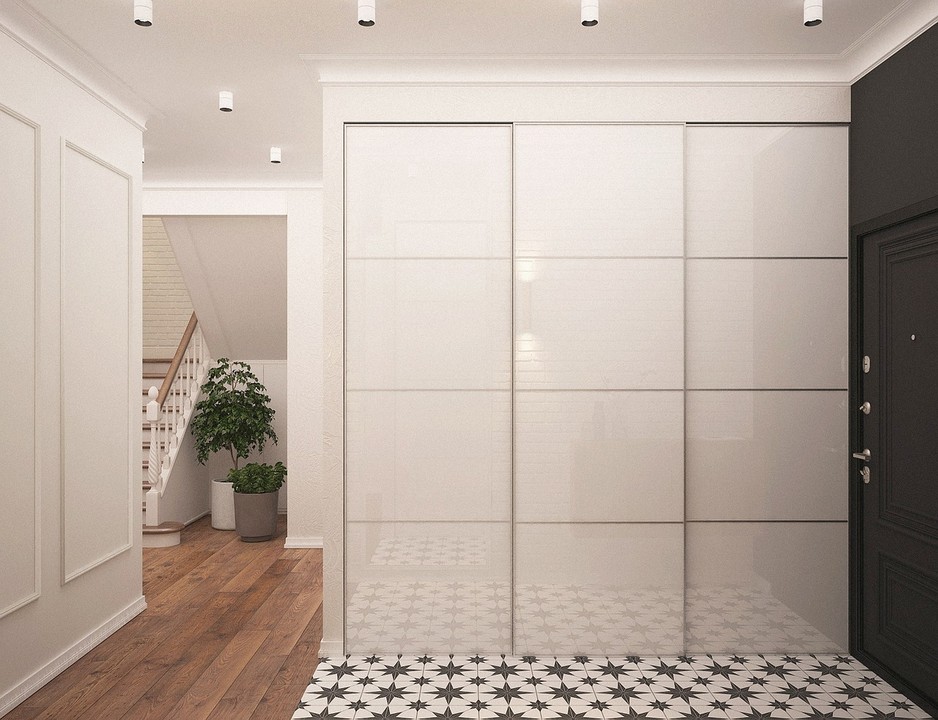 输入图像
输入已核验 · 同一 benchmark case · gap 0.8771
image_static_photorealistic_passageways_0128
套件: image_static场景: photorealistic / indoor / passageways
基准 prompt target
Camera pan left. A modern hallway with potted plant, artwork, and hallway extension.
prompt source: prompt_target
两条视频的首帧都已通过与展示输入的几何匹配核验;高低标签只比较当前 metric。
较高指标分分数 0.9749
较低指标分分数 0.0978
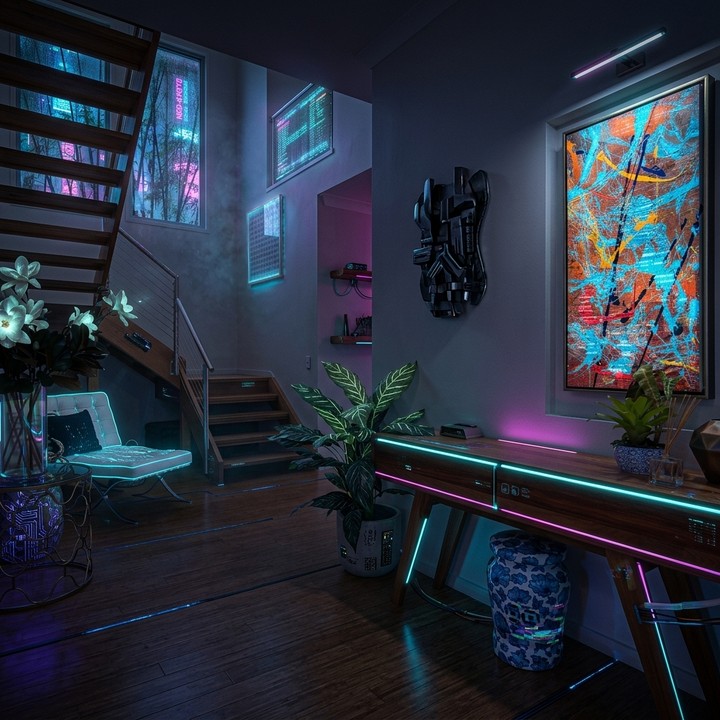 输入图像
输入已核验 · 同一 benchmark case · gap 0.8513
image_static_stylized_living_spaces_0096
套件: image_static场景: stylized / indoor / living_spaces
基准 prompt target
Camera pan right. A modern living space with hallway, neon lights, and artwork.
prompt source: prompt_target
两条视频的首帧都已通过与展示输入的几何匹配核验;高低标签只比较当前 metric。
较高指标分分数 0.9514
较低指标分分数 0.1001

