跳转到内容

MEt3R 一致性

2026-09-10:当前实现为 met3r_paper_consecutive_symmetric_v1。旧参考图/anchor 和 reference_all_anchors_v2 成绩不属于论文配对协议,不能与本版混用。CPU 实现测试不等于预训练模型的 GPU 数值验收。

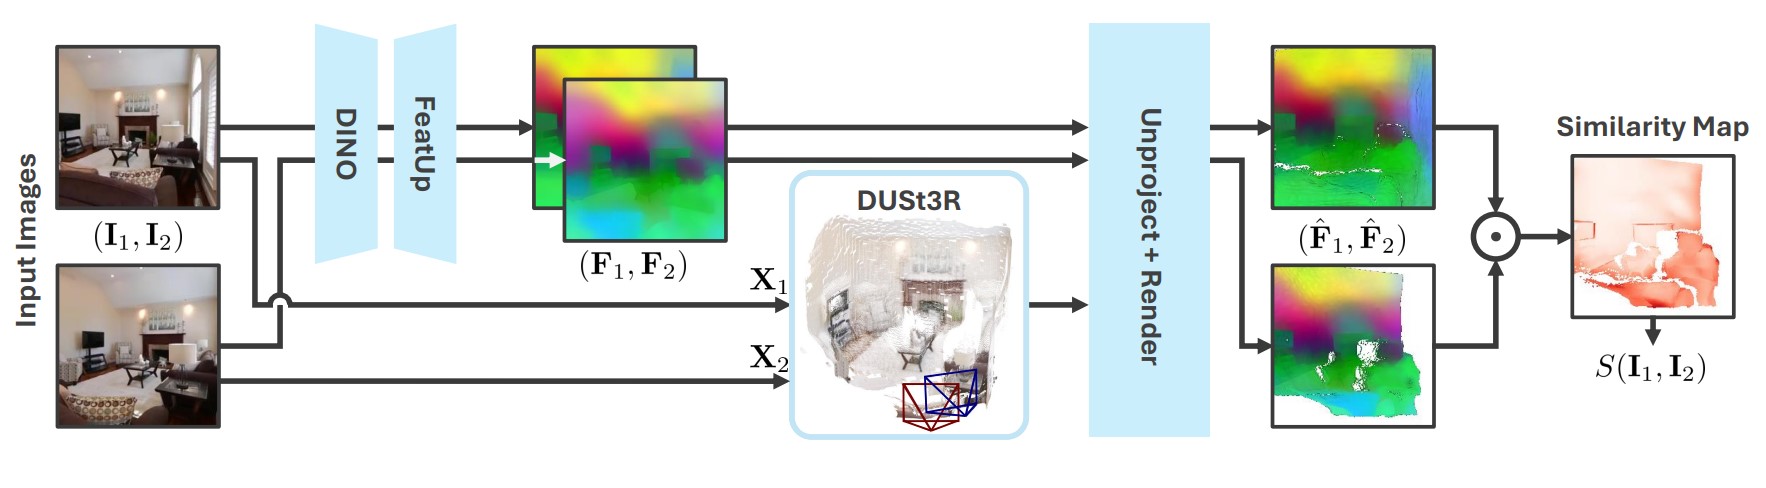
met3r_consistency 按 MEt3R,CVPR 2025 的双图定义计算:DUSt3R 重建、DINO16 特征、FeatUp 上采样、有效重叠区域内的余弦不相似度。直接调用作者未修改的实现,固定 commit 为 ee0e1752898559e1a3e85e2e151d3edeb9b55f73。

对于每对相邻生成帧 (I_t, I_{t+1}),分别调用官方 scorer 计算两个方向,再取平均,对应论文式 (1);视频分数再对所有相邻帧对取均值。不再拿输入原图或参考视频与预测帧比较,也不使用全局随机 anchor。

MEt3R 方法概览
MEt3R 使用多视角生成图像之间的几何和表征一致性来度量生成结果的 multi-view consistency。

论文 raw 分数范围为 [0, 2],越低越好。榜单对每个视频直接计算 clip(1 - raw/2, 0, 1),再平均并乘 100,不反推 error_ref 均值。报告里的 normalized 可保留旧兼容变换;最终展示值是 score_details.published_score。无法对应到逐视频报告的旧成绩保留历史已发布汇总,并在网页悬停说明,不能称为已重算的 raw/scored 均值。

零重叠时保留官方代码返回的有限值并记录诊断信息,不再替换为最差分、不按 overlap 删样本、不修补 NaN。空重叠返回有限零值是上游实现的边界行为,不表示两帧已被证明一致。解码失败、非法 mask 或非有限分数使本条测量失败。

视频输入适配明确为:完整预测文件、原生步长 1,不做时间重采样、不插入 conditioning image;RGB 以带抗锯齿的双线性插值缩放到约 256² 像素,理想高度取最近的 32 像素、宽度取最近的 16 像素(等距向上取整)。官方 FeatUp 的 DINO patch embedder 在 patch 网格高度为奇数时会裁掉一行一列,却不相应调整位置编码;偶数行网格可避开这一不兼容路径,不改官方代码或权重,原先已兼容的缩放尺寸保持不变。运行结果将该约定记录为 area_256_squared_height32_width16_bilinear_antialias,渲染尺寸随适配后的宽高变化。论文规定约 256² 和保持宽高比,但没有公开完全相同的整数取整规则;这属于已记录的输入适配约定,不能声称逐位复现作者的视频预处理。论文特定数据集使用的 48/80 视角限制,不静默截取到 WorldAtlas 视频上。

这里显式选择论文主体的 DUSt3R 路径,而不是新版本官方库默认的 MASt3R。该指标拒绝非 FeatUp 配置;缺少 FeatUp 或 DUSt3R 依赖时明确报错,不回退到 bilinear 特征。发布前仍需新依赖锁和预训练 GPU 直接调用对照。

下方历史案例仅为追溯保留,使用了已废止的配置/配对协议,不代表当前新版成绩。

以下代表性对比从 2026-07-17 正式 image_static MEt3R 快照中筛选,并经过 frame strip 人工复核。每个展示固定一个 benchmark case——相同的输入图像与 eval-plan prompt target——并比较两个 prediction 视频。MEt3R 归一化分数越高越好,raw distance 越低越好。

不同 adapter 的实际 conditioning 可能不同,因此这些是 metric 诊断案例,不是受控的模型排名对比。精确路径、哈希、overlap 值及 report 来源见机器可读 MEt3R 清单。

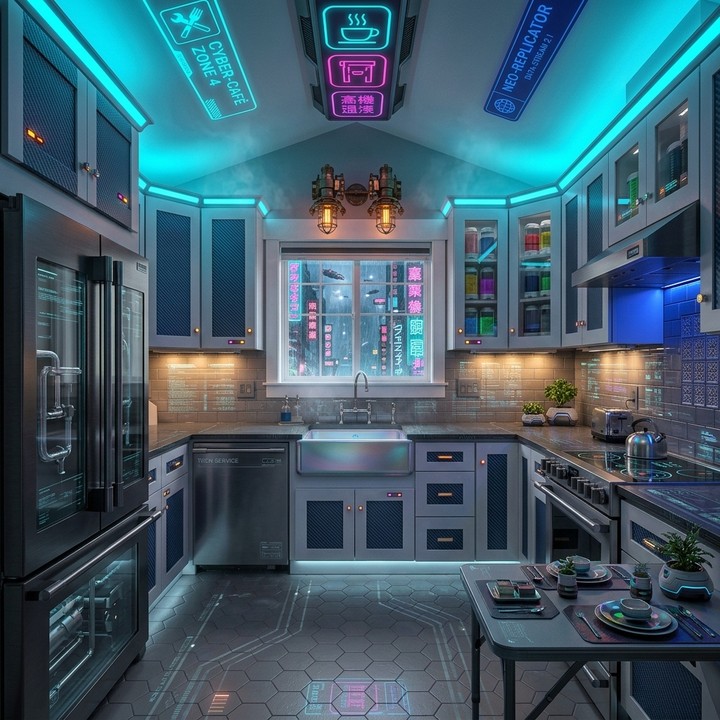
输入图像: image_static_stylized_dining_spaces_0115
输入图像
Case 1 · 可见结构漂移会降低多视角一致性

image_static_stylized_dining_spaces_0115

image_staticstylized / indoor / dining_spaces
Benchmark prompt target

Camera pan right. A futuristic dining area with dining table, chairs, and digital displays. Camera pull out. A futuristic living room with sofa, digital screens, and neon accents. Camera move right. A futuristic balcony with neon signs, railing, and skyscrapers.

Output A 按目标场景序列推进,在评测 anchor 处仍保持清晰、稳定的结构;Output B 出现半透明重复轮廓与扭曲的房间几何,有效 overlap 下降,MEt3R raw distance 随之升高。

Model result videos will be available with the ModelScope release. / 模型推理视频将在 ModelScope 方案上线后提供。

Output AMEt3R:0.9823 normalized · 0.0354 raw · 0.9388 overlap

Model result videos will be available with the ModelScope release. / 模型推理视频将在 ModelScope 方案上线后提供。

Output BMEt3R:0.5737 normalized · 0.8527 raw · 0.4778 overlap
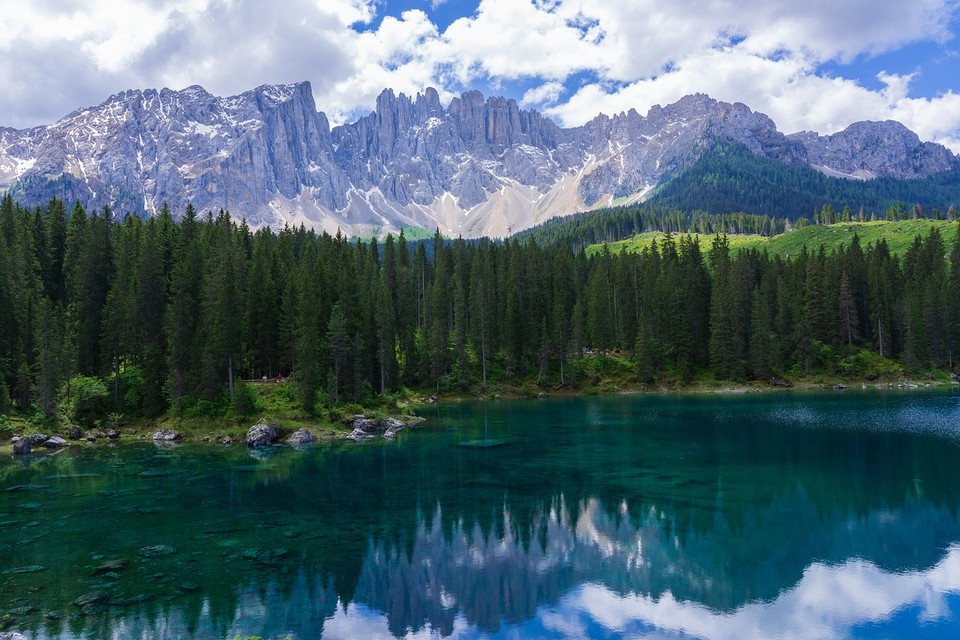
输入图像: image_static_photorealistic_aquatic_landscape_0006
输入图像
Case 2 · 视角突变导致 anchor overlap 过低

image_static_photorealistic_aquatic_landscape_0006

image_staticphotorealistic / outdoor / aquatic_landscape
Benchmark prompt target

Camera pull out. A forest edge with rocky shore and trees. Camera pan right. A forest edge with open meadow, grassy field, and distant hills. Camera move right. A hiking trail with path through trees and small clearing.

Output A 逐步改变视角,同时保留山体、林线和湖岸结构;Output B 更突然地跳向林间小径。在评测 anchor 上,有效投影 overlap 降至 0.0529,MEt3R raw distance 因此升高。

Model result videos will be available with the ModelScope release. / 模型推理视频将在 ModelScope 方案上线后提供。

Output AMEt3R:0.9559 normalized · 0.0883 raw · 0.8652 overlap

Model result videos will be available with the ModelScope release. / 模型推理视频将在 ModelScope 方案上线后提供。

Output BMEt3R:0.7167 normalized · 0.5666 raw · 0.0529 overlap

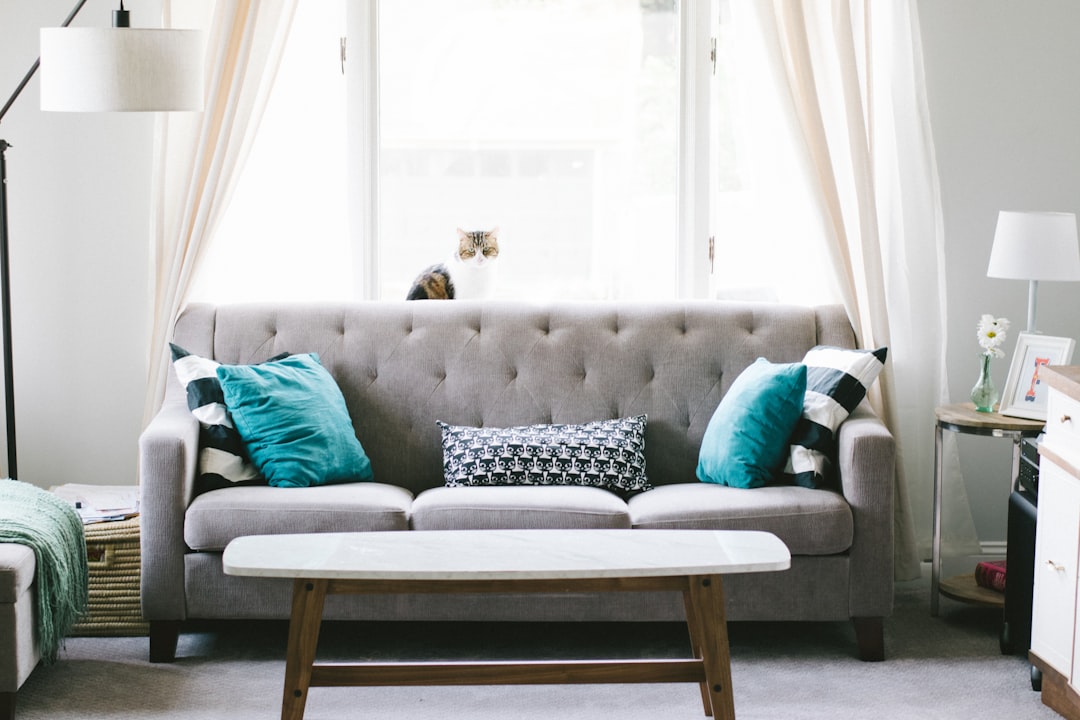
输入图像: image_static_photorealistic_living_spaces_0140
输入图像
Case 3 · 不同运动幅度下的 anchor 一致性接近

image_static_photorealistic_living_spaces_0140

image_staticphotorealistic / indoor / living_spaces
Benchmark prompt target

Camera push in. A living room with sofa, bookshelf, and books.

Output A 的运动较小;Output B 做了更大幅、平滑的相机运动并露出书架。在被评估的 MEt3R anchor 上,两者都保持了较高的特征与投影视角一致性,因此得分非常接近。

Model result videos will be available with the ModelScope release. / 模型推理视频将在 ModelScope 方案上线后提供。

Output AMEt3R:0.9957 normalized · 0.0087 raw · 0.5406 overlap

Model result videos will be available with the ModelScope release. / 模型推理视频将在 ModelScope 方案上线后提供。

Output BMEt3R:0.9972 normalized · 0.0055 raw · 0.5455 overlap

BibTeX
@inproceedings{asim25met3r,
title = {MEt3R: Measuring Multi-View Consistency in Generated Images},
author = {Asim, Mohammad and Wewer, Christopher and Wimmer, Thomas and Schiele, Bernt and Lenssen, Jan Eric},
booktitle = {IEEE/CVF Computer Vision and Pattern Recognition ({CVPR})},
year = {2025},
}