检验回访帧的特征对应是否符合 ViPE 估计的相机几何。这是位姿/特征一致性代理指标,不是独立三维真值验证。
相对位姿为 Tb−1Ta=(R,t)。非零基线使用单位平移方向,避免单目平移任意尺度影响极线计算:
E=[∥t∥t]×RF=Kb−⊤EKa−1(1)
spair=fpos⋅2exp(−eepi/τepi)+exp(−erep/τrep)(2)
对 SIFT 匹配进行三角化,要求点在两台相机前方;fpos 的分母为全部匹配,因此相机后方的完美重投影不能拿满分。默认像素尺度为 τepi=4 px、τrep=8 px。有限三角化点不足时不给数字。
零/近零平移基线下 E 退化,不代表成功。此时使用位姿导出的旋转单应 H=KbRKa−1 和双向传递误差,得分为 exp(−e/τrep),极线误差为不适用;不从这些匹配重新拟合 H。
越高越好。整段得分对满足支持度要求的可测帧对取平均。return gate 未通过也继续评分;没有严格回访对时使用最近位姿回退配对,并记录 gate 状态与配对来源。缺失测量与测得零分有区别。近零基线容差只是数值门限,未做物理标定;特征重叠及估计器可靠性构成测量限制。后端为 sift_epipolar。
Audit manifest: docs/assets/metric_examples/longseq_memory_60s_examples_20260909.json.
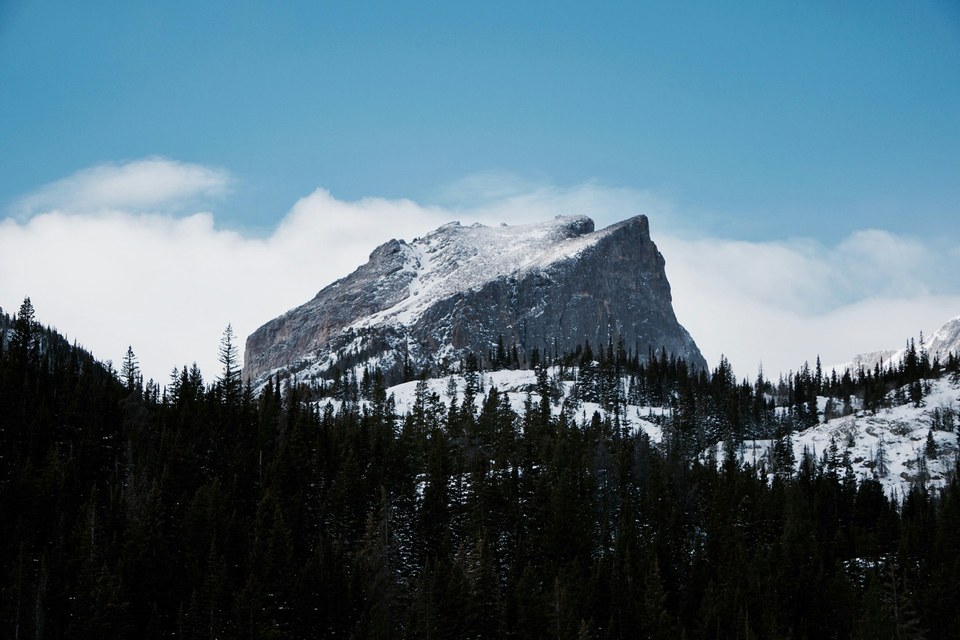 输入图像
60 秒 memory_loop · 同一 benchmark case · gap 0.8982
memory-dolly_loop-memory_pool_065
套件: memory_loop场景: photorealistic / outdoor / terrestrial_landscape
基准 prompt target
Move the camera forward through the scene, then back to where it started.
prompt source: memory_loop_prompt
较好的回环在返回后仍满足双视角几何解释;较差的回环布局与对应关系已经对不上。
较高指标分分数 0.8982 · official
较低指标分分数 0.0000 · official
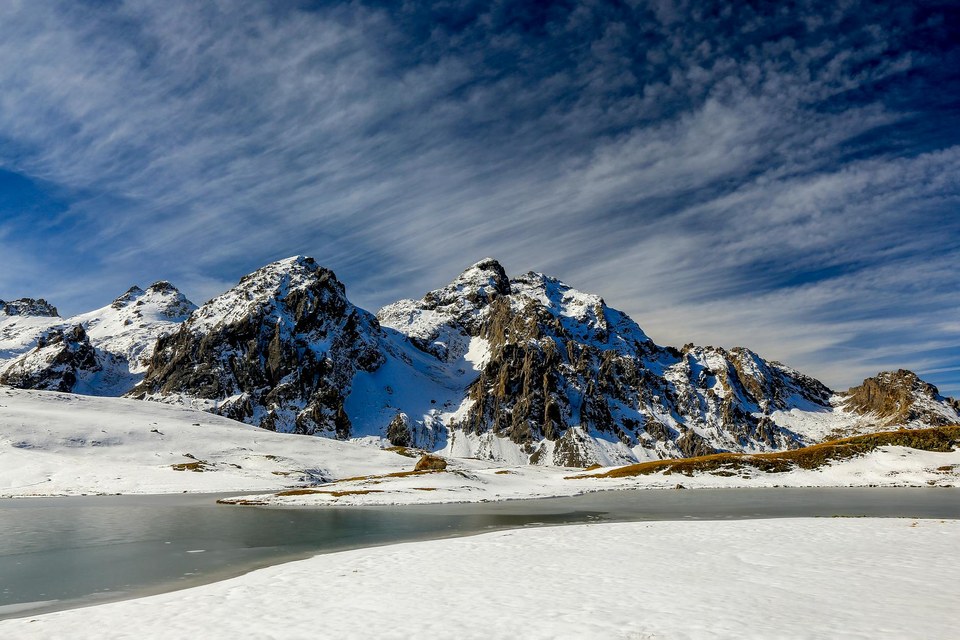 输入图像
60 秒 memory_loop · 同一 benchmark case · gap 0.9150
memory-double_yaw_loop-memory_pool_137
套件: memory_loop场景: photorealistic / outdoor / terrestrial_landscape
基准 prompt target
Turn away and back to the start twice in a row.
prompt source: memory_loop_prompt
较好的回环在返回后仍满足双视角几何解释;较差的回环布局与对应关系已经对不上。
较高指标分分数 0.9151 · official
较低指标分分数 0.0001 · official
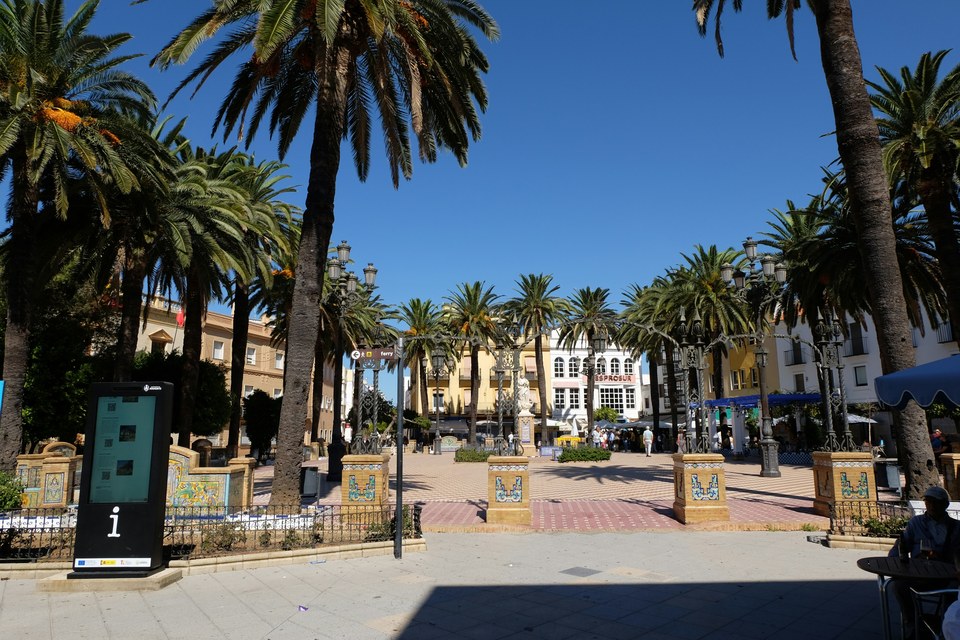 输入图像
60 秒 memory_loop · 同一 benchmark case · gap 0.9203
memory-yaw_loop_360-memory_pool_028
套件: memory_loop场景: photorealistic / outdoor / city
基准 prompt target
Rotate the camera a full turn in place and come back to the starting view.
prompt source: memory_loop_prompt
较好的回环在返回后仍满足双视角几何解释;较差的回环布局与对应关系已经对不上。
较高指标分分数 0.9203 · official
较低指标分分数 0.0000 · official
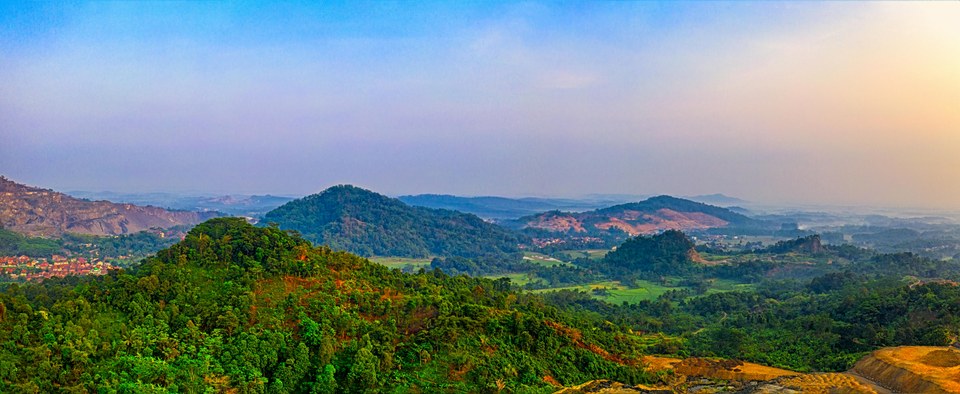 输入图像
60 秒 memory_loop · 同一 benchmark case · gap 0.9014
memory-yaw_loop_180-memory_pool_377
套件: memory_loop场景: photorealistic / outdoor / verdant_landscape
基准 prompt target
Turn the camera to the right, then turn back to the starting view.
prompt source: memory_loop_prompt
较好的回环在返回后仍满足双视角几何解释;较差的回环布局与对应关系已经对不上。
较高指标分分数 0.9014 · official
较低指标分分数 0.0000 · official
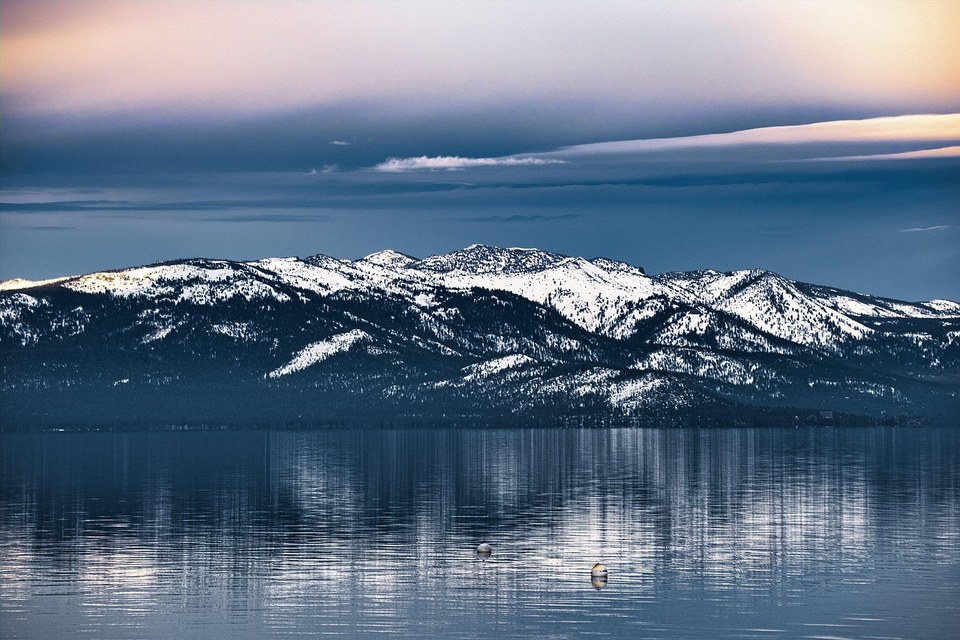 输入图像
60 秒 memory_loop · 同一 benchmark case · gap 0.8918
memory-dolly_loop-memory_pool_352
套件: memory_loop场景: photorealistic / outdoor / aquatic_landscape
基准 prompt target
Move the camera forward through the scene, then back to where it started.
prompt source: memory_loop_prompt
较好的回环在返回后仍满足双视角几何解释;较差的回环布局与对应关系已经对不上。
较高指标分分数 0.8918 · official
较低指标分分数 0.0000 · official

