reconstruction_consistency 是公开指标 geometric_consistency 与 photometric_consistency 共用的计算单元。Depth-Anything-3(DA3)从预测帧恢复深度与相机位姿,构建彩色点云,并评估这些点跨视角重投影的一致性。它只依赖 prediction 本身,不需要 reference video 或几何真值。
与旧版 World-R1 的 Gaussian splat + LPIPS S_recon 不同,也与 WorldLens 中对预渲染 reconstruction 视频做光流 warp + LPIPS 的 novel_view_consistency 不同,本指标直接在预测帧上运行 DA3(infer_gs = false),由深度图、估计位姿与 RGB 帧构建点云,再检验跨帧重投影是否与预测深度一致。因此它衡量的是重建路径下的几何自洽性 ,而不是 prompt following、感知质量或 reference-video fidelity。
对每一帧,backend 将其他帧观测到的点重投影到当前视角,并计算几何误差(重投影深度与预测深度图的 median relative depth error)与光度误差(z-buffer 渲染颜色相对原始帧的 PSNR)。headline 分数为几何一致性:
g e o m e t r i c _ c o n s i s t e n c y = 1 1 + m e a n ( v a l i d _ g e o _ e r r o r s ) (1) \mathrm{geometric\_consistency}
=
\frac{1}{1 + \mathrm{mean}(\mathrm{valid\_geo\_errors})}
\tag{1} geometric_consistency = 1 + mean ( valid_geo_errors ) 1 ( 1 ) 光度 PSNR 采用标准映射:
p h o t o m e t r i c _ c o n s i s t e n c y = 1 − 10 − P S N R / 20 . (2) \mathrm{photometric\_consistency} = 1 - 10^{-\mathrm{PSNR}/20}.
\tag{2} photometric_consistency = 1 − 1 0 − PSNR /20 . ( 2 ) 两个公开指标都落在 [ 0 , 1 ] [0, 1] [ 0 , 1 ] 越高越好 ,并分别聚合。
案例按 Geometric Consistency 与 Photometric Consistency 各选三组;高分侧均有明显运动。每组分数只对应标注的指标。
Audit manifest: docs/assets/metric_examples/missing_pages_examples_20260824.json.
输入图像
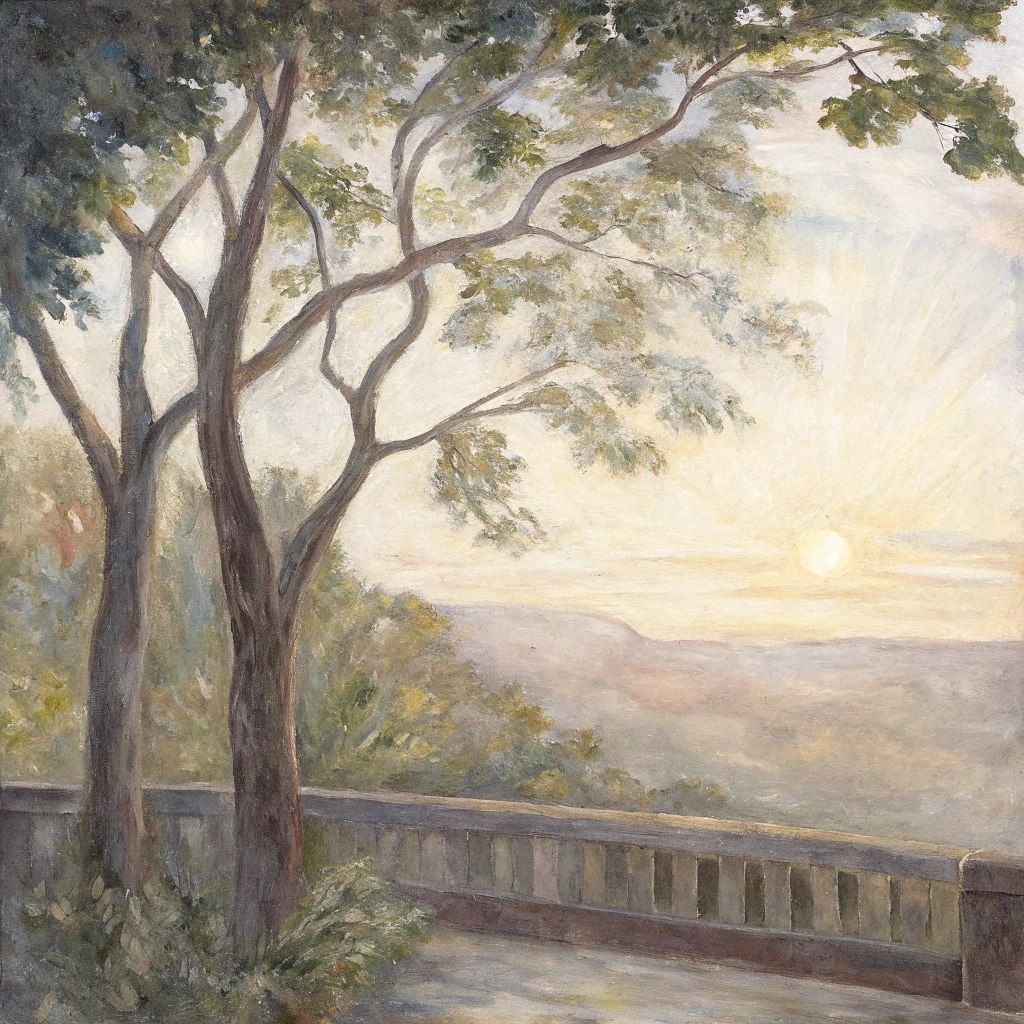
输入已核验 · 同一 benchmark case · gap 0.8063
image_static_stylized_verdant_landscape_0122套件: image_static 指标: geometric_consistency 场景: stylized / outdoor / verdant_landscape
基准 prompt target
Camera pan left. A verdant landscape with trees, extended terrace, and foliage.
prompt source: report_details
高分侧有明显的镜头或场景运动;两侧首帧均与同一输入图完成几何匹配。此处只比较 geometric_consistency。
较高指标分 分数 0.9909
较低指标分 分数 0.1847
输入图像
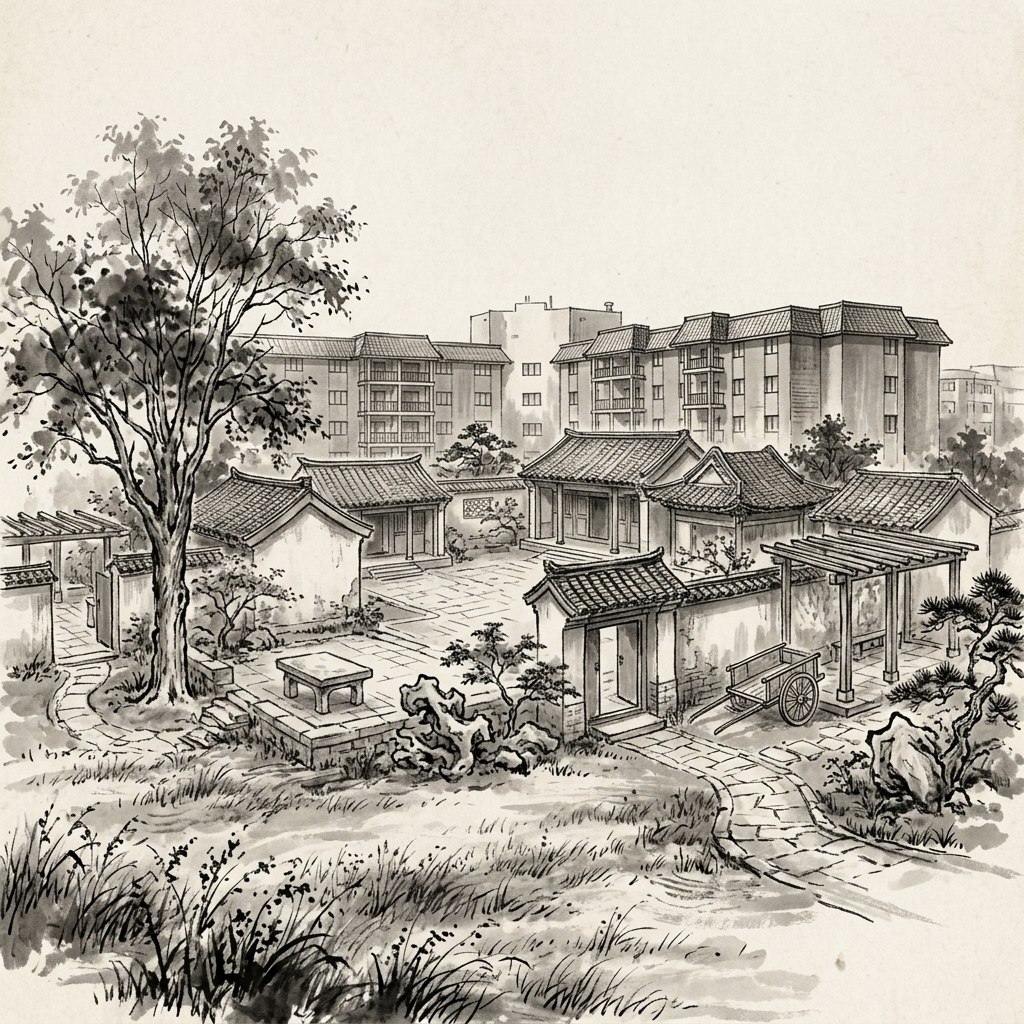
输入已核验 · 同一 benchmark case · gap 0.7897
image_static_stylized_suburb_0009套件: image_static 指标: geometric_consistency 场景: stylized / outdoor / suburb
基准 prompt target
Camera orbit right. A traditional courtyard with stone bench, garden elements, and traditional buildings.
prompt source: report_details
高分侧有明显的镜头或场景运动;两侧首帧均与同一输入图完成几何匹配。此处只比较 geometric_consistency。
较高指标分 分数 0.9848
较低指标分 分数 0.1952
输入图像
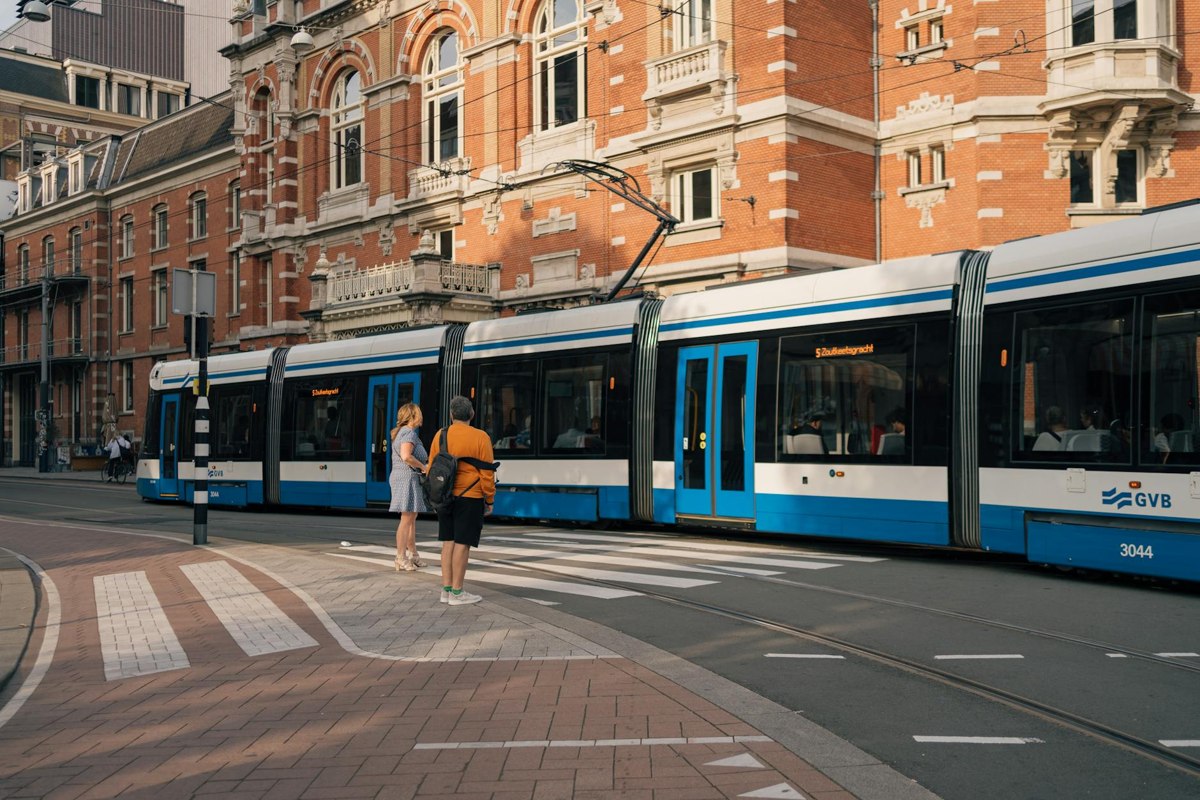
输入已核验 · 同一 benchmark case · gap 0.8076
image_static_photorealistic_city_0047套件: image_static 指标: geometric_consistency 场景: photorealistic / outdoor / city
基准 prompt target
Camera orbit left. A city street with tram, bicycle, and historic building.
prompt source: report_details
高分侧有明显的镜头或场景运动;两侧首帧均与同一输入图完成几何匹配。此处只比较 geometric_consistency。
较高指标分 分数 0.9894
较低指标分 分数 0.1818
输入图像
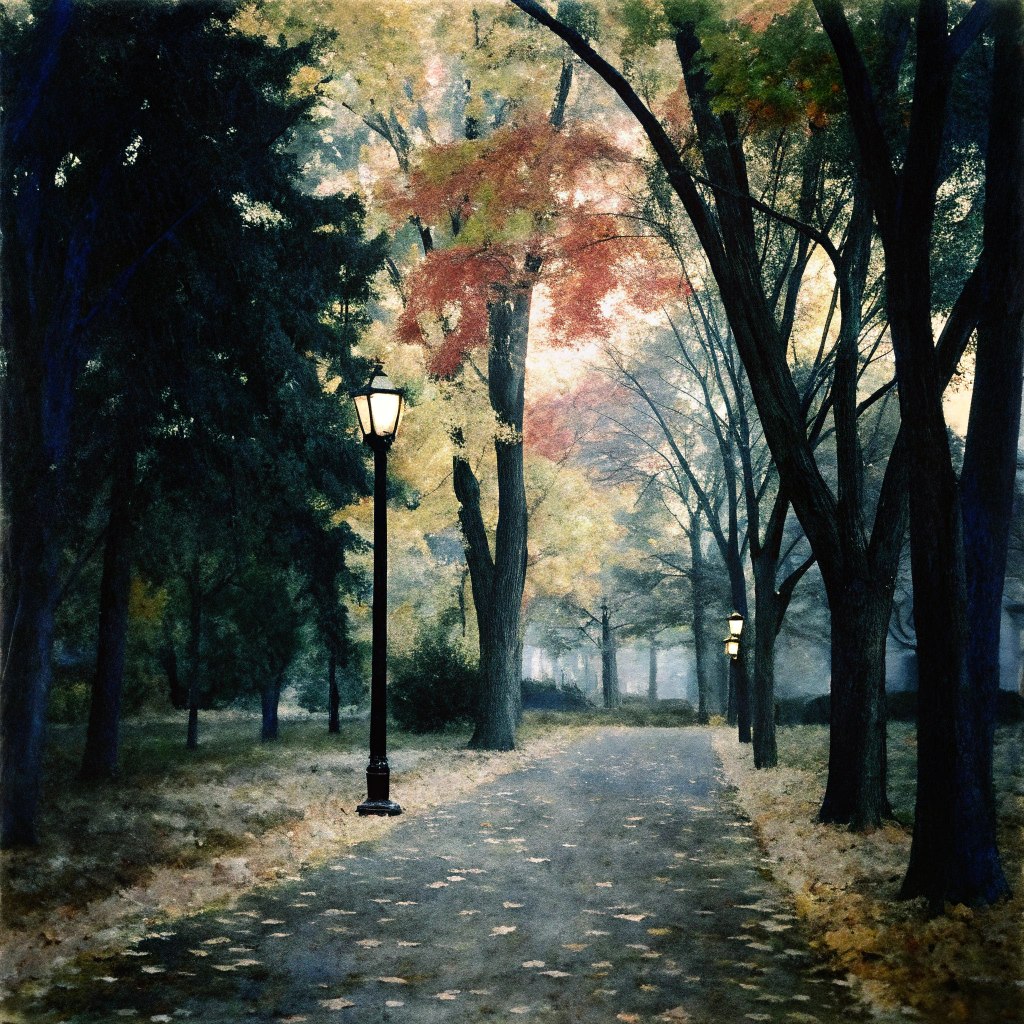
输入已核验 · 同一 benchmark case · gap 0.3239
image_static_stylized_city_0123套件: image_static 指标: photometric_consistency 场景: stylized / outdoor / city
基准 prompt target
Camera pull out. A park path with benches, trees, and wider path. Camera move right. A city street with buildings, parked cars, and benches. Camera pan right. An urban square with fountain, people, and shops.
prompt source: report_details
高分侧有明显的镜头或场景运动;两侧首帧均与同一输入图完成几何匹配。此处只比较 photometric_consistency。
较高指标分 分数 0.8311
较低指标分 分数 0.5073
输入图像
输入已核验 · 同一 benchmark case · gap 0.2983
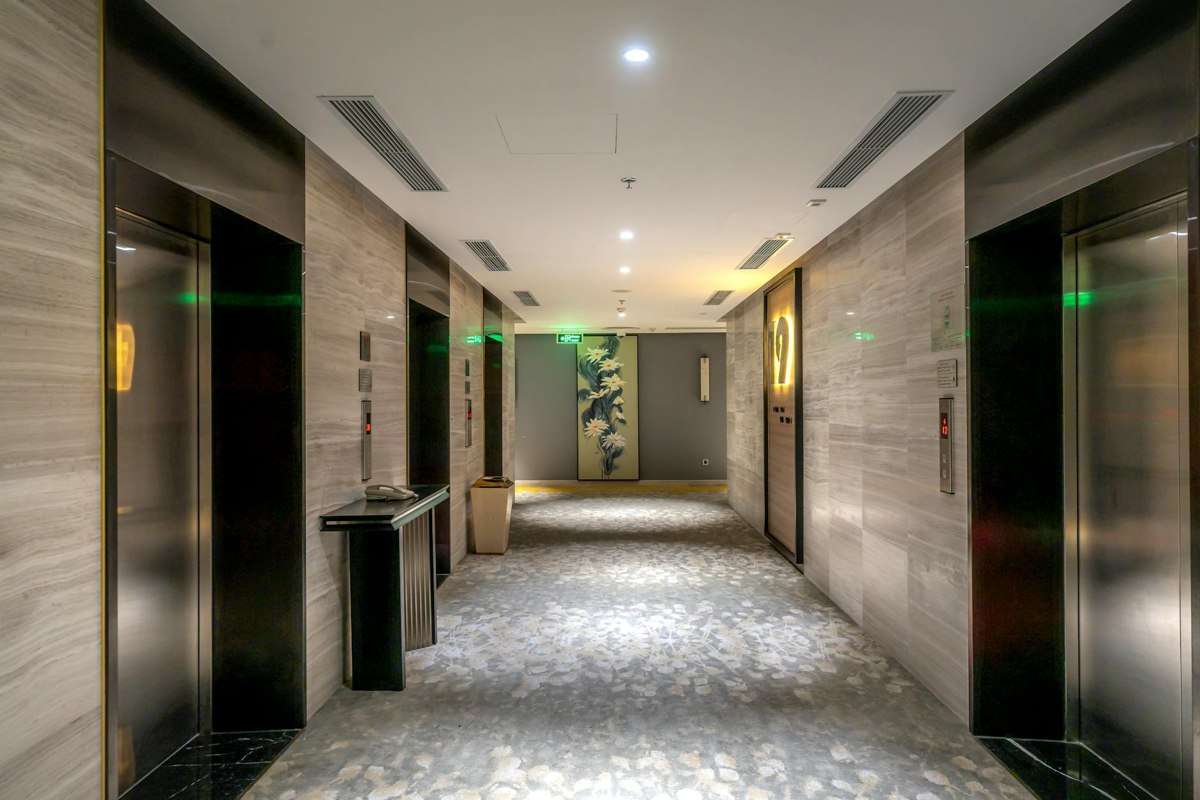
image_static_photorealistic_passageways_0106套件: image_static 指标: photometric_consistency 场景: photorealistic / indoor / passageways
基准 prompt target
Camera pan right. A modern hotel corridor with elevator doors, emergency exit sign, and wall panels. Camera move right. A lobby area with reception desk, seating area, and decorative plants. Camera pull out. Entrance doors with revolving door and floor mat.
prompt source: report_details
高分侧有明显的镜头或场景运动;两侧首帧均与同一输入图完成几何匹配。此处只比较 photometric_consistency。
较高指标分 分数 0.9052
较低指标分 分数 0.6070
输入图像
输入已核验 · 同一 benchmark case · gap 0.3448
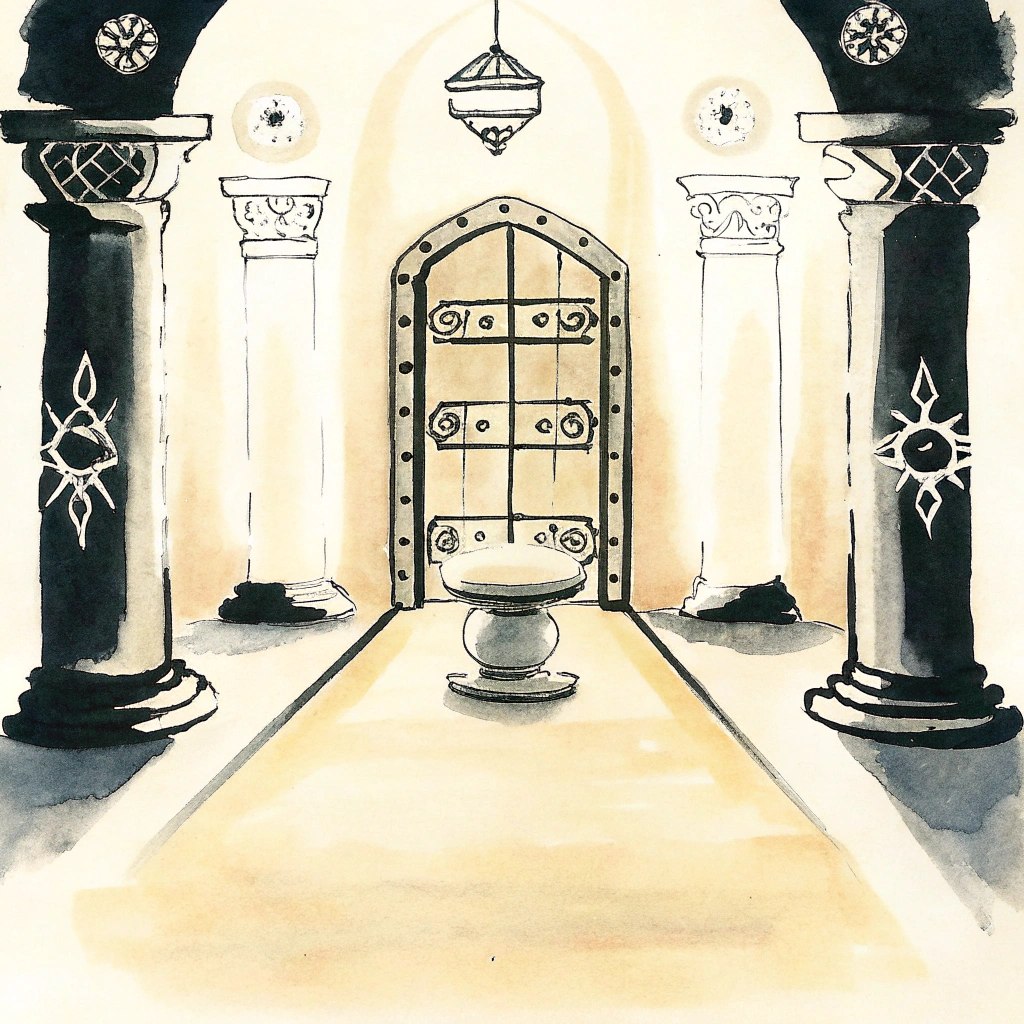
image_static_stylized_passageways_0090套件: image_static 指标: photometric_consistency 场景: stylized / indoor / passageways
基准 prompt target
Camera pan right. A stylized passageway with columns, wall sconces, and corridor.
prompt source: report_details
高分侧有明显的镜头或场景运动;两侧首帧均与同一输入图完成几何匹配。此处只比较 photometric_consistency。
较高指标分 分数 0.8870
较低指标分 分数 0.5423