衡量实际观测到的原生视频帧区间上,恢复动作集合与命令集合是否完全一致。设预测为 Pi、目标为 Gi、区间时长为 wi:
strict=∑iwi∑iwi⋅1[Pi=Gi](1)
解码使用固定的每秒速率阈值和真实视频 FPS,不根据测试标签挑选阈值。F 帧只提供 F−1 个可观察区间。缺失位姿区间不插值成成功动作,而是排除并报告观测覆盖率。
默认阈值为 move_speed_threshold=0.06 位姿平移单位/秒、rotation_speed_threshold=6.0 度/秒,所有模型共用。这些阈值未经独立物理标定,不能把 ViPE 的平移单位直接解释为米。
FPS 来自视频或显式 runtime 配置。只评价实际观测到的原生连续帧区间;帧号映射损坏或 FPS 未知时不给数字。优先使用原生动作时间线;只有有序动作 token 时,均匀分配时间属于显式假设,不代表已经验证了实际执行时序。
越高越好,为 official 指标。动作标签一致不等于位移/角度幅度正确。另存有动作命令时的准确率与 idle 误动作率。需要可用动作时间线和位姿 sidecar;后端为 pose_action。
Audit manifest: docs/assets/metric_examples/longseq_memory_60s_examples_20260909.json.
 输入图像
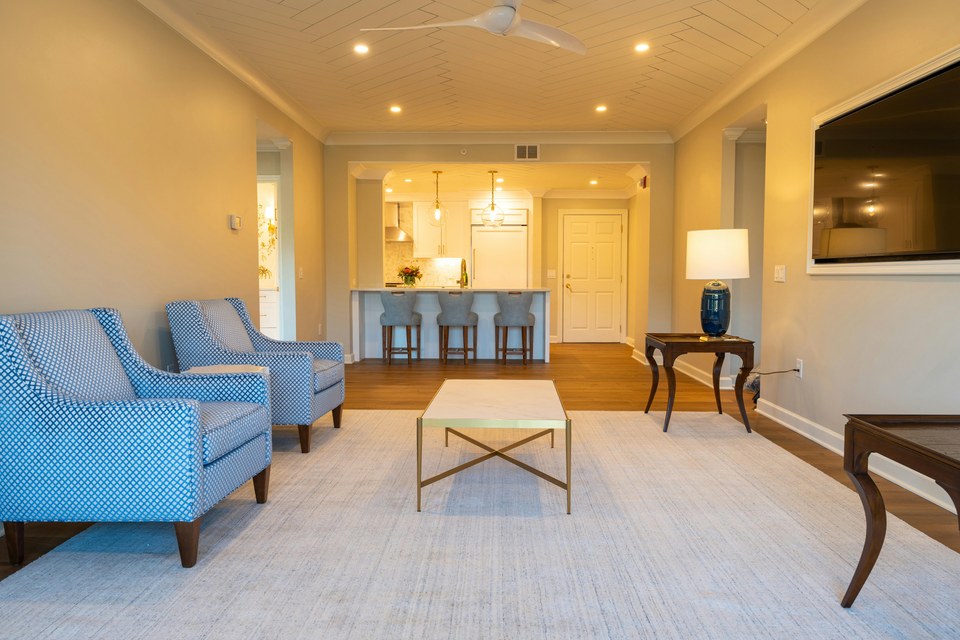
60 秒 memory_loop · 同一 benchmark case · gap 0.9990
memory-dolly_loop-memory_pool_408
套件: memory_loop场景: photorealistic / indoor / living_spaces
基准 prompt target
Move the camera forward through the scene, then back to where it started.
prompt source: memory_loop_prompt
在这段 60 秒回环里,看恢复出的逐帧动作是否与请求按键完全一致。多余运动或漏转都会降低严格准确率。
较高指标分分数 0.9990 · official
较低指标分分数 0.0000 · official
 输入图像
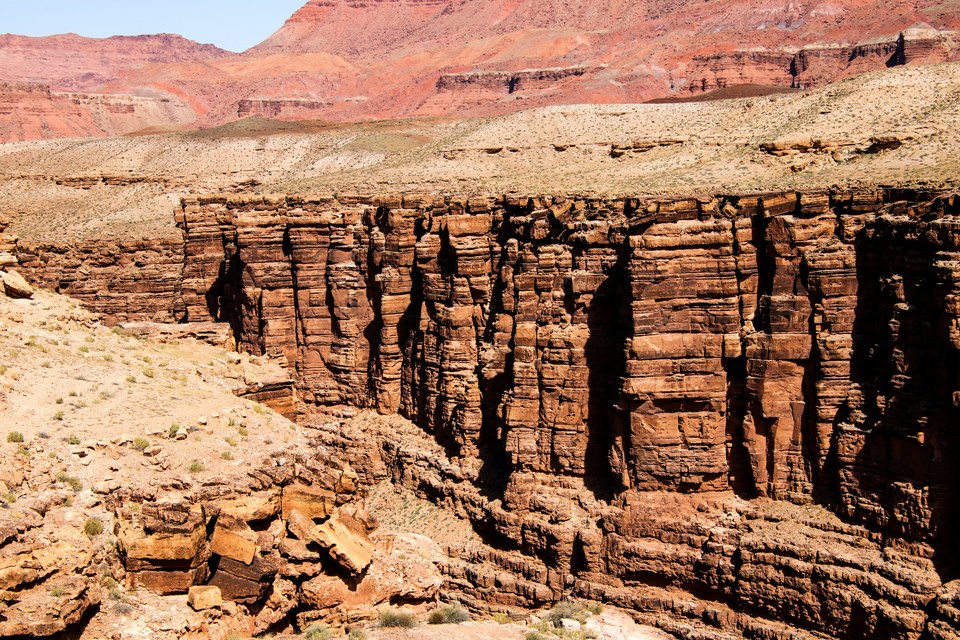
60 秒 memory_loop · 同一 benchmark case · gap 0.8933
memory-palindrome_loop-memory_pool_003
套件: memory_loop场景: photorealistic / outdoor / terrestrial_landscape
基准 prompt target
Move forward, turn and continue, then retrace the whole path back.
prompt source: memory_loop_prompt
在这段 60 秒回环里,看恢复出的逐帧动作是否与请求按键完全一致。多余运动或漏转都会降低严格准确率。
较高指标分分数 0.9890 · official
较低指标分分数 0.0957 · official
 输入图像
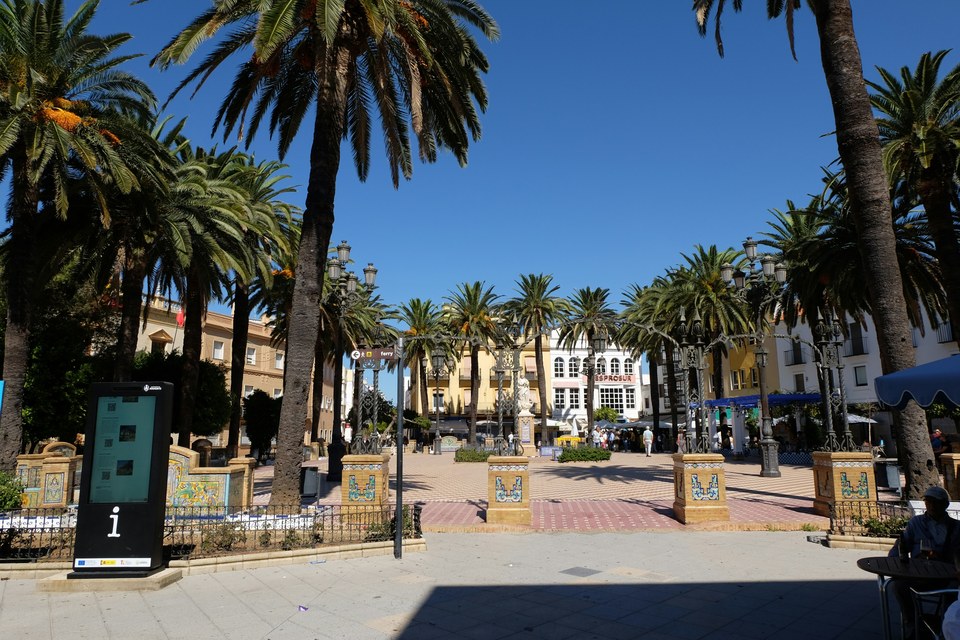
60 秒 memory_loop · 同一 benchmark case · gap 0.8297
memory-yaw_loop_360-memory_pool_028
套件: memory_loop场景: photorealistic / outdoor / city
基准 prompt target
Rotate the camera a full turn in place and come back to the starting view.
prompt source: memory_loop_prompt
在这段 60 秒回环里,看恢复出的逐帧动作是否与请求按键完全一致。多余运动或漏转都会降低严格准确率。
较高指标分分数 0.8297 · official
较低指标分分数 0.0000 · official
 输入图像
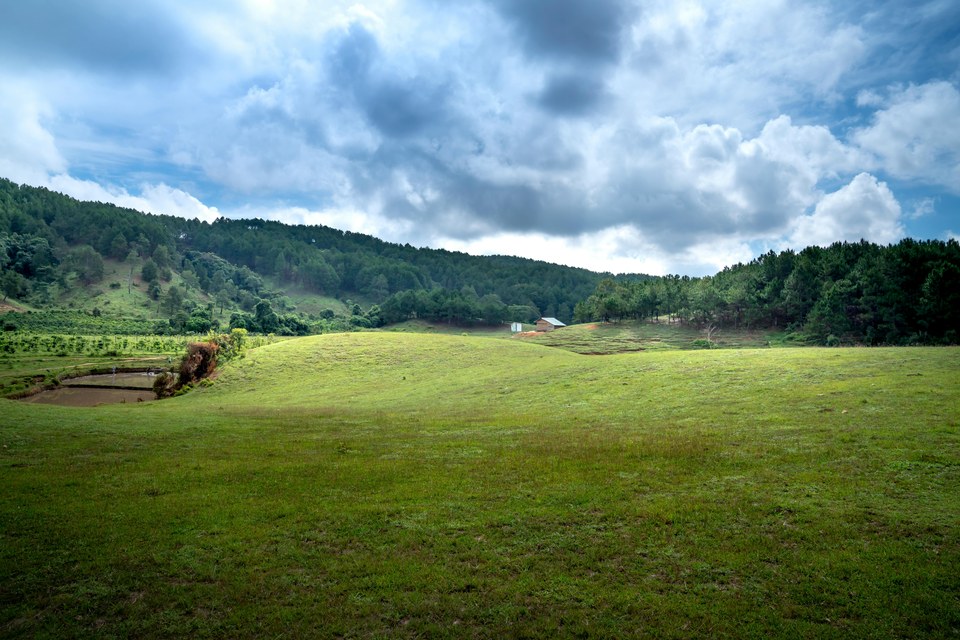
60 秒 memory_loop · 同一 benchmark case · gap 0.8242
memory-yaw_loop_180-memory_pool_249
套件: memory_loop场景: photorealistic / outdoor / verdant_landscape
基准 prompt target
Turn the camera to the right, then turn back to the starting view.
prompt source: memory_loop_prompt
在这段 60 秒回环里,看恢复出的逐帧动作是否与请求按键完全一致。多余运动或漏转都会降低严格准确率。
较高指标分分数 0.8242 · official
较低指标分分数 0.0000 · official

