衡量恢复动作集合与命令集合之间按时长加权的集合 F1,同时惩罚漏动作和额外动作。设预测为 Pi、目标为 Gi、观测区间时长为 wi:
F1(Pi,Gi)=∣Pi∣+∣Gi∣2∣Pi∩Gi∣(1)
partial=∑iwi∑iwi⋅F1(Pi,Gi)(2)
两个空集合的 F1 为 1。只要求一个动作,却预测了包含它的五个动作时,F1 为 1/3,而不是 1。越高越好。
与 strict accuracy 共用固定速率解码、原生时间轴及覆盖率规则。为 official 指标,不是独立的记忆能力证据,也不测标定后的运动幅度。后端为 pose_action。
Audit manifest: docs/assets/metric_examples/longseq_memory_60s_examples_20260909.json.
 输入图像
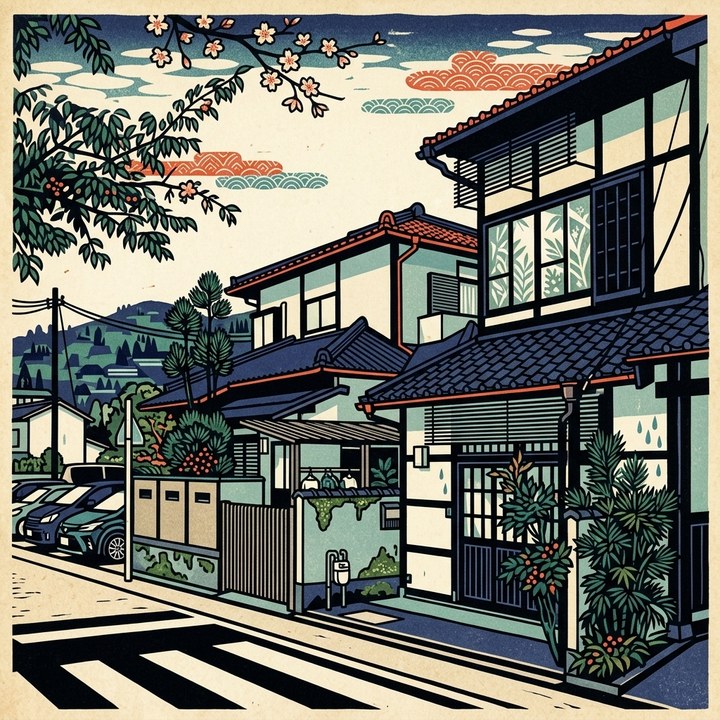
60 秒 memory_loop · 同一 benchmark case · gap 0.9781
memory-dolly_loop-memory_pool_238
套件: memory_loop场景: stylized / outdoor / suburb
基准 prompt target
Move the camera forward through the scene, then back to where it started.
prompt source: memory_loop_prompt
部分重合的按键仍计分。较好的 60 秒结果跟随请求方向,较差的结果换成了另一种运动。
较高指标分分数 0.9781 · official
较低指标分分数 0.0000 · official
 输入图像
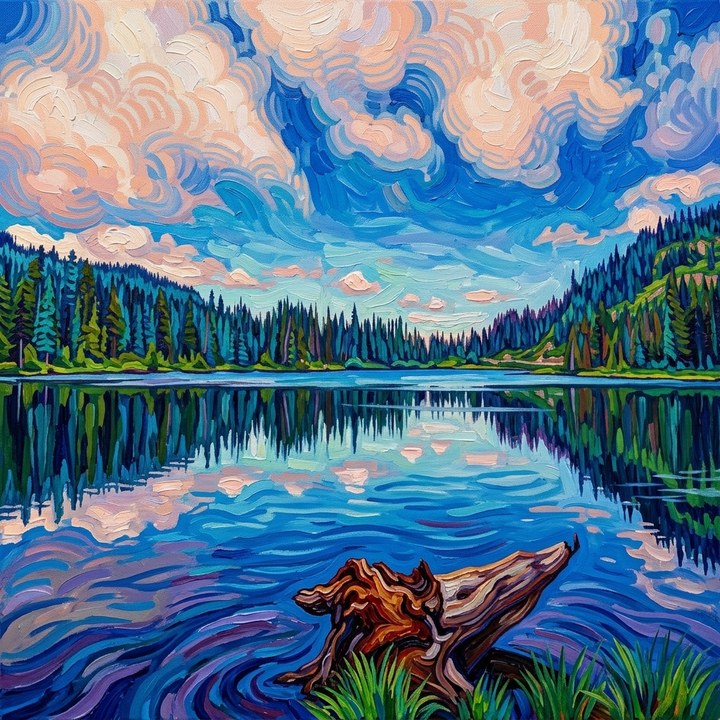
60 秒 memory_loop · 同一 benchmark case · gap 0.9174
memory-yaw_loop_180-memory_pool_439
套件: memory_loop场景: stylized / outdoor / aquatic_landscape
基准 prompt target
Turn the camera to the right, then turn back to the starting view.
prompt source: memory_loop_prompt
部分重合的按键仍计分。较好的 60 秒结果跟随请求方向,较差的结果换成了另一种运动。
较高指标分分数 0.9441 · official
较低指标分分数 0.0267 · official
 输入图像
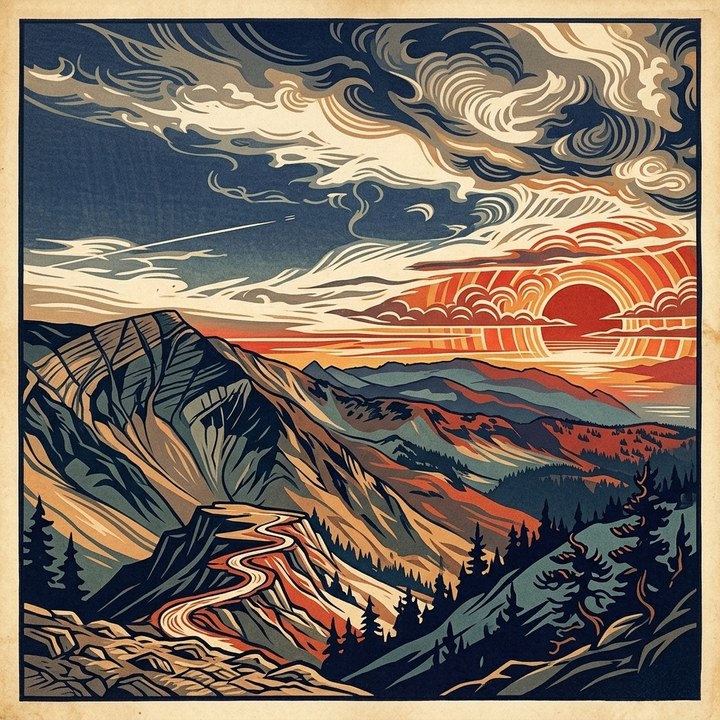
60 秒 memory_loop · 同一 benchmark case · gap 0.9161
memory-yaw_loop_360-memory_pool_132
套件: memory_loop场景: stylized / outdoor / terrestrial_landscape
基准 prompt target
Rotate the camera a full turn in place and come back to the starting view.
prompt source: memory_loop_prompt
部分重合的按键仍计分。较好的 60 秒结果跟随请求方向,较差的结果换成了另一种运动。
较高指标分分数 0.9283 · official
较低指标分分数 0.0122 · official
 输入图像
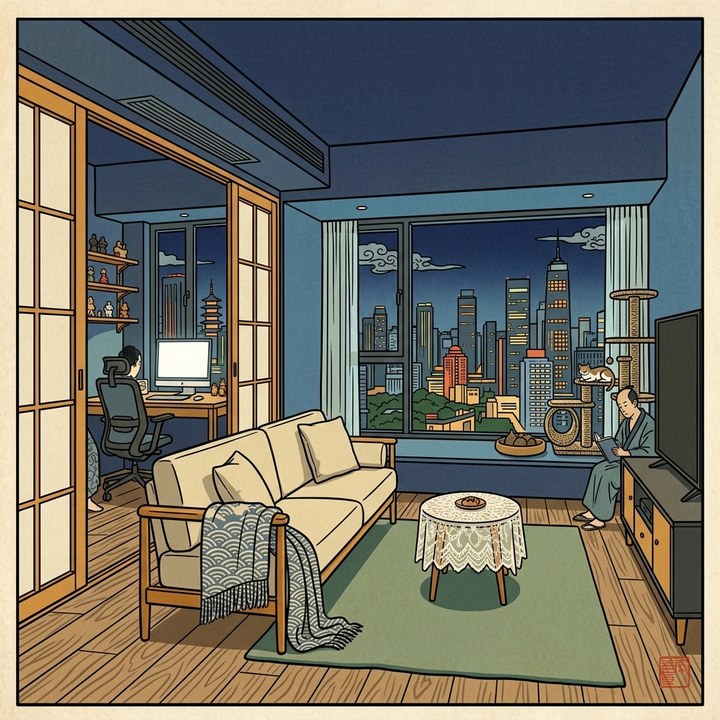
60 秒 memory_loop · 同一 benchmark case · gap 0.4901
memory-double_yaw_loop-memory_pool_260
套件: memory_loop场景: stylized / indoor / living_spaces
基准 prompt target
Turn away and back to the start twice in a row.
prompt source: memory_loop_prompt
部分重合的按键仍计分。较好的 60 秒结果跟随请求方向,较差的结果换成了另一种运动。
较高指标分分数 0.7072 · official
较低指标分分数 0.2171 · official
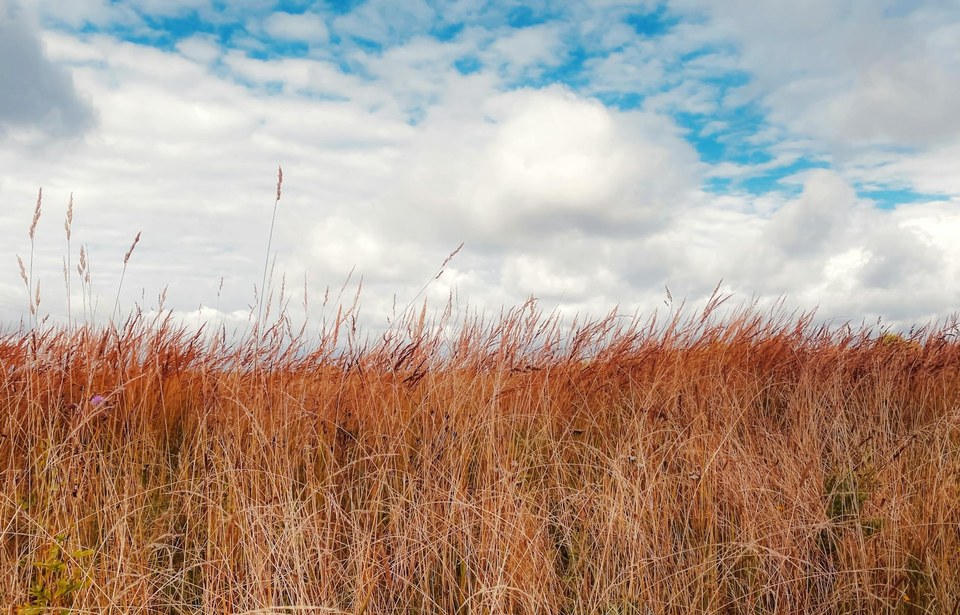 输入图像
60 秒 memory_loop · 同一 benchmark case · gap 0.3753
memory-dolly_loop-memory_pool_463
套件: memory_loop场景: photorealistic / outdoor / terrestrial_landscape
基准 prompt target
Move the camera forward through the scene, then back to where it started.
prompt source: memory_loop_prompt
部分重合的按键仍计分。较好的 60 秒结果跟随请求方向,较差的结果换成了另一种运动。
较高指标分分数 0.8285 · official
较低指标分分数 0.4531 · official

