本页定义三组 GVGC-style 正式极线几何指标 [Li et al., 2024 ],用于检验生成视频相邻帧是否具备稳定的双视角极线解释 [Hartley and Zisserman, 2004 ]。它们只依赖 prediction 视频本身,不需要相机位姿标注或 reference video;核心问题是:局部特征对应关系是否近似满足 epipolar constraint,从而说明两帧能否被同一个 pinhole 相机模型下的相对运动解释。
在经典多视角几何中,若两帧来自同一场景、仅发生刚体相机运动,则第一帧中的点 x x x x ′ x' x ′ F F F l ′ = F x l' = F x l ′ = F x 轻量、可解释 的双视角几何信号;但它只检查稀疏特征点的 epipolar 一致性,不能替代 MEt3R、重投影误差或重建类指标对全局三维自洽性的判断。
WorldAtlas 在 prediction 的采样帧上,按 pair_stride 构造相邻(或跨步)帧对,默认使用 SIFT 特征与 Lowe 比率测试进行匹配,再以 OpenCV RANSAC 估计基础矩阵 F F F
指标 原始统计量 方向 epipolar_error基础矩阵 RANSAC 后 inlier 的 Sampson 误差中位数 越低越好 epipolar_inlier_rateRANSAC inlier 数 / Lowe 比率过滤后的匹配数 越高越好 feature_match_coverageRANSAC inlier 数 / 较少一侧关键点数 越高越好
对匹配齐次点 x i , x i ′ x_i, x'_i x i , x i ′
d i = ∣ x i ′ T F x i ∣ ( F x i ) 1 2 + ( F x i ) 2 2 + ( F T x i ′ ) 1 2 + ( F T x i ′ ) 2 2 (1) d_i = \frac{|{x'_i}^{\mathsf T} F x_i|}{\sqrt{(Fx_i)_1^2 + (Fx_i)_2^2 + (F^{\mathsf T}x'_i)_1^2 + (F^{\mathsf T}x'_i)_2^2}}
\tag{1} d i = ( F x i ) 1 2 + ( F x i ) 2 2 + ( F T x i ′ ) 1 2 + ( F T x i ′ ) 2 2 ∣ x i ′ T F x i ∣ ( 1 ) 每个有效帧对以 RANSAC inlier 的 d i d_i d i epipolar_error;视频级取各 pair 中位数,并在 [ 0 , 5 ] [0, 5] [ 0 , 5 ]
每个有效帧对的 inlier 率与覆盖率为
r = # i n l i e r s # g o o d m a t c h e s , c = min ( # i n l i e r s min ( # k p l e f t , # k p r i g h t ) , 1 ) (2) r = \frac{\#\mathrm{inliers}}{\#\mathrm{good\ matches}},
\qquad
c = \min\!\left(\frac{\#\mathrm{inliers}}{\min(\#\mathrm{kp}_\mathrm{left}, \#\mathrm{kp}_\mathrm{right})},\, 1\right)
\tag{2} r = # good matches # inliers , c = min ( min ( # kp left , # kp right ) # inliers , 1 ) ( 2 ) 视频级 epipolar_inlier_rate 与 feature_match_coverage 分别对 r r r c c c [ 0 , 1 ] [0,1] [ 0 , 1 ] epipolar_error 取各有效帧对中位数的中位数,并在 [ 0 , 5 ] [0, 5] [ 0 , 5 ] [ 0 , 1 ] [0, 1] [ 0 , 1 ] not_applicable。这三项均为 official 榜单指标 ,发布时核验完整覆盖率和有效测量;在弱纹理、强非刚性运动或 dynamic prompt 场景下可能频繁失效,宜与 MEt3R、重投影误差等互补阅读。
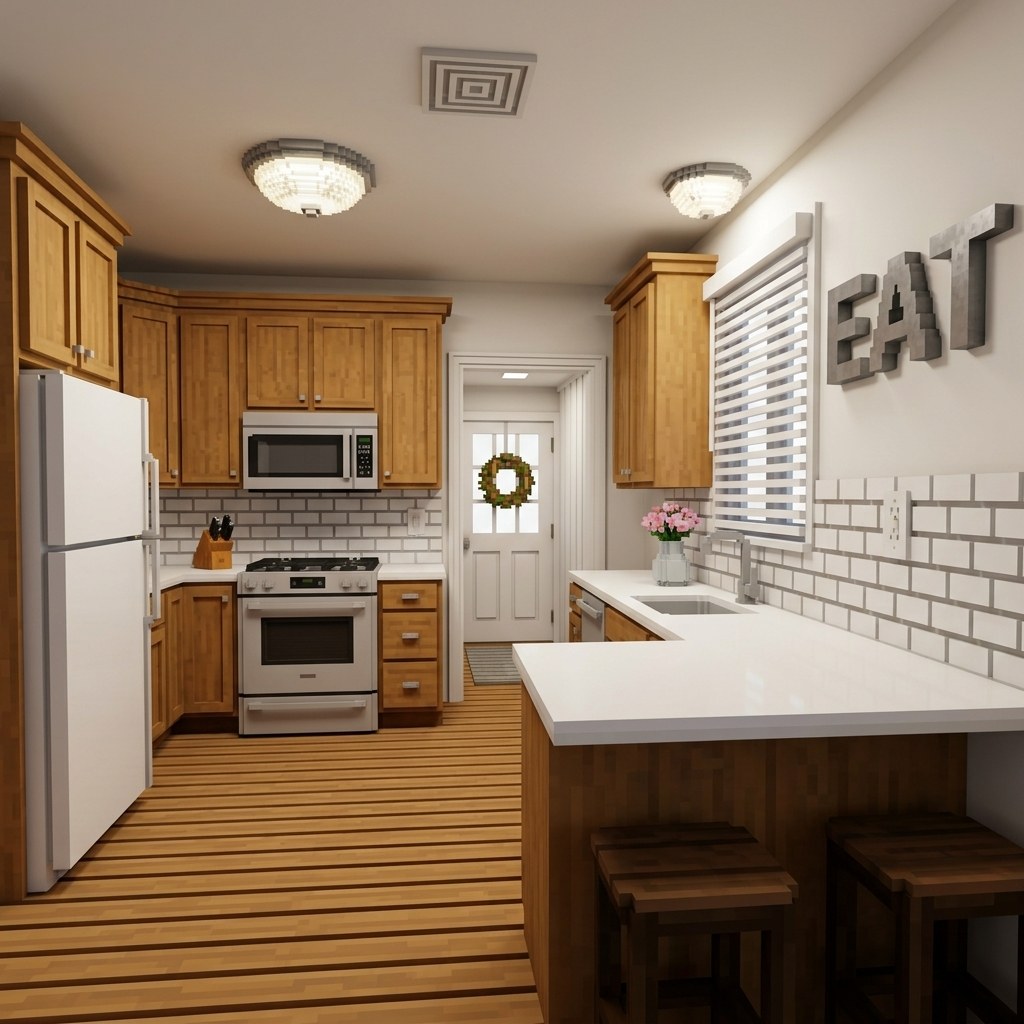
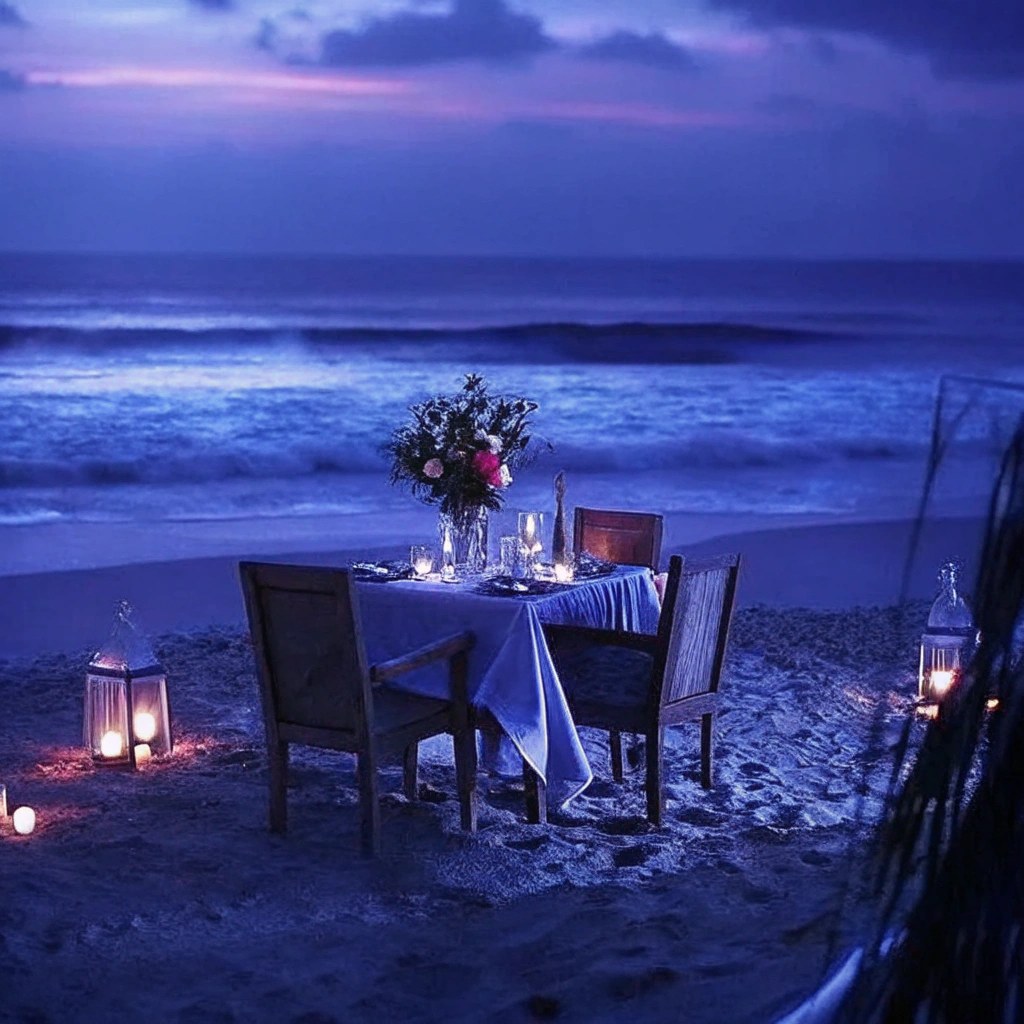
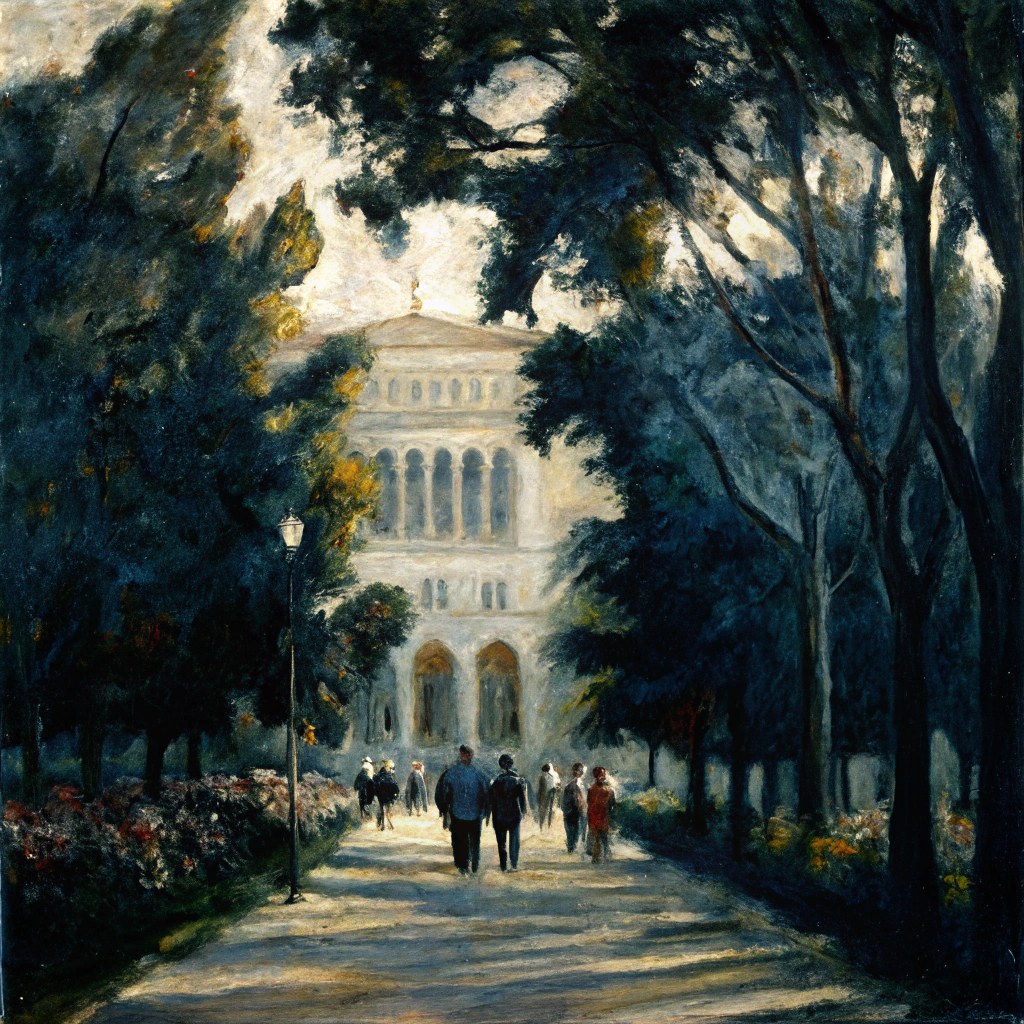
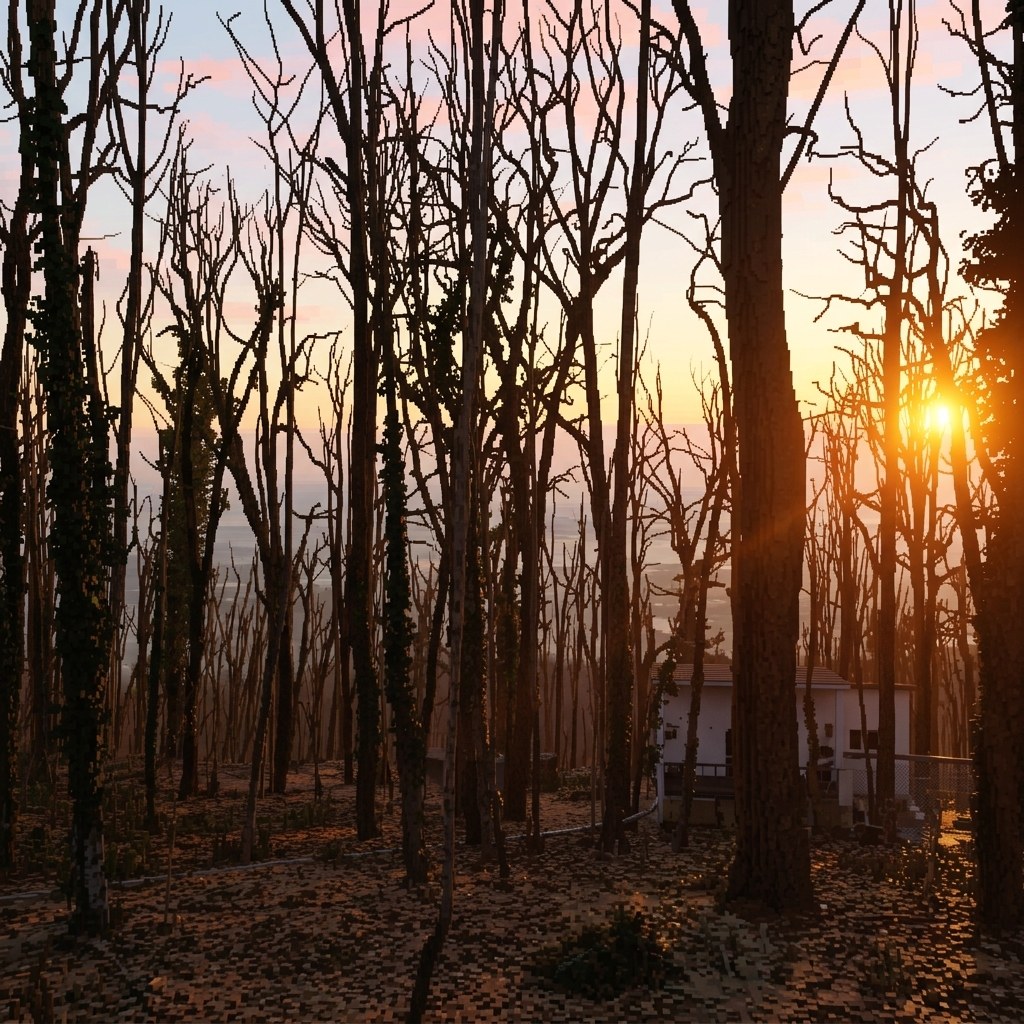
下方展示 19 组 image_static 对比,来自站点已选的同输入案例 docs/assets/metric_examples/paired_manifest.json(paired_same_input_prompt,verified_exact),且两条示例视频都已导出。顺序按各子指标的站点 case rank 轮流排列 epipolar_error、epipolar_inlier_rate、feature_match_coverage。分数是对应子指标的归一化分数。
Audit manifest: docs/assets/metric_examples/paired_manifest.json.
输入图像
同一输入与 prompt · image_static · gap 0.0593
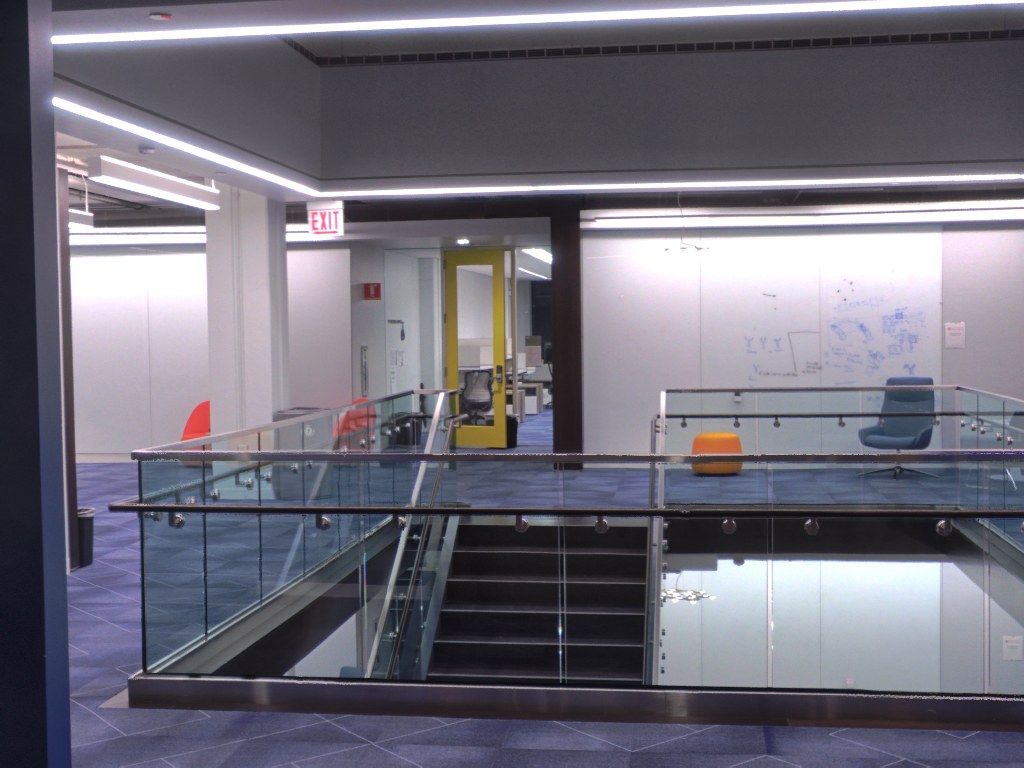
image_static_photorealistic_workspaces_0016套件: image_static 指标: epipolar_error 场景: photorealistic / workspaces
Benchmark prompt
Camera pan right. A modern office with desks, computers, and office chairs. Everything in the scene remains completely motionless.
来源: generation_records
较高分: lingbot_world_image_static。较低分: matrix_game2_5s_image_static。好坏标签仅比较 epipolar_error。
较高指标分 分数 0.9814 lingbot_world_image_static 内点 Sampson 误差中位数 0.0932
较低指标分 分数 0.9221 matrix_game2_5s_image_static 内点 Sampson 误差中位数 0.3897
输入图像
同一输入与 prompt · image_static · gap 0.5595
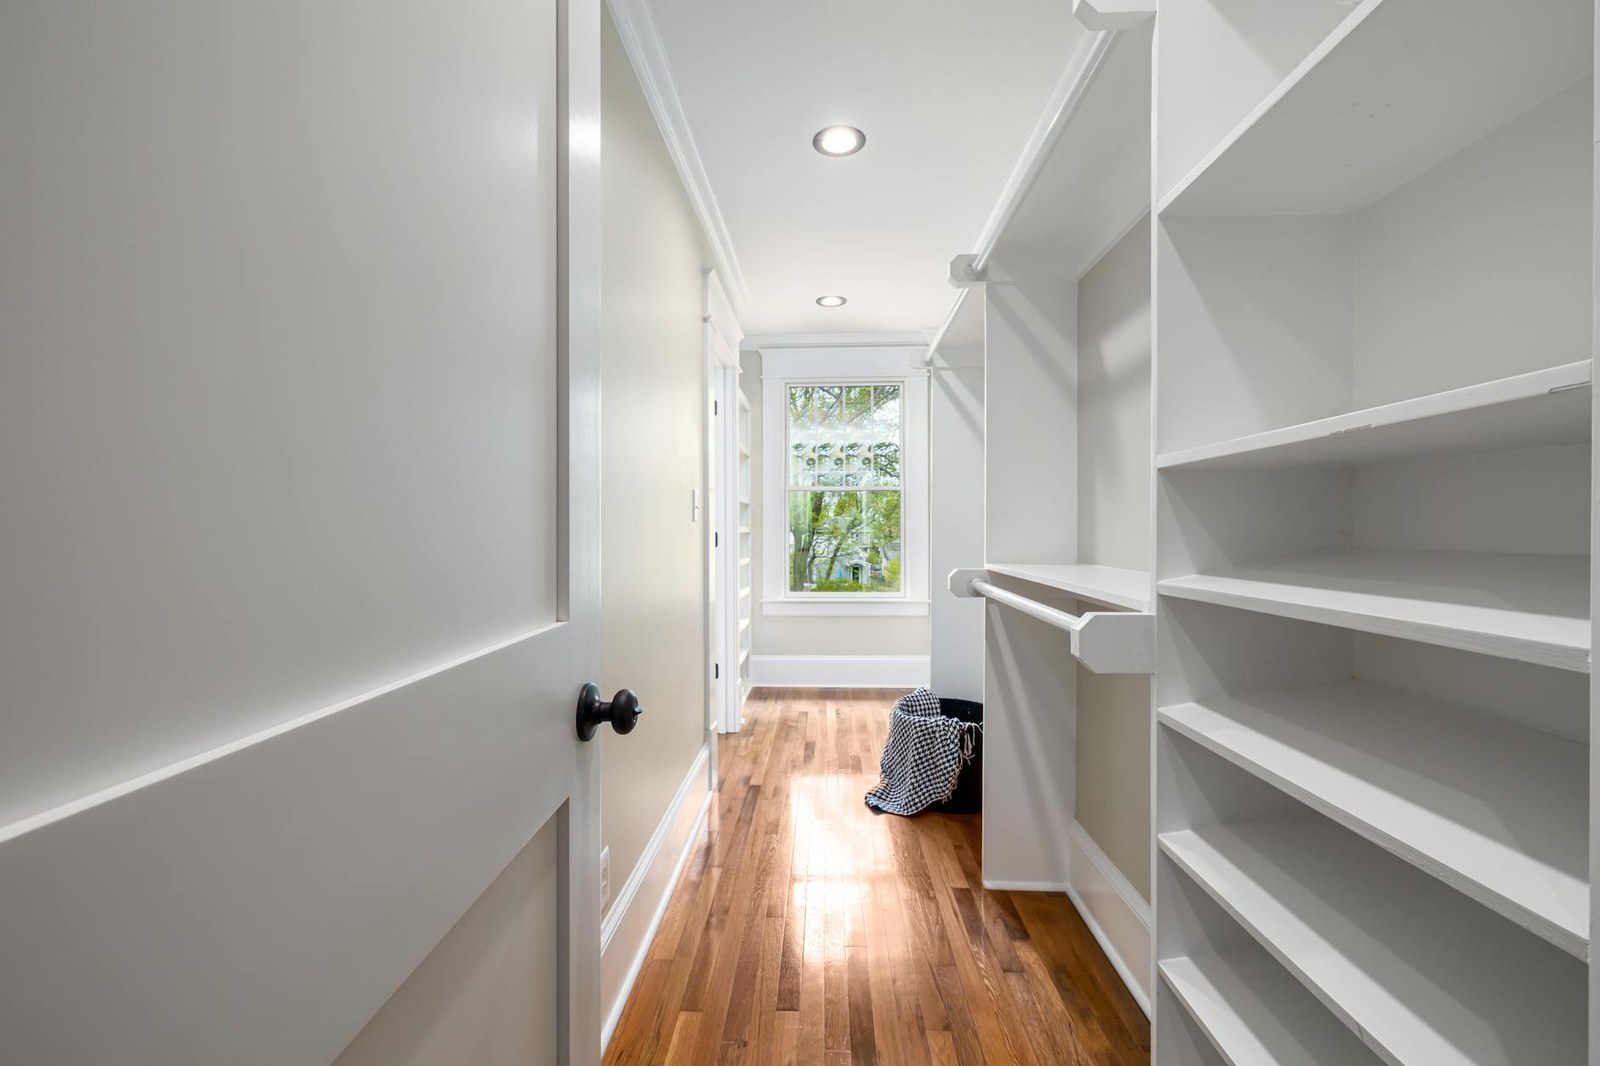
image_static_photorealistic_passageways_0079套件: image_static 指标: epipolar_inlier_rate 场景: photorealistic / passageways
Benchmark prompt
Camera move right. A bright hallway with wooden floor, armchair, and small table. Everything in the scene remains completely motionless.
来源: generation_records
较高分: astronex_world_image_static。较低分: matrix_game2_5s_image_static。好坏标签仅比较 epipolar_inlier_rate。
较高指标分 分数 0.9745 astronex_world_image_static 内点率 97.5%
较低指标分 分数 0.4150 matrix_game2_5s_image_static 内点率 41.5%
输入图像
同一输入与 prompt · image_static · gap 0.4021
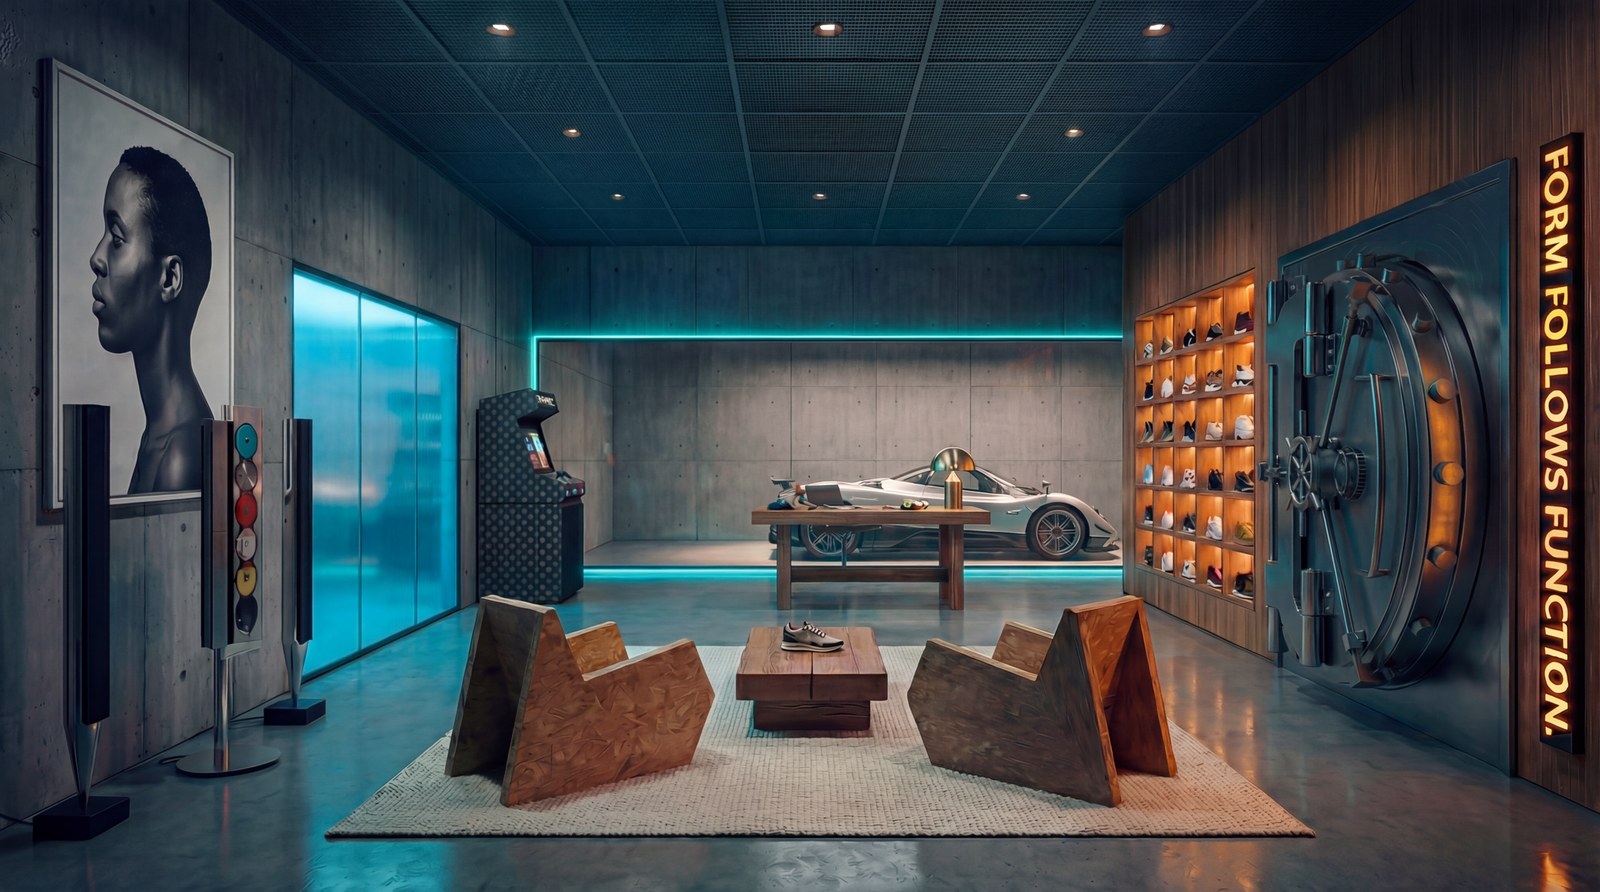
image_static_photorealistic_workspaces_0074套件: image_static 指标: feature_match_coverage 场景: photorealistic / workspaces
Benchmark prompt
Camera orbit left. A modern workspace with sneaker wall, vault door, and futuristic car. Everything in the scene remains completely motionless.
来源: generation_records
较高分: hy_worldplay_ar_distilled_image_test_balanced_5000_5s。较低分: hy_worldplay_ar_rl_image_test_balanced_5000_5s。好坏标签仅比较 feature_match_coverage。
较高指标分 分数 0.5724 hy_worldplay_ar_distilled_image_test_balanced_5000_5s 特征匹配覆盖率 57.2%
较低指标分 分数 0.1703 hy_worldplay_ar_rl_image_test_balanced_5000_5s 特征匹配覆盖率 17.0%
输入图像
同一输入与 prompt · image_static · gap 0.0396
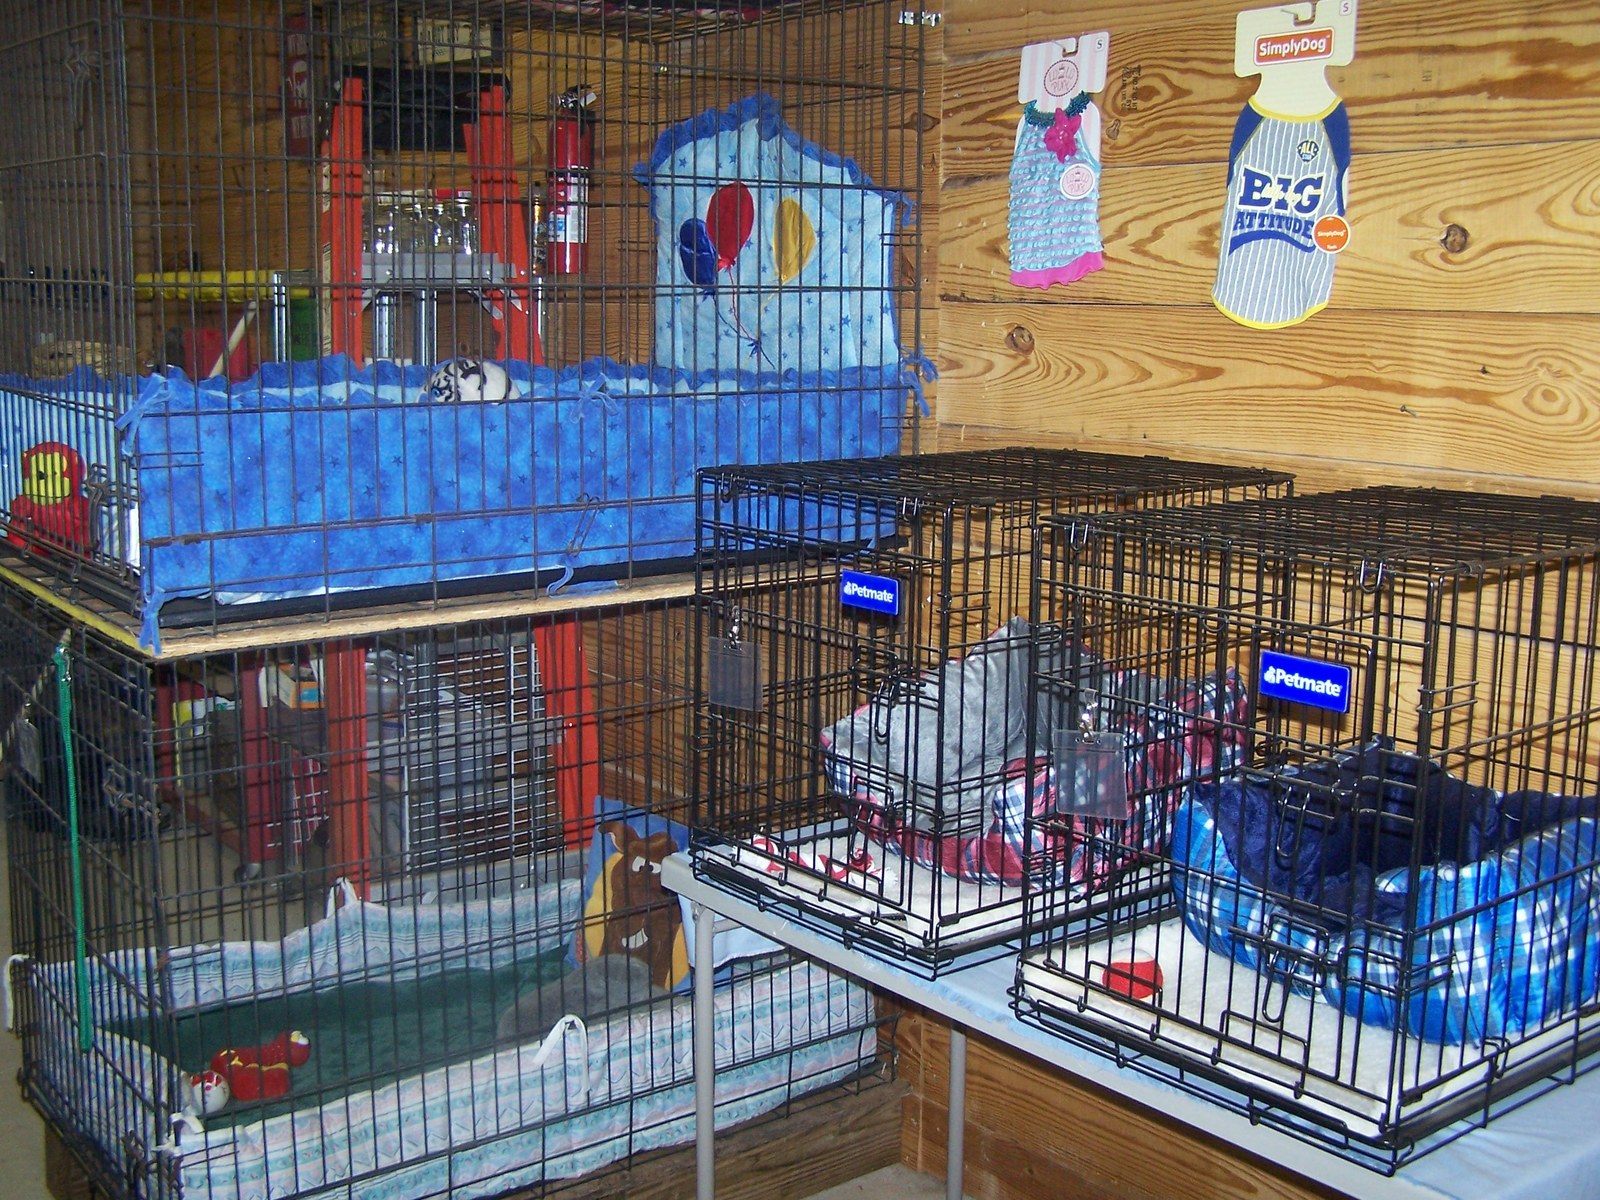
image_static_photorealistic_public_spaces_0014套件: image_static 指标: epipolar_error 场景: photorealistic / public_spaces
Benchmark prompt
Camera pan right. A pet care room with pet cages, feeding station, and water bowls.
来源: generation_records
较高分: hy_worldplay_ar_image_static。较低分: ac3d-image-static。好坏标签仅比较 epipolar_error。
较高指标分 分数 0.9725 hy_worldplay_ar_image_static 内点 Sampson 误差中位数 0.1375
较低指标分 分数 0.9329 ac3d-image-static 内点 Sampson 误差中位数 0.3357
输入图像
同一输入与 prompt · image_static · gap 0.2254
image_static_photorealistic_public_spaces_0150套件: image_static 指标: epipolar_inlier_rate 场景: photorealistic / public_spaces
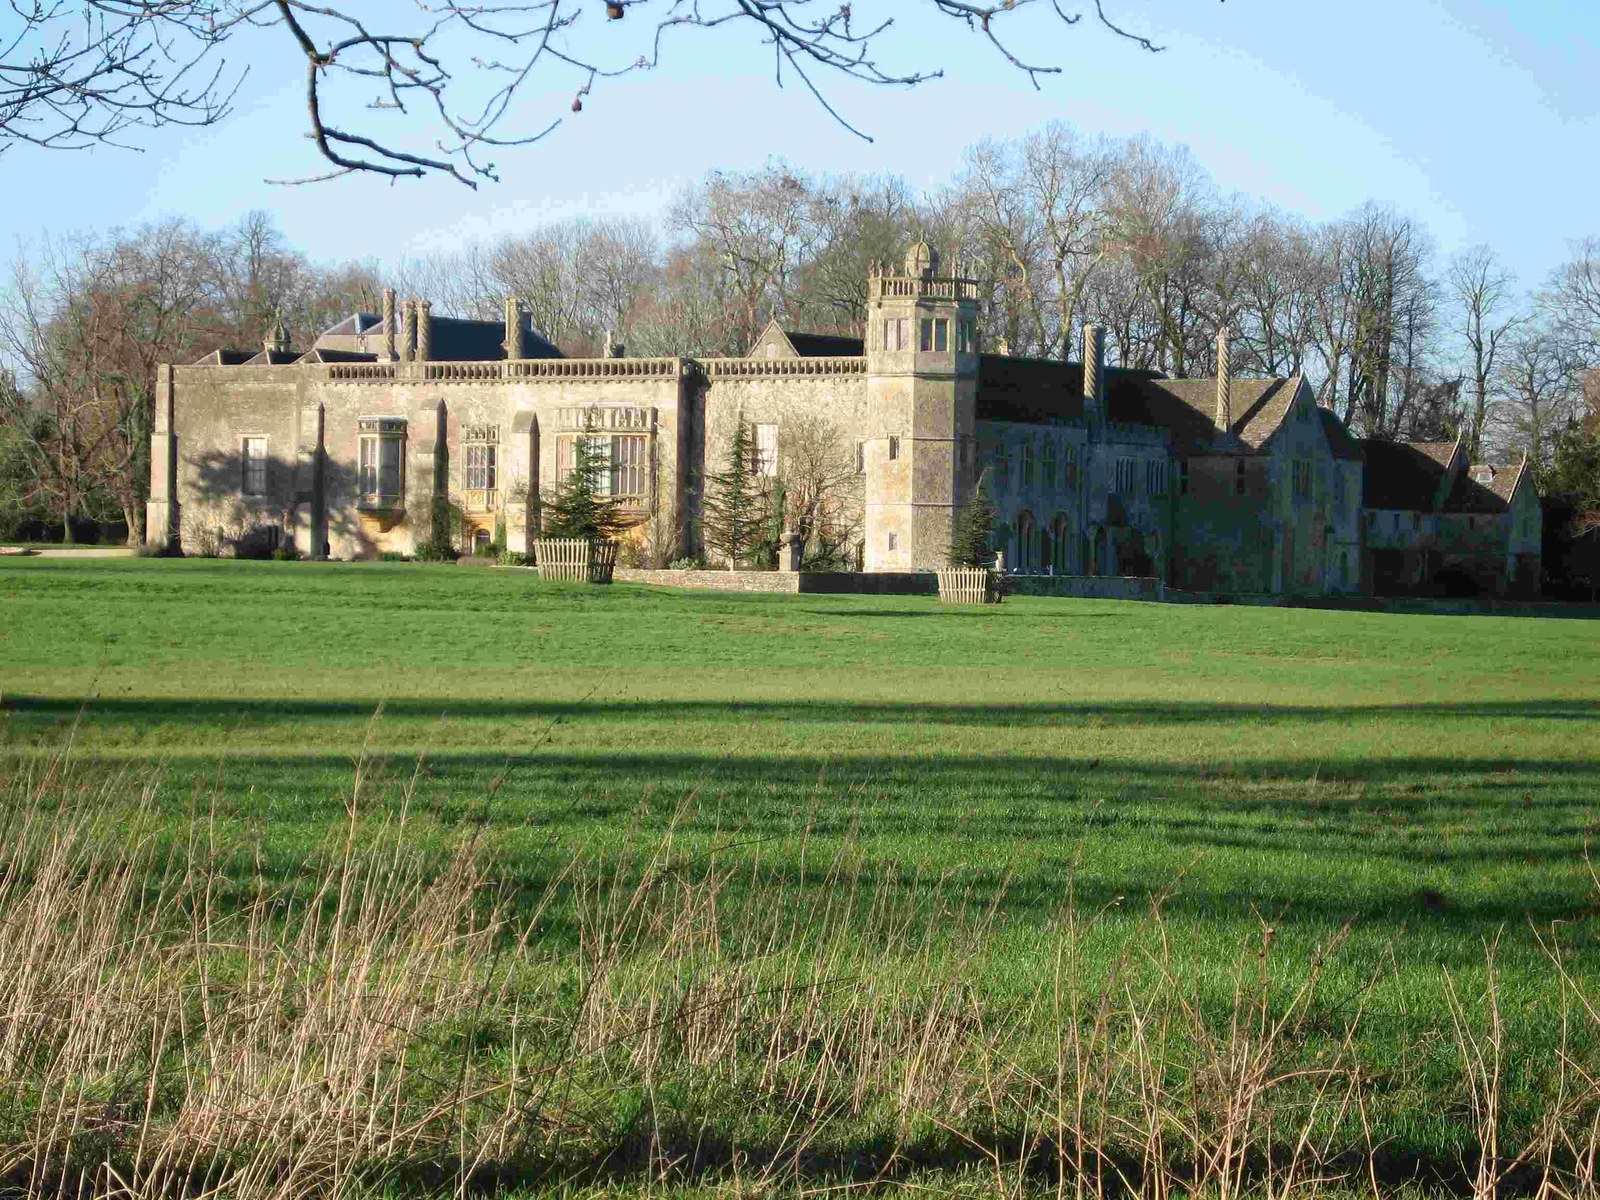
Benchmark prompt
Camera pan left. A historic building with flower beds, stone path, and hedges. Everything in the scene remains completely motionless.
来源: generation_records
较高分: dreamx_world_image_static。较低分: matrix_game2_5s_image_static。好坏标签仅比较 epipolar_inlier_rate。
较高指标分 分数 0.9759 dreamx_world_image_static 内点率 97.6%
较低指标分 分数 0.7505 matrix_game2_5s_image_static 内点率 75.0%
输入图像
同一输入与 prompt · image_static · gap 0.3860
image_static_photorealistic_terrestrial_landscape_0067套件: image_static 指标: feature_match_coverage 场景: photorealistic / terrestrial_landscape
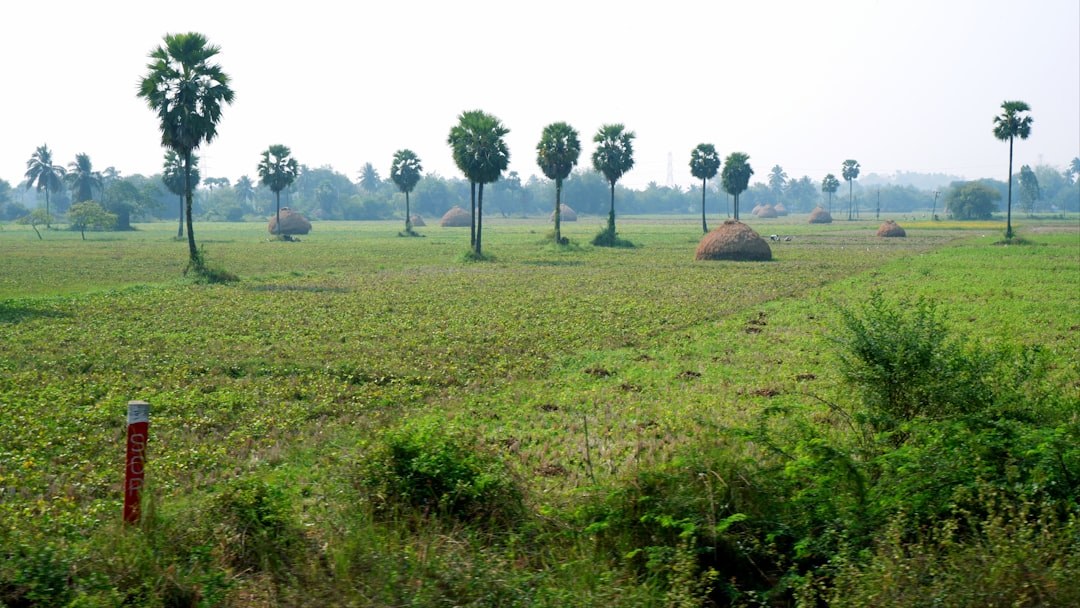
Benchmark prompt
Camera pan left. A rural field with palm trees, haystacks, and green field. Everything in the scene remains completely motionless.
来源: generation_records
较高分: lyra-2-image-static-openenvision。较低分: matrix_game3_5s_image_static_dynamic。好坏标签仅比较 feature_match_coverage。
较高指标分 分数 0.4469 lyra-2-image-static-openenvision 特征匹配覆盖率 44.7%
较低指标分 分数 0.0609 matrix_game3_5s_image_static_dynamic 特征匹配覆盖率 6.1%
输入图像
同一输入与 prompt · image_static · gap 0.0704
image_static_stylized_living_spaces_0037套件: image_static 指标: epipolar_error 场景: stylized / living_spaces
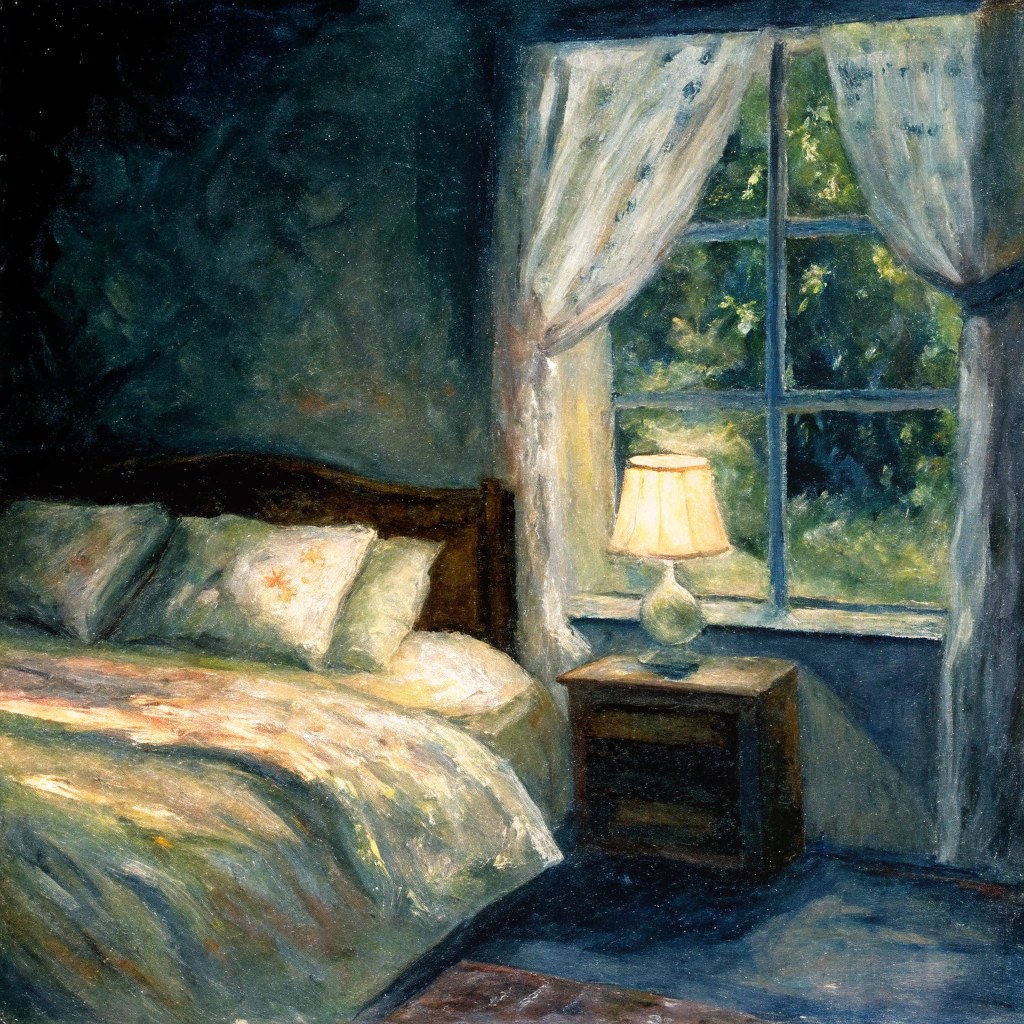
Benchmark prompt
Camera pan right. A bedroom corner with wardrobe, chair, and rug. Everything in the scene remains completely motionless.
来源: generation_records
较高分: dreamx_world_image_static。较低分: matrix_game2_5s_image_static。好坏标签仅比较 epipolar_error。
较高指标分 分数 0.9715 dreamx_world_image_static 内点 Sampson 误差中位数 0.1424
较低指标分 分数 0.9011 matrix_game2_5s_image_static 内点 Sampson 误差中位数 0.4946
输入图像
同一输入与 prompt · image_static · gap 0.1651
image_static_photorealistic_terrestrial_landscape_0006套件: image_static 指标: epipolar_inlier_rate 场景: photorealistic / terrestrial_landscape
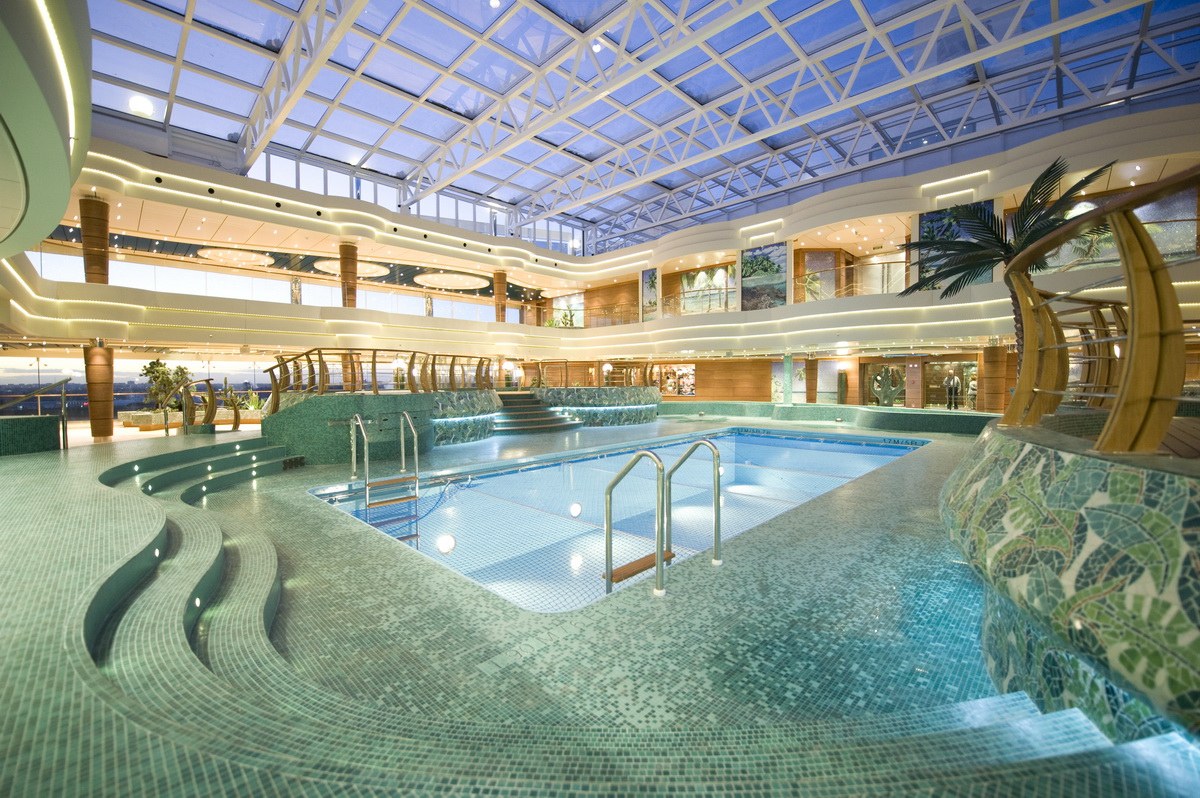
Benchmark prompt
Camera orbit left. An indoor pool with wooden railings, decorative plants, and upper level. Everything in the scene remains completely motionless.
来源: generation_records
较高分: hy_worldplay_ar_distilled_image_test_balanced_5000_5s。较低分: matrix_game3_image_static。好坏标签仅比较 epipolar_inlier_rate。
较高指标分 分数 0.9675 hy_worldplay_ar_distilled_image_test_balanced_5000_5s 内点率 96.7%
较低指标分 分数 0.8024 matrix_game3_image_static 内点率 80.2%
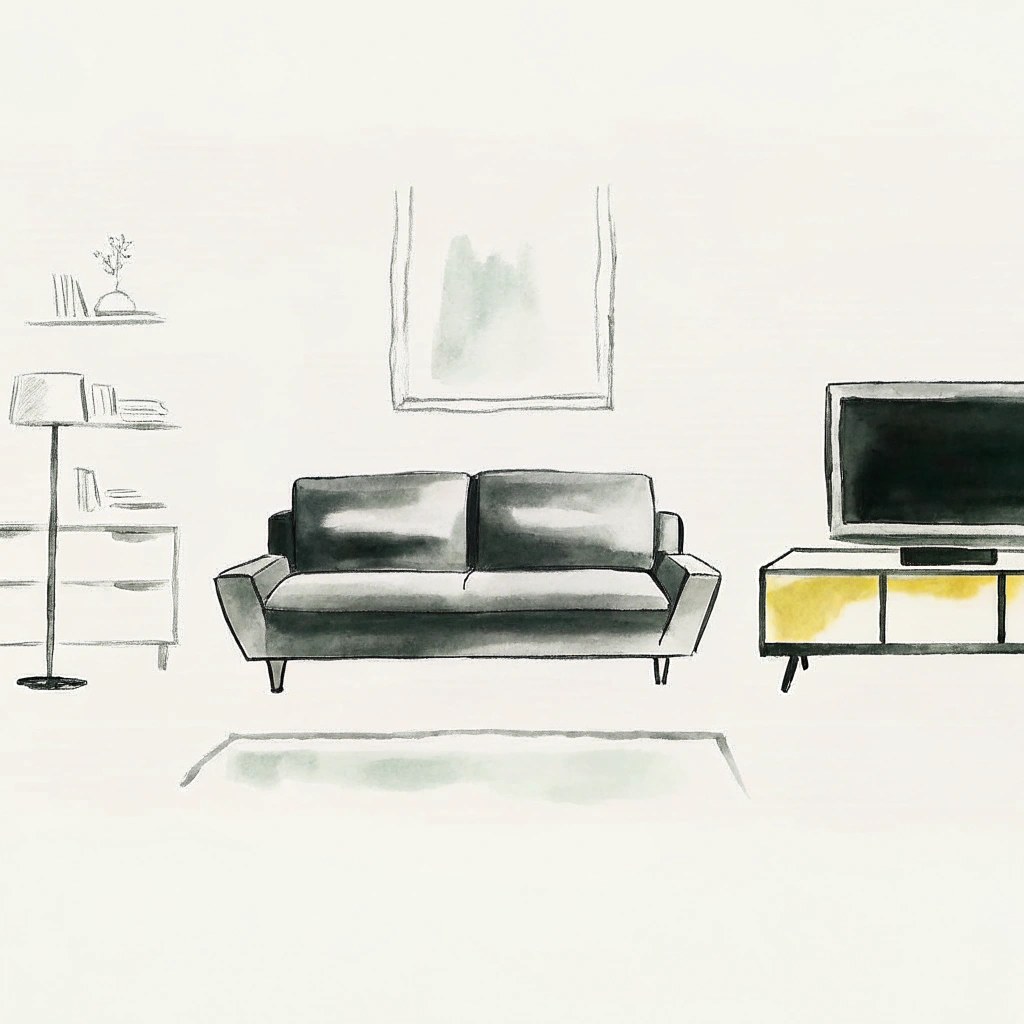
输入图像
同一输入与 prompt · image_static · gap 0.8906
image_static_stylized_living_spaces_0034套件: image_static 指标: feature_match_coverage 场景: stylized / living_spaces
Benchmark prompt
Camera move left. A minimalist living room with bookshelf, window, and armchair. Everything in the scene remains completely motionless.
来源: generation_records
较高分: cameractrl_image_static。较低分: astra_image_static。好坏标签仅比较 feature_match_coverage。
较高指标分 分数 1.0000 cameractrl_image_static 特征匹配覆盖率 100.0%
较低指标分 分数 0.1094 astra_image_static 特征匹配覆盖率 10.9%
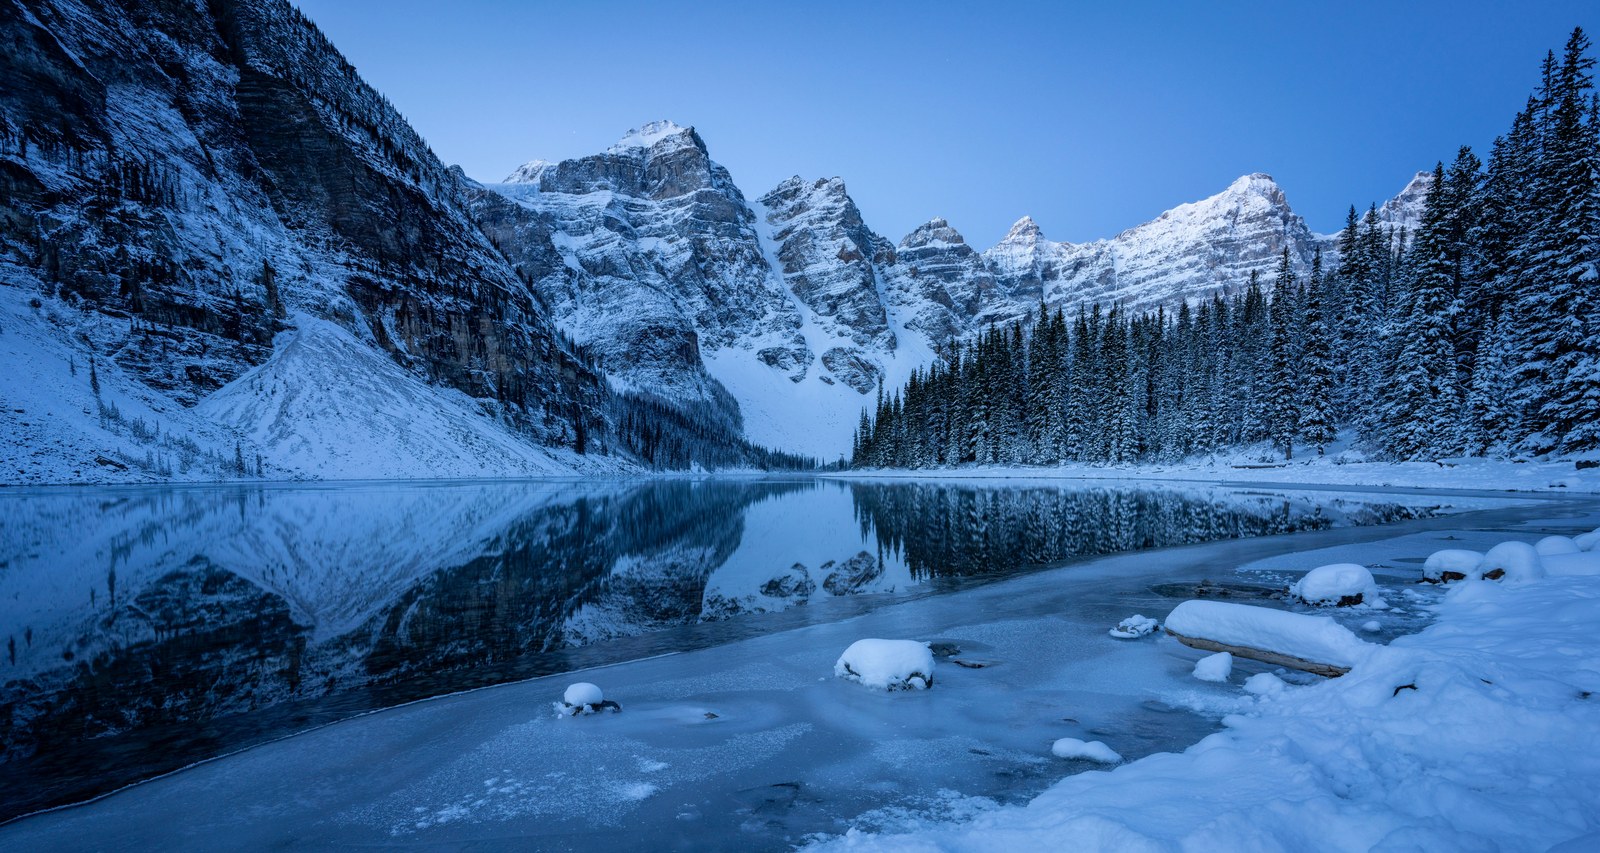
输入图像
同一输入与 prompt · image_static · gap 0.0545
image_static_photorealistic_aquatic_landscape_0070套件: image_static 指标: epipolar_error 场景: photorealistic / aquatic_landscape
Benchmark prompt
Camera pan left. A frozen lake with snow-covered mountains, evergreen trees, and distant peak. Everything in the scene remains completely motionless.
来源: generation_records
较高分: hy_worldplay_ar_image_test_balanced_5000_5s。较低分: motionctrl_image_static_official_default_tmp2。好坏标签仅比较 epipolar_error。
较高指标分 分数 0.9875 hy_worldplay_ar_image_test_balanced_5000_5s 内点 Sampson 误差中位数 0.0625
较低指标分 分数 0.9330 motionctrl_image_static_official_default_tmp2 内点 Sampson 误差中位数 0.3351
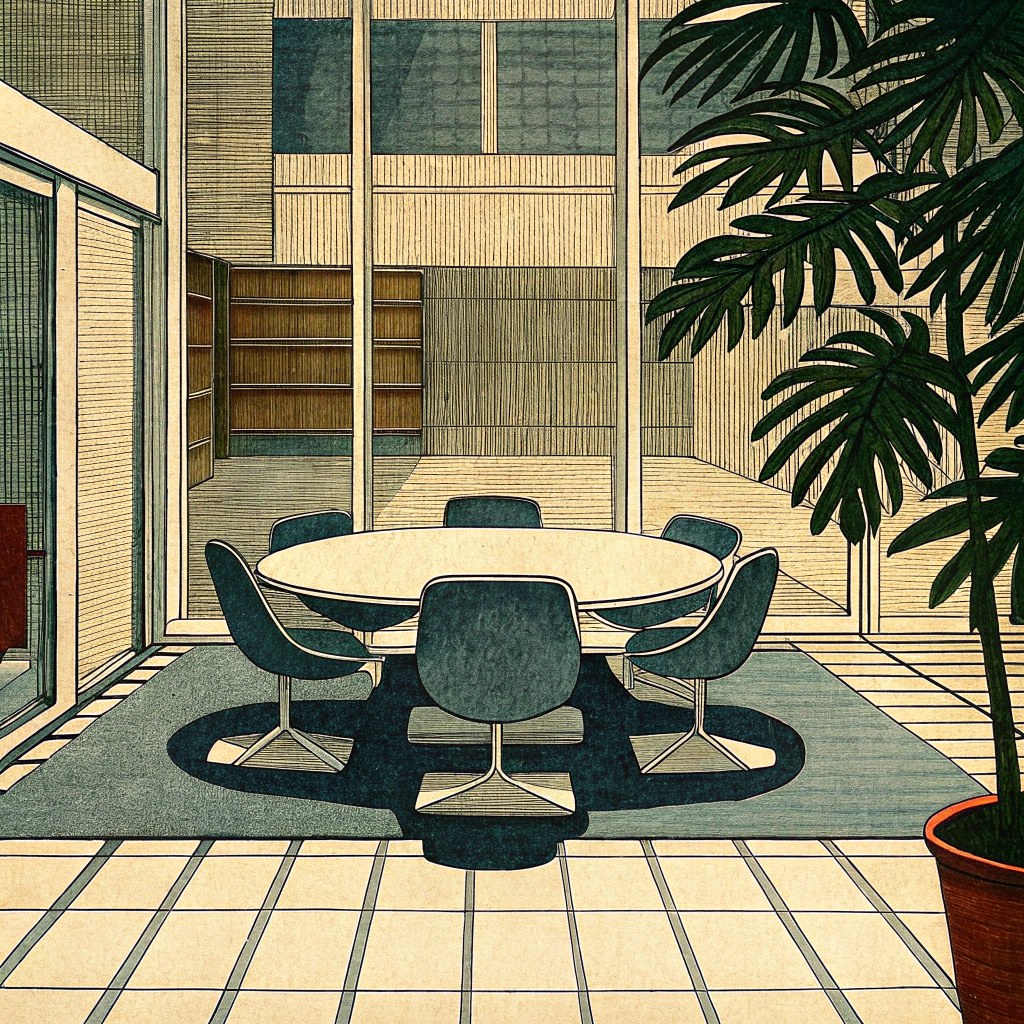
输入图像
同一输入与 prompt · image_static · gap 0.5392
image_static_stylized_workspaces_0008套件: image_static 指标: epipolar_inlier_rate 场景: stylized / workspaces
Benchmark prompt
Camera orbit left. A modern conference room with bookshelves, glass walls, and modern chairs. Everything in the scene remains completely motionless.
来源: generation_records
较高分: hy_worldplay_ar_distilled_image_test_balanced_5000_5s。较低分: matrix_game3_5s_image_static_dynamic。好坏标签仅比较 epipolar_inlier_rate。
较高指标分 分数 0.9507 hy_worldplay_ar_distilled_image_test_balanced_5000_5s 内点率 95.1%
较低指标分 分数 0.4115 matrix_game3_5s_image_static_dynamic 内点率 41.1%
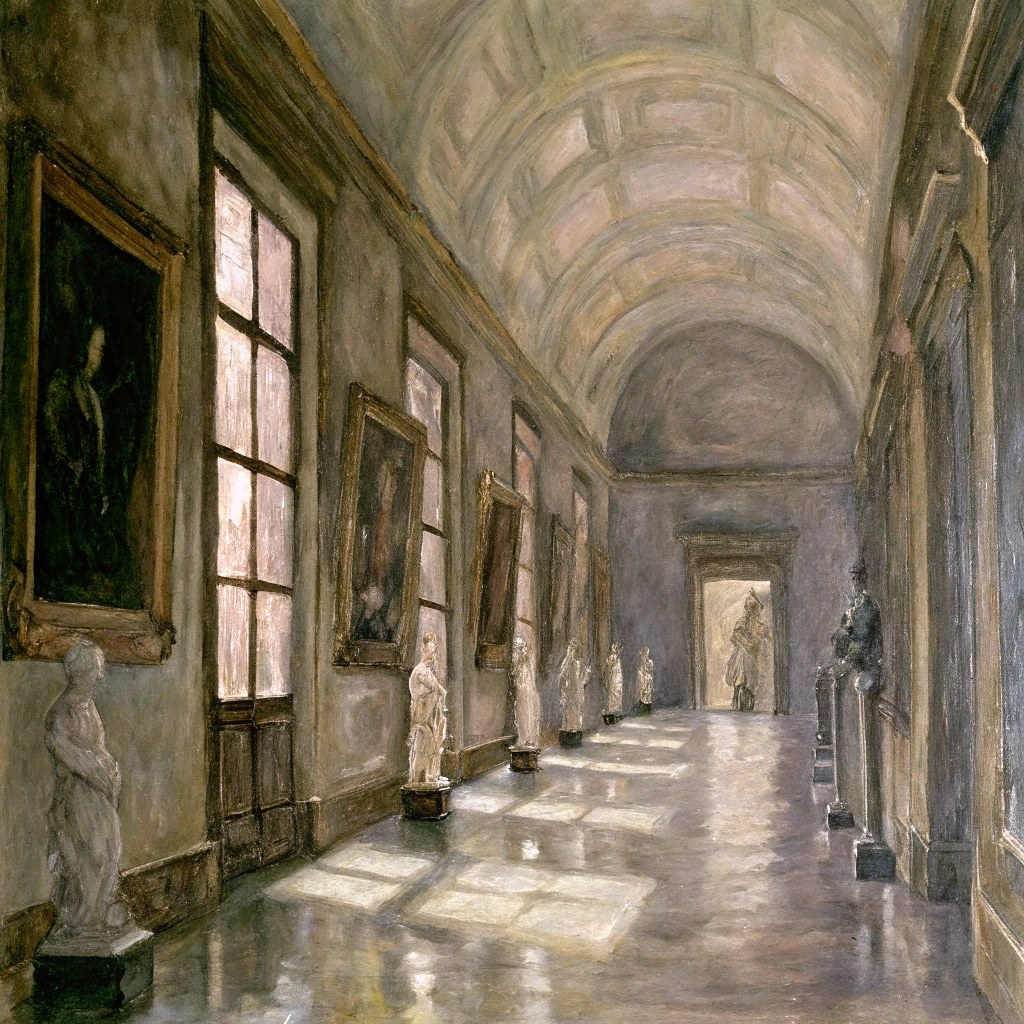
输入图像
同一输入与 prompt · image_static · gap 0.3882
image_static_stylized_public_spaces_0008套件: image_static 指标: feature_match_coverage 场景: stylized / public_spaces
Benchmark prompt
Camera orbit left. A gallery corridor with statues, paintings, and windows. Everything in the scene remains completely motionless.
来源: generation_records
较高分: astra_image_static。较低分: matrix_game3_5s_image_static_dynamic。好坏标签仅比较 feature_match_coverage。
较高指标分 分数 0.4870 astra_image_static 特征匹配覆盖率 48.7%
较低指标分 分数 0.0988 matrix_game3_5s_image_static_dynamic 特征匹配覆盖率 9.9%
输入图像
同一输入与 prompt · image_static · gap 0.0532
image_static_stylized_dining_spaces_0097套件: image_static 指标: epipolar_error 场景: stylized / dining_spaces
Benchmark prompt
Camera pull out. Dining spaces with wooden table, chairs, and window with curtains. Everything in the scene remains completely motionless.
来源: generation_records
较高分: cameractrl_image_static。较低分: dreamx_world_image_static。好坏标签仅比较 epipolar_error。
较高指标分 分数 0.9890 cameractrl_image_static 内点 Sampson 误差中位数 0.0549
较低指标分 分数 0.9358 dreamx_world_image_static 内点 Sampson 误差中位数 0.3209
输入图像
同一输入与 prompt · image_static · gap 0.2484
image_static_stylized_dining_spaces_0041套件: image_static 指标: epipolar_inlier_rate 场景: stylized / dining_spaces
Benchmark prompt
Camera pull out. A beachside path with sand, lanterns, and ocean. Camera pan left. A beachfront lounge with lounge chairs, palm trees, and ocean. Camera move left. A beach bar with bar counter, stools, and string lights.
来源: generation_records
较高分: luciddreamer-image-static-8gpu-20260613_151844。较低分: longcat-video-image-static-8gpu-20260612_133950。好坏标签仅比较 epipolar_inlier_rate。
较高指标分 分数 0.9290 luciddreamer-image-static-8gpu-20260613_151844 内点率 92.9%
较低指标分 分数 0.6806 longcat-video-image-static-8gpu-20260612_133950 内点率 68.1%
输入图像
同一输入与 prompt · image_static · gap 0.4055
image_static_stylized_suburb_0007套件: image_static 指标: feature_match_coverage 场景: stylized / suburb
Benchmark prompt
Camera pull out. A path intersection with trees, benches, and people. Everything in the scene remains completely motionless.
来源: generation_records
较高分: hy_worldplay_ar_image_test_balanced_5000_5s。较低分: dreamx_world_image_static。好坏标签仅比较 feature_match_coverage。
较高指标分 分数 0.4402 hy_worldplay_ar_image_test_balanced_5000_5s 特征匹配覆盖率 44.0%
较低指标分 分数 0.0348 dreamx_world_image_static 特征匹配覆盖率 3.5%
输入图像
同一输入与 prompt · image_static · gap 0.0705
image_static_stylized_verdant_landscape_0087套件: image_static 指标: epipolar_error 场景: stylized / verdant_landscape
Benchmark prompt
Camera pan left. A forest at sunset with trees, open field, and forest edge.
来源: generation_records
较高分: longcat-video-image-static-8gpu-20260612_133950。较低分: ac3d-image-static。好坏标签仅比较 epipolar_error。
较高指标分 分数 1.0000 longcat-video-image-static-8gpu-20260612_133950 内点 Sampson 误差中位数 0.0001
较低指标分 分数 0.9295 ac3d-image-static 内点 Sampson 误差中位数 0.3527
输入图像
同一输入与 prompt · image_static · gap 0.4548
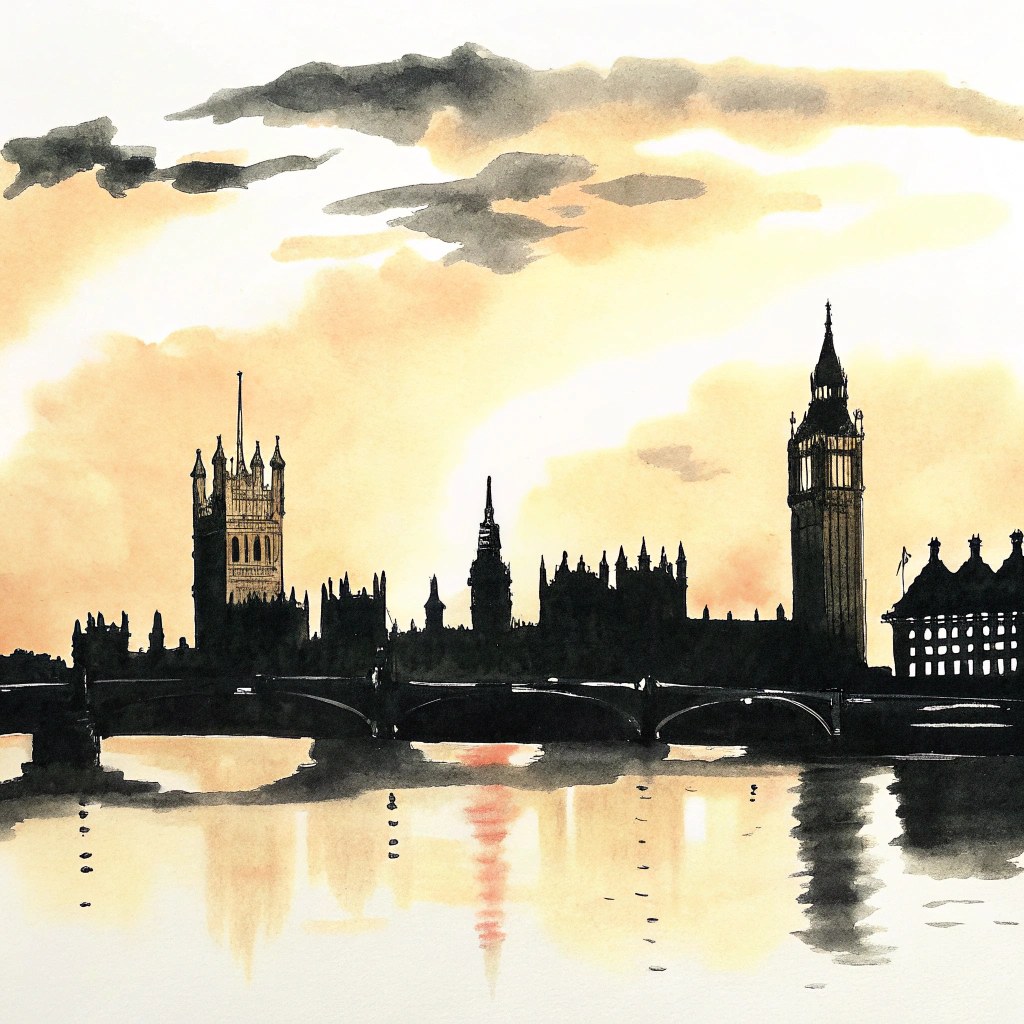
image_static_stylized_city_0021套件: image_static 指标: epipolar_inlier_rate 场景: stylized / city
Benchmark prompt
Camera move right. A cityscape silhouette with towers, buildings, and bridge. Everything in the scene remains completely motionless.
来源: generation_records
较高分: motionctrl_image_static_official_default_tmp2。较低分: astra_image_static。好坏标签仅比较 epipolar_inlier_rate。
较高指标分 分数 0.9696 motionctrl_image_static_official_default_tmp2 内点率 97.0%
较低指标分 分数 0.5148 astra_image_static 内点率 51.5%
输入图像
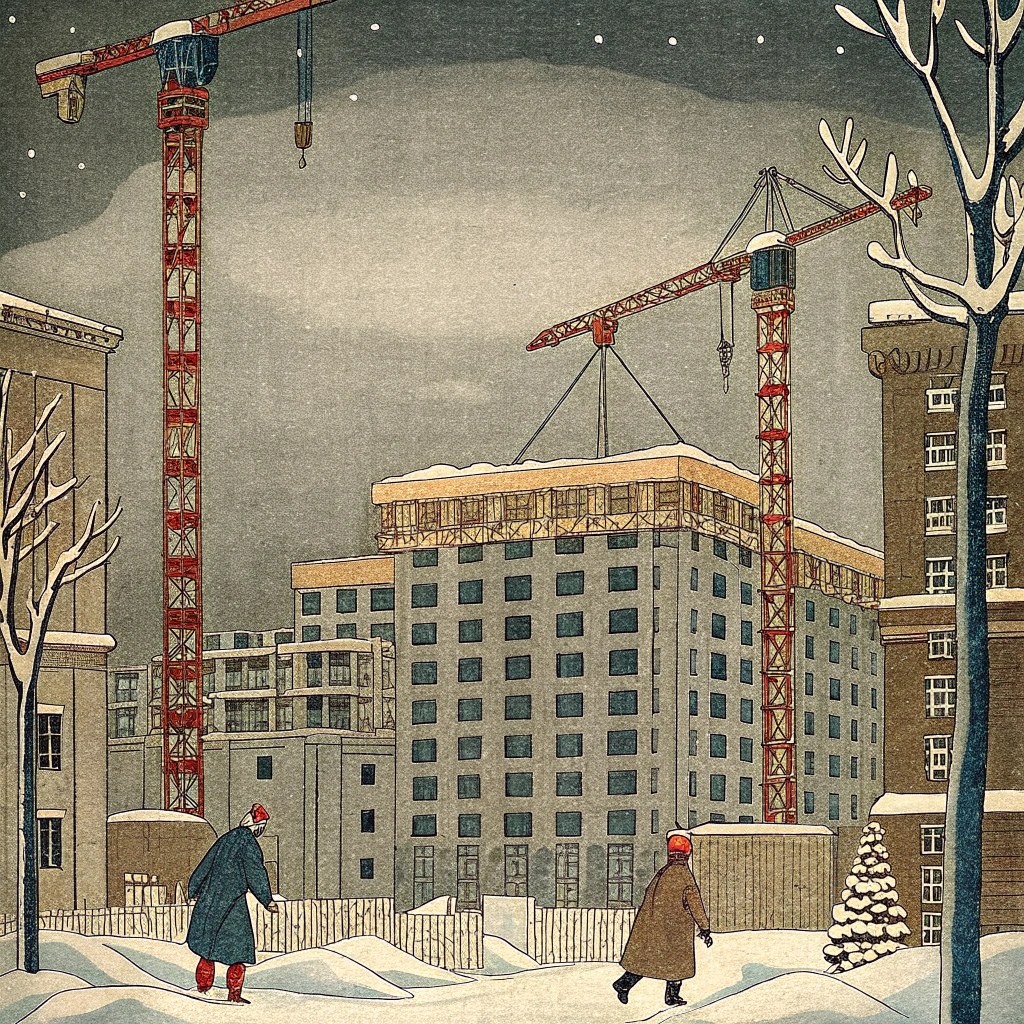
同一输入与 prompt · image_static · gap 0.0537
image_static_stylized_city_0051套件: image_static 指标: epipolar_error 场景: stylized / city
Benchmark prompt
Camera pan right. A city construction site with street, snow, and cars.
来源: generation_records
较高分: longcat-video-image-static-8gpu-20260612_133950。较低分: warp-as-history-image-static-8gpu-20260612_152000。好坏标签仅比较 epipolar_error。
较高指标分 分数 0.9920 longcat-video-image-static-8gpu-20260612_133950 内点 Sampson 误差中位数 0.0399
较低指标分 分数 0.9383 warp-as-history-image-static-8gpu-20260612_152000 内点 Sampson 误差中位数 0.3087
输入图像
同一输入与 prompt · image_static · gap 0.2243
image_static_stylized_aquatic_landscape_0123套件: image_static 指标: epipolar_inlier_rate 场景: stylized / aquatic_landscape
Benchmark prompt
Camera pan left. Dense trees with stone pathway and lake. Everything in the scene remains completely motionless.
来源: generation_records
较高分: hy_worldplay_ar_distilled_image_test_balanced_5000_5s。较低分: motionctrl_image_static_official_default_tmp2。好坏标签仅比较 epipolar_inlier_rate。
较高指标分 分数 0.9741 hy_worldplay_ar_distilled_image_test_balanced_5000_5s 内点率 97.4%
较低指标分 分数 0.7498 motionctrl_image_static_official_default_tmp2 内点率 75.0%
Sora Generates Videos with Stunning Geometrical Consistency
Xuanyi Li, Daquan Zhou, Chenxu Zhang, Shaodong Wei, Qibin Hou, and Ming-Ming Cheng.https://arxiv.org/abs/2402.17403
BibTeX @article { XuanyiLI2024Sora ,
title = { Sora Generates Videos with Stunning Geometrical Consistency } ,
author = { Xuanyi Li and Daquan Zhou and Chenxu Zhang and Shaodong Wei and Qibin Hou and Ming-Ming Cheng } ,
journal = { arXiv preprint arXiv:2402.17403 } ,
url = { https://arxiv.org/abs/2402.17403 } ,
Multiple View Geometry in Computer Vision
Hartley & Zisserman, Cambridge University Press, 2004.