long_sequence_dynamic_degree 是一个光流探针,用来判断长 rollout 是否仍有足够运动。long_sequence 后端先把视频切成 clip。RAFT-things 在约 8 Hz 采样的相邻帧之间估计光流。每个 transition 取光流幅值最高 5% 像素的均值。超过分辨率缩放阈值的 transition 足够多时,该 clip 记为有动态(1.0),否则为 0.0。
mk=mean(top5%∥fk∥)(1)
τ=6⋅256min(H,W),nτ=max(1,round(4⋅N/16))(2)
sdyn=1[∣{k:mk>τ}∣≥nτ](3)
N 是该 clip 的采样帧数。视频分是各 clip 分数在 {0,1} 上的均值。越高越好,表示更多 clip 仍保持动态。仅基于预测,不使用参考 rollout。在 memory_loop 上为 official 指标。共享运行时见 Long-Sequence 指标。
Audit manifest: docs/assets/metric_examples/longseq_memory_60s_examples_20260909.json.
 输入图像
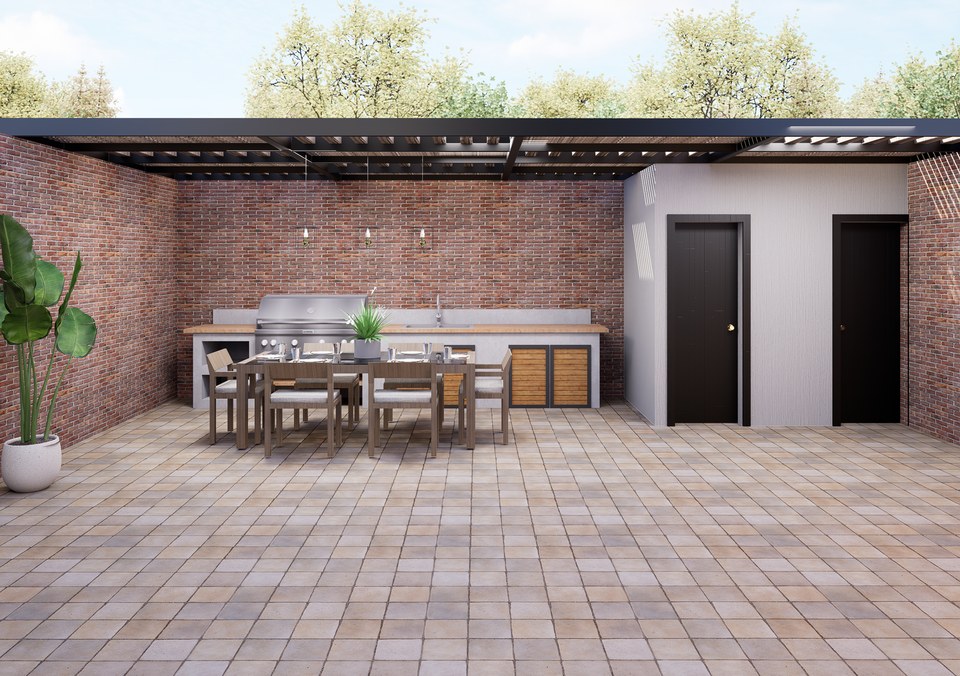
60 秒 memory_loop · 同一 benchmark case · gap 1.0000
memory-yaw_loop_360-memory_pool_479
套件: memory_loop场景: photorealistic / indoor / dining_spaces
基准 prompt target
Rotate the camera a full turn in place and come back to the starting view.
prompt source: memory_loop_prompt
较高分结果在整分钟里仍有足够的相机或场景运动;较低分结果接近静止。
较高指标分分数 1.0000 · official
较低指标分分数 0.0000 · official
 输入图像
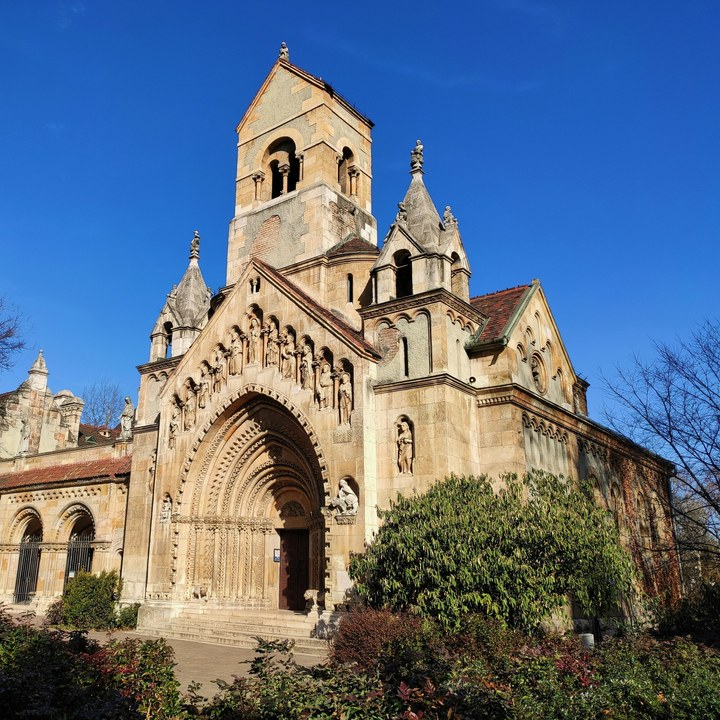
60 秒 memory_loop · 同一 benchmark case · gap 1.0000
memory-dolly_loop-memory_pool_002
套件: memory_loop场景: photorealistic / outdoor / city
基准 prompt target
Move the camera forward through the scene, then back to where it started.
prompt source: memory_loop_prompt
较高分结果在整分钟里仍有足够的相机或场景运动;较低分结果接近静止。
较高指标分分数 1.0000 · official
较低指标分分数 0.0000 · official
 输入图像
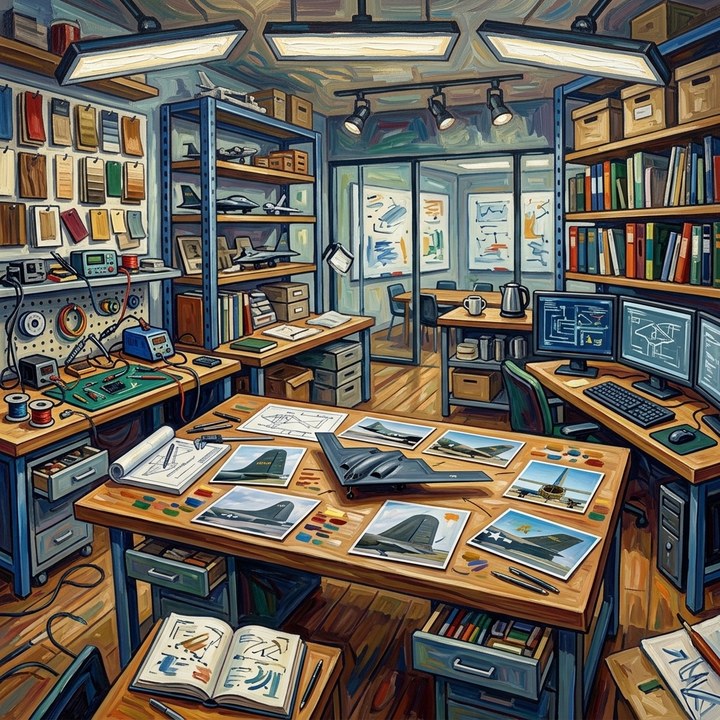
60 秒 memory_loop · 同一 benchmark case · gap 1.0000
memory-yaw_loop_180-memory_pool_427
套件: memory_loop场景: stylized / indoor / workspaces
基准 prompt target
Turn the camera to the right, then turn back to the starting view.
prompt source: memory_loop_prompt
较高分结果在整分钟里仍有足够的相机或场景运动;较低分结果接近静止。
较高指标分分数 1.0000 · official
较低指标分分数 0.0000 · official
 输入图像
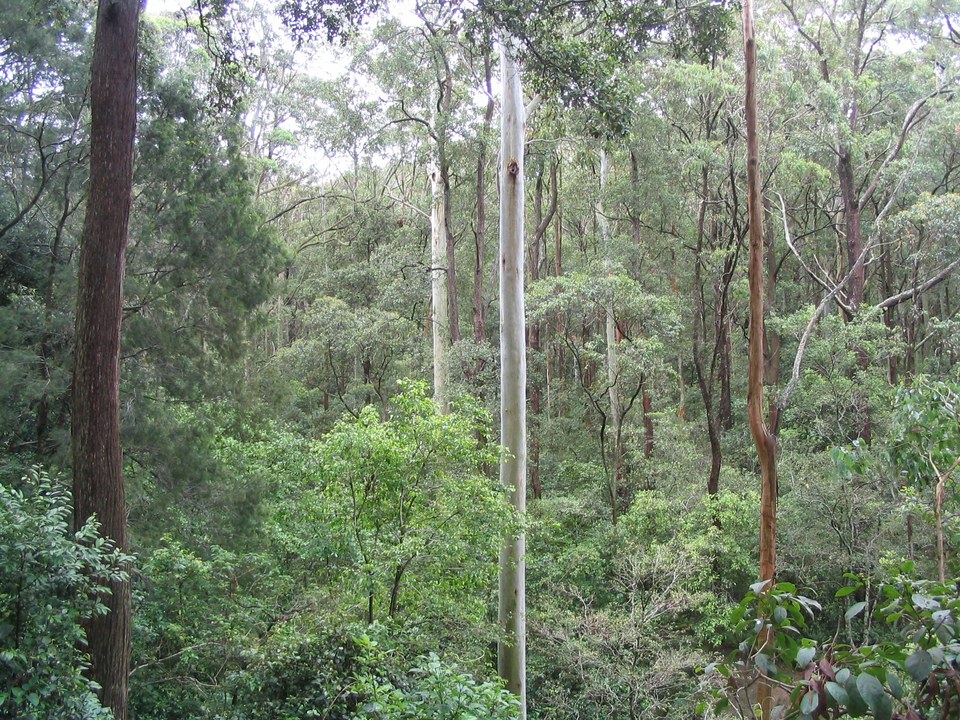
60 秒 memory_loop · 同一 benchmark case · gap 1.0000
memory-palindrome_loop-memory_pool_281
套件: memory_loop场景: photorealistic / outdoor / verdant_landscape
基准 prompt target
Move forward, turn and continue, then retrace the whole path back.
prompt source: memory_loop_prompt
较高分结果在整分钟里仍有足够的相机或场景运动;较低分结果接近静止。
较高指标分分数 1.0000 · official
较低指标分分数 0.0000 · official
 输入图像
60 秒 memory_loop · 同一 benchmark case · gap 1.0000
memory-yaw_loop_360-memory_pool_477
套件: memory_loop场景: photorealistic / outdoor / aquatic_landscape
基准 prompt target
Rotate the camera a full turn in place and come back to the starting view.
prompt source: memory_loop_prompt
较高分结果在整分钟里仍有足够的相机或场景运动;较低分结果接近静止。
较高指标分分数 1.0000 · official
较低指标分分数 0.0000 · official

