Skip to content

Rollout Imaging Drift

Measures maximum chronological relative drawdown in MUSIQ-SPAQ imaging-quality scores. Scores are grouped in temporal order (default 10 segments; equal-time bins when timestamps are known). For segment means qjq_j:

pj=max⁡(q0,…,qj)(1)p_j = \max(q_0,\ldots,q_j) \tag{1} drift=max⁡jpj−qjmax⁡(pj, ε)(2)\mathrm{drift} = \max_j \frac{p_j - q_j}{\max(p_j,\,\varepsilon)} \tag{2}

Lower is better, within [0,1][0, 1], with ε=10−12\varepsilon = 10^{-12}. Input scores must be finite and nonnegative, with at least two time points and two temporal segments. Improving quality has zero degradation; a decline is penalized. A dip followed by recovery still records drawdown, while signed endpoint change and slope describe recovery separately.

Mean absolute quality is also reported: constant low quality is not high quality. Nonfinite observations are not silently removed to compress time. If FPS is unknown, chronological drift is available but per-second slope is null. This is an official quality metric; it does not measure memory. Backend: quality_drift.


Audit manifest: docs/assets/metric_examples/longseq_memory_60s_examples_20260909.json.

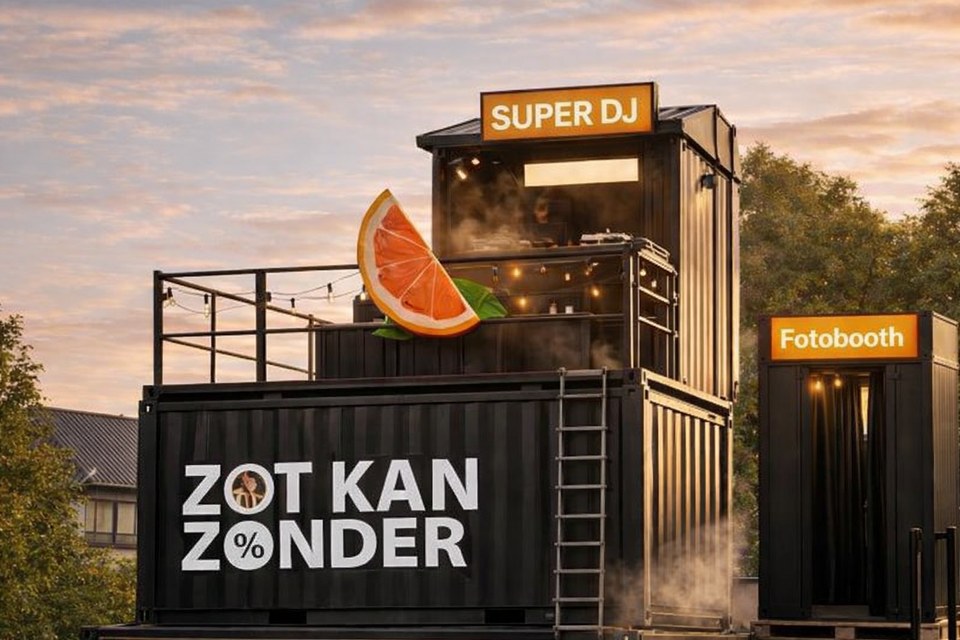
Input image: memory-dolly_loop-memory_pool_371
Input image
60s memory_loop · illustrative same input

memory-dolly_loop-memory_pool_371

Suite: memory_loopScene: photorealistic / outdoor / city
Benchmark prompt target

Move the camera forward through the scene, then back to where it started.

prompt source: memory_loop_prompt

Model result videos will be available with the ModelScope release. / 模型推理视频将在 ModelScope 方案上线后提供。

Output Arollout_imaging_drift

Model result videos will be available with the ModelScope release. / 模型推理视频将在 ModelScope 方案上线后提供。

Output Brollout_imaging_drift
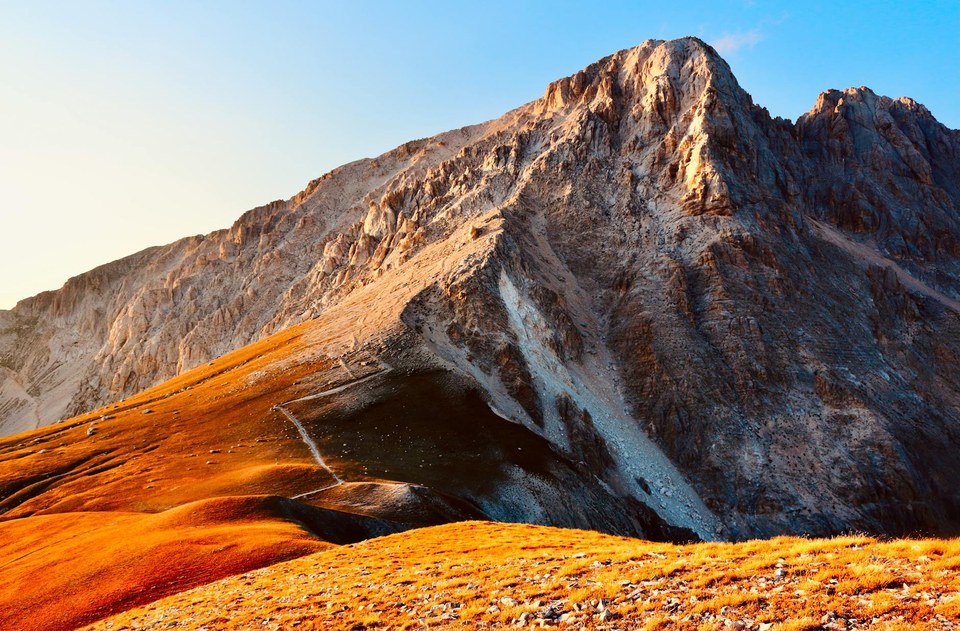
Input image: memory-yaw_loop_180-memory_pool_040
Input image
60s memory_loop · illustrative same input

memory-yaw_loop_180-memory_pool_040

Suite: memory_loopScene: photorealistic / outdoor / terrestrial_landscape
Benchmark prompt target

Turn the camera to the right, then turn back to the starting view.

prompt source: memory_loop_prompt

Model result videos will be available with the ModelScope release. / 模型推理视频将在 ModelScope 方案上线后提供。

Output Arollout_imaging_drift

Model result videos will be available with the ModelScope release. / 模型推理视频将在 ModelScope 方案上线后提供。

Output Brollout_imaging_drift
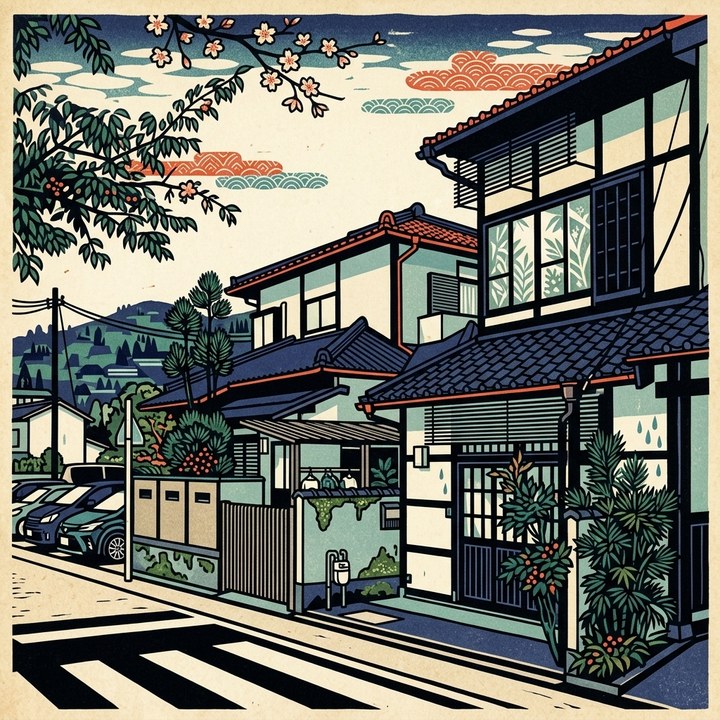
Input image: memory-dolly_loop-memory_pool_238
Input image
60s memory_loop · illustrative same input

memory-dolly_loop-memory_pool_238

Suite: memory_loopScene: stylized / outdoor / suburb
Benchmark prompt target

Move the camera forward through the scene, then back to where it started.

prompt source: memory_loop_prompt

Model result videos will be available with the ModelScope release. / 模型推理视频将在 ModelScope 方案上线后提供。

Output Arollout_imaging_drift

Model result videos will be available with the ModelScope release. / 模型推理视频将在 ModelScope 方案上线后提供。

Output Brollout_imaging_drift
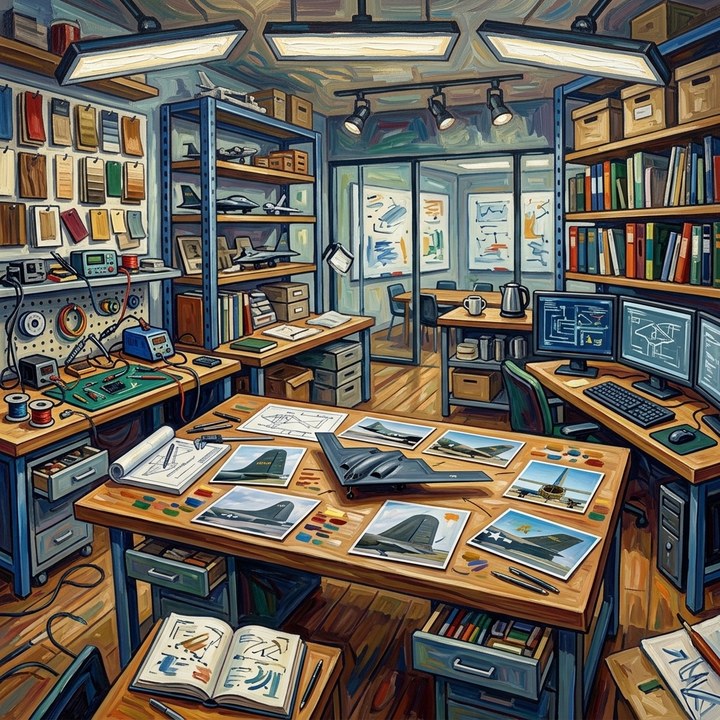
Input image: memory-yaw_loop_180-memory_pool_427
Input image
60s memory_loop · illustrative same input

memory-yaw_loop_180-memory_pool_427

Suite: memory_loopScene: stylized / indoor / workspaces
Benchmark prompt target

Turn the camera to the right, then turn back to the starting view.

prompt source: memory_loop_prompt

Model result videos will be available with the ModelScope release. / 模型推理视频将在 ModelScope 方案上线后提供。

Output Arollout_imaging_drift

Model result videos will be available with the ModelScope release. / 模型推理视频将在 ModelScope 方案上线后提供。

Output Brollout_imaging_drift
Input image: memory-double_yaw_loop-memory_pool_320
Input image
60s memory_loop · illustrative same input

memory-double_yaw_loop-memory_pool_320

Suite: memory_loopScene: photorealistic / indoor / living_spaces
Benchmark prompt target

Turn away and back to the start twice in a row.

prompt source: memory_loop_prompt

Model result videos will be available with the ModelScope release. / 模型推理视频将在 ModelScope 方案上线后提供。

Output Arollout_imaging_drift

Model result videos will be available with the ModelScope release. / 模型推理视频将在 ModelScope 方案上线后提供。

Output Brollout_imaging_drift