Here et,start,i and et,end,i are positional errors against the target at the two ends of observed interval i, within its constant-action segment; wi=1/FPS. ATEt is the trapezoidal time integral divided by total observed duration, a time-weighted mean error rather than an unnormalized integral. No arc-length resampling is used. The default minimum path normalizer is ℓmin=0.5 pose units. ℓobs is the observed path length. nmismatch counts intervals whose commanded and observed translation-activity states disagree; nactive counts intervals with commanded or observed translation.
Observed translation activity means speed exceeds move_speed_threshold=0.06 pose units/second by default. Commanded but stalled motion and uncommanded motion contribute to activity error; observation gaps are missing data, not freezes.
Lower raw error is better. If translation is neither commanded nor observed, the metric is not_applicable, not a perfect score. Target amplitude is prediction-derived (amplitude_calibrated=false); scale and speed accuracy are not independently validated. Backend: pose_action; official metric.
Move the camera forward through the scene, then back to where it started.
prompt source: memory_loop_prompt
Compare recovered translation over the 60s path: requested movement, stalls, and extra movement all affect this score. Visual quality is measured separately.
Model result videos will be available with the ModelScope release. / 模型推理视频将在 ModelScope 方案上线后提供。
Higher metric scoreScore 0.8450 · official
Model result videos will be available with the ModelScope release. / 模型推理视频将在 ModelScope 方案上线后提供。
Lower metric scoreScore 0.5427 · official
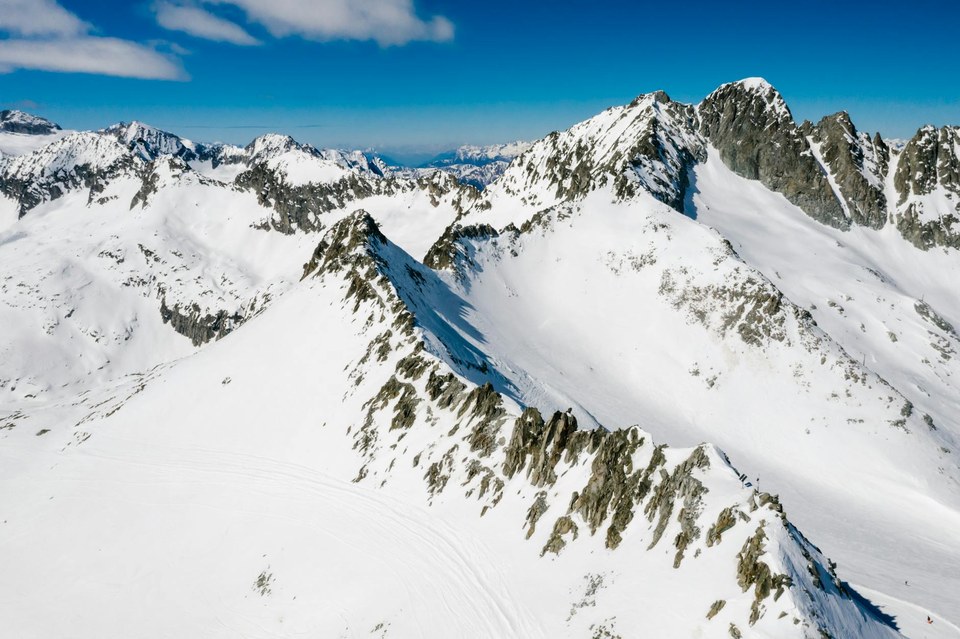
Input image
60s memory_loop · same benchmark case · gap 0.4043
Move forward, turn and continue, then retrace the whole path back.
prompt source: memory_loop_prompt
Compare recovered translation over the 60s path: requested movement, stalls, and extra movement all affect this score. Visual quality is measured separately.
Model result videos will be available with the ModelScope release. / 模型推理视频将在 ModelScope 方案上线后提供。
Higher metric scoreScore 0.7876 · official
Model result videos will be available with the ModelScope release. / 模型推理视频将在 ModelScope 方案上线后提供。
Lower metric scoreScore 0.3834 · official
Input image
60s memory_loop · same benchmark case · gap 0.2480
Compare recovered translation over the 60s path: requested movement, stalls, and extra movement all affect this score. Visual quality is measured separately.
Model result videos will be available with the ModelScope release. / 模型推理视频将在 ModelScope 方案上线后提供。
Higher metric scoreScore 0.8547 · official
Model result videos will be available with the ModelScope release. / 模型推理视频将在 ModelScope 方案上线后提供。
Lower metric scoreScore 0.6067 · official
Input image
60s memory_loop · same benchmark case · gap 0.3874
Move the camera forward through the scene, then back to where it started.
prompt source: memory_loop_prompt
Compare recovered translation over the 60s path: requested movement, stalls, and extra movement all affect this score. Visual quality is measured separately.
Model result videos will be available with the ModelScope release. / 模型推理视频将在 ModelScope 方案上线后提供。
Higher metric scoreScore 0.8406 · official
Model result videos will be available with the ModelScope release. / 模型推理视频将在 ModelScope 方案上线后提供。
Lower metric scoreScore 0.4532 · official
Input image
60s memory_loop · same benchmark case · gap 0.3420
Rotate the camera a full turn in place and come back to the starting view.
prompt source: memory_loop_prompt
Compare recovered translation over the 60s path: requested movement, stalls, and extra movement all affect this score. Visual quality is measured separately.
Model result videos will be available with the ModelScope release. / 模型推理视频将在 ModelScope 方案上线后提供。
Higher metric scoreScore 0.8744 · official
Model result videos will be available with the ModelScope release. / 模型推理视频将在 ModelScope 方案上线后提供。