Skip to content

Color Temperature Consistency

This metric evaluates the consistency of environmental atmosphere (color-temperature logic) in generated videos. We analyze the Hue channel in HSV color space: the hue spectrum [0,179][0, 179] is divided into 77 core intervals to construct a hue feature vector ht∈R7\mathbf{h}_t \in \mathbb{R}^{7}. We then compute a weighted perceptual similarity of the full sequence relative to the initial frame. To balance global constancy and local transition, the similarity at frame tt (t≥2t \geq 2) is the arithmetic mean of current-to-first and current-to-previous similarities. The similarity S(⋅,⋅)S(\cdot, \cdot) follows the cosine inner product (same as Eq. (3) in the brightness-distribution metric):

S(a,b)=a⋅b∥a∥ ∥b∥=∑i=1naibi∑i=1nai2 ∑i=1nbi2(3)S(a, b) = \frac{a \cdot b}{\|a\|\,\|b\|} = \frac{\sum_{i=1}^{n} a_i b_i}{ \sqrt{\sum_{i=1}^{n} a_i^2}\,\sqrt{\sum_{i=1}^{n} b_i^2} } \tag{3} Sˉt=S(ht,h1)+S(ht,ht−1)2(7)\bar{S}_t = \frac{ S(\mathbf{h}_t, \mathbf{h}_1) + S(\mathbf{h}_t, \mathbf{h}_{t-1}) }{ 2 } \tag{7}

For each frame ItI_t, RGB is converted to HSV; a saturation-weighted histogram over 77 hue bins on [0,180)[0, 180) is normalized to form ht\mathbf{h}_t (WorldAtlas default hue_bins=7).

The final score uses a normalized exponentially decaying weighted sum, where weights w^′(d)\hat{w}'(d) are an improved variant of w^(d)\hat{w}(d) with faster decay (β>α\beta > \alpha), and similarities are passed through the modified Softmax transform T(⋅)T(\cdot) (Eq. (4), default λ=4.0\lambda = 4.0):

T(x)=eλx−1eλ−1,λ>0(4)T(x) = \frac{e^{\lambda x} - 1}{e^{\lambda} - 1}, \quad \lambda > 0 \tag{4} w′(d)=e−β⋅d,w^′(d)=w′(d)∑k=1T−1w′(k)(β>0)(8)w'(d) = e^{-\beta \cdot d}, \qquad \hat{w}'(d) = \frac{w'(d)}{\sum_{k=1}^{T-1} w'(k)} \quad (\beta > 0) \tag{8}

Here d∈[1,T−1]d \in [1, T-1] is the frame distance (d=1d=1 for the second frame relative to the first), and β\beta is the decay coefficient. The default β=0.10\beta = 0.10 exceeds the brightness metric’s α=0.05\alpha = 0.05, so w^′(d)\hat{w}'(d) decays faster than w^(d)\hat{w}(d) and long-video color drift is penalized more strongly. The comprehensive score is:

SColor=∑d=1T−1w^′(d)⋅T ⁣(Sˉd+1)(9)S_{\mathrm{Color}} = \sum_{d=1}^{T-1} \hat{w}'(d) \cdot T\!\left(\bar{S}_{d+1}\right) \tag{9}

In WorldAtlas this algorithm is implemented as the official metric color_temperature_constraint (hue_distribution backend). Under the default normalization config, raw and normalized outputs lie in [0,1][0,1] with higher is better. The legacy scalar alias color_temperature_consistency is documented for compatibility; use the configured canonical metric to avoid double counting.


Audit manifest: docs/assets/metric_examples/curated_same_case_manifest.json.

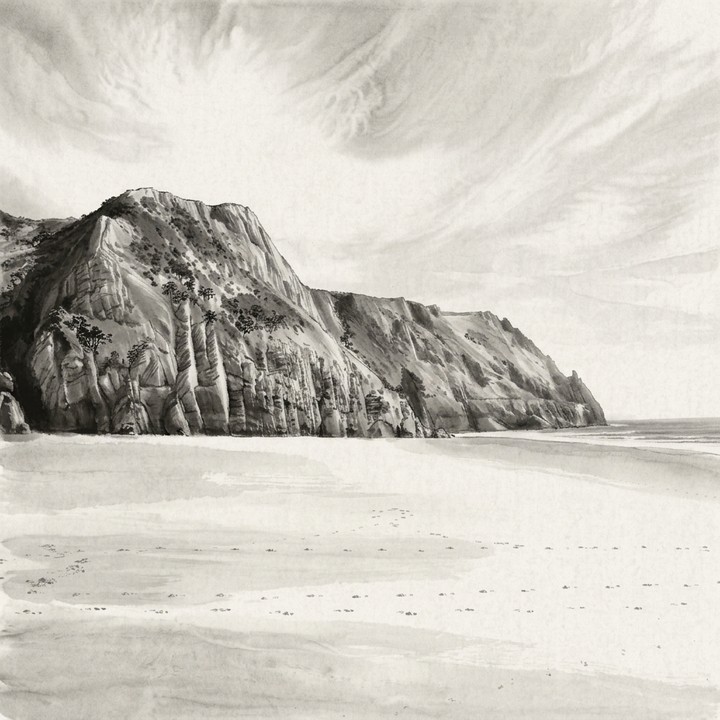
Input image: image_static_stylized_aquatic_landscape_0098
Input image
Input verified · same benchmark case · gap 0.8068

image_static_stylized_aquatic_landscape_0098

Suite: image_staticScene: stylized / outdoor / aquatic_landscape
Benchmark prompt target

Camera pan left. An aquatic landscape with beach, cliffs, and ocean.

prompt source: prompt_target

Both first frames passed geometric matching against the displayed input; labels compare this metric only.

Model result videos will be available with the ModelScope release. / 模型推理视频将在 ModelScope 方案上线后提供。

Higher metric scoreScore 0.9983

Model result videos will be available with the ModelScope release. / 模型推理视频将在 ModelScope 方案上线后提供。

Lower metric scoreScore 0.1915
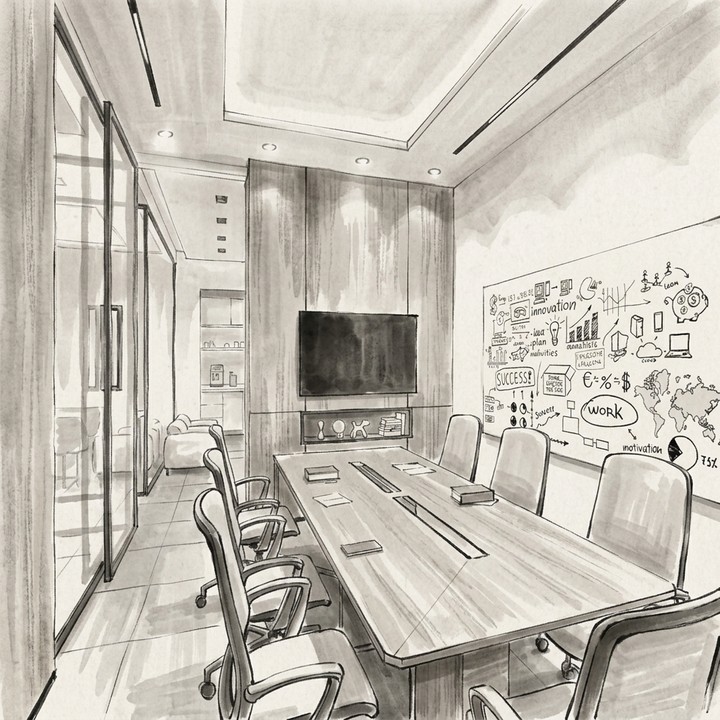
Input image: image_static_stylized_workspaces_0088
Input image
Input verified · same benchmark case · gap 0.8132

image_static_stylized_workspaces_0088

Suite: image_staticScene: stylized / indoor / workspaces
Benchmark prompt target

Camera pan right. A modern conference room with couch, coffee table, and bookshelves.

prompt source: prompt_target

Both first frames passed geometric matching against the displayed input; labels compare this metric only.

Model result videos will be available with the ModelScope release. / 模型推理视频将在 ModelScope 方案上线后提供。

Higher metric scoreScore 0.9998

Model result videos will be available with the ModelScope release. / 模型推理视频将在 ModelScope 方案上线后提供。

Lower metric scoreScore 0.1866
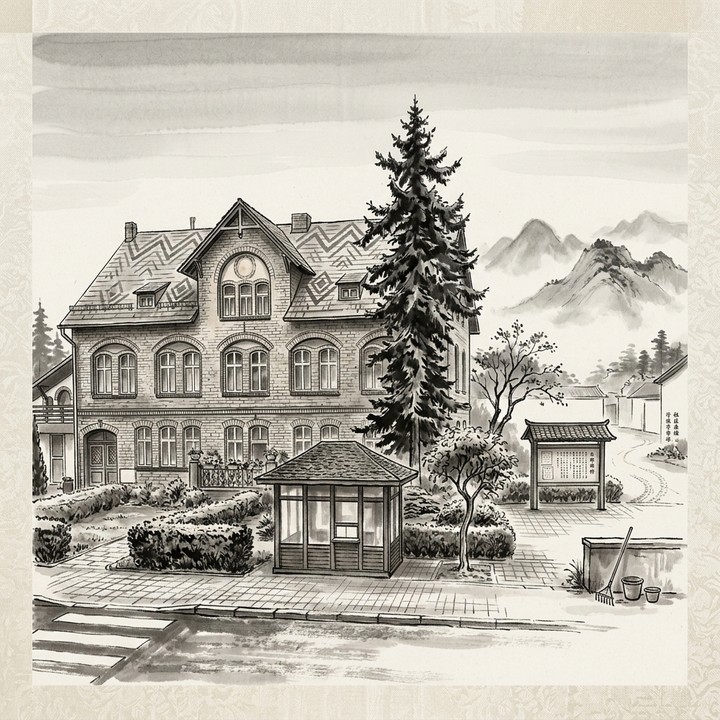
Input image: image_static_stylized_suburb_0132
Input image
Input verified · same benchmark case · gap 0.6806

image_static_stylized_suburb_0132

Suite: image_staticScene: stylized / outdoor / suburb
Benchmark prompt target

Camera move right. A suburban street with houses, trees, and road.

prompt source: prompt_target

Both first frames passed geometric matching against the displayed input; labels compare this metric only.

Model result videos will be available with the ModelScope release. / 模型推理视频将在 ModelScope 方案上线后提供。

Higher metric scoreScore 0.9968

Model result videos will be available with the ModelScope release. / 模型推理视频将在 ModelScope 方案上线后提供。

Lower metric scoreScore 0.3162