Skip to content

Background Consistency

Background Consistency measures temporal stability of scene appearance in a generated video. Large shifts in background layout, texture, or global scene context between adjacent frames lower the score.

For each decoded frame xix_i, CLIP ViT-B/32 extracts a normalized embedding fif_i. The metric averages cosine similarity over consecutive frame pairs:

Sbg=1N−1∑i=1N−1cos⁡(fi,fi+1)(1)S_{\mathrm{bg}} = \frac{1}{N-1}\sum_{i=1}^{N-1}\cos(f_i, f_{i+1}) \tag{1}

where NN is the number of evaluated frames and cos⁡(⋅,⋅)\cos(\cdot,\cdot) is cosine similarity between L2-normalized CLIP image features. WorldAtlas clamps SbgS_{\mathrm{bg}} to [0,1][0, 1]; higher values indicate more stable backgrounds. The metric is prediction-only and requires at least two frames.


Audit manifest: docs/assets/metric_examples/curated_same_case_manifest.json.

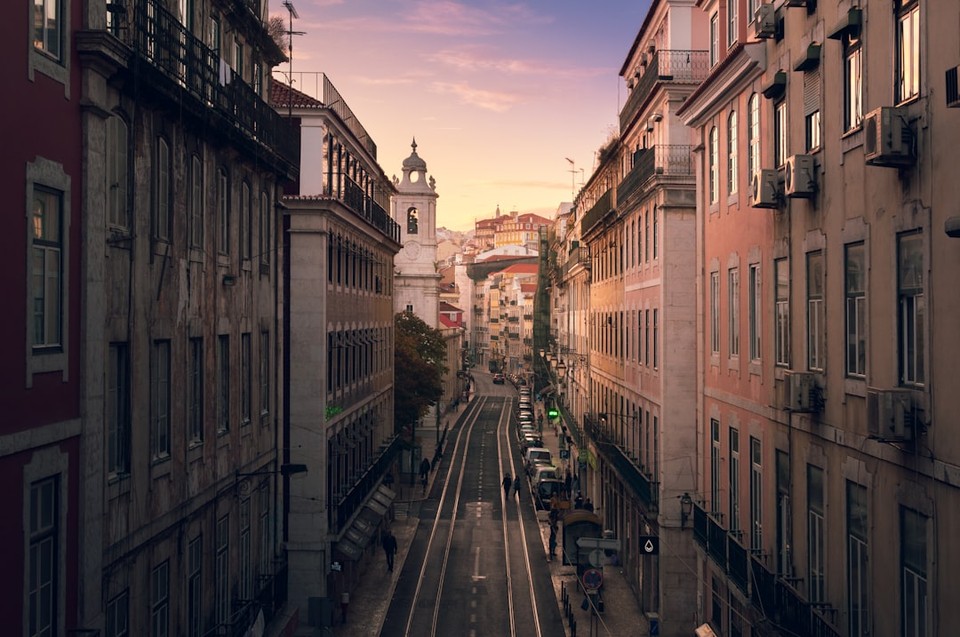
Input image: image_static_photorealistic_city_0043
Input image
Input verified · same benchmark case · gap 0.1517

image_static_photorealistic_city_0043

Suite: image_staticScene: photorealistic / outdoor / city
Benchmark prompt target

Camera orbit left. A narrow city street with historic buildings, street corner, and streetlights.

prompt source: prompt_target

Both first frames passed geometric matching against the displayed input; labels compare this metric only.

Model result videos will be available with the ModelScope release. / 模型推理视频将在 ModelScope 方案上线后提供。

Higher metric scoreScore 0.9849Mean adjacent-frame similarity: 0.9849

Model result videos will be available with the ModelScope release. / 模型推理视频将在 ModelScope 方案上线后提供。

Lower metric scoreScore 0.8333Mean adjacent-frame similarity: 0.8333
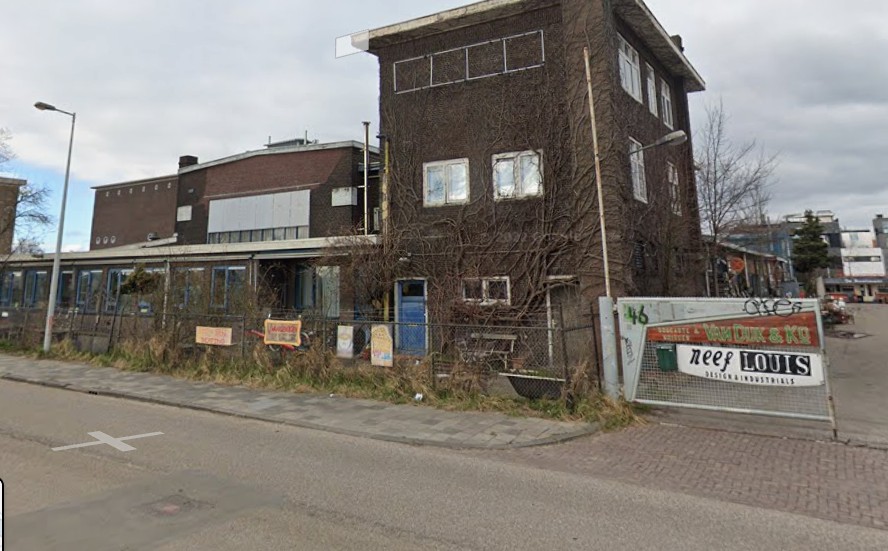
Input image: image_static_photorealistic_city_0041
Input image
Input verified · same benchmark case · gap 0.1444

image_static_photorealistic_city_0041

Suite: image_staticScene: photorealistic / outdoor / city
Benchmark prompt target

Camera move right. An old industrial building with adjacent street, buildings, and parked cars.

prompt source: prompt_target

Both first frames passed geometric matching against the displayed input; labels compare this metric only.

Model result videos will be available with the ModelScope release. / 模型推理视频将在 ModelScope 方案上线后提供。

Higher metric scoreScore 0.9882Mean adjacent-frame similarity: 0.9882

Model result videos will be available with the ModelScope release. / 模型推理视频将在 ModelScope 方案上线后提供。

Lower metric scoreScore 0.8437Mean adjacent-frame similarity: 0.8437
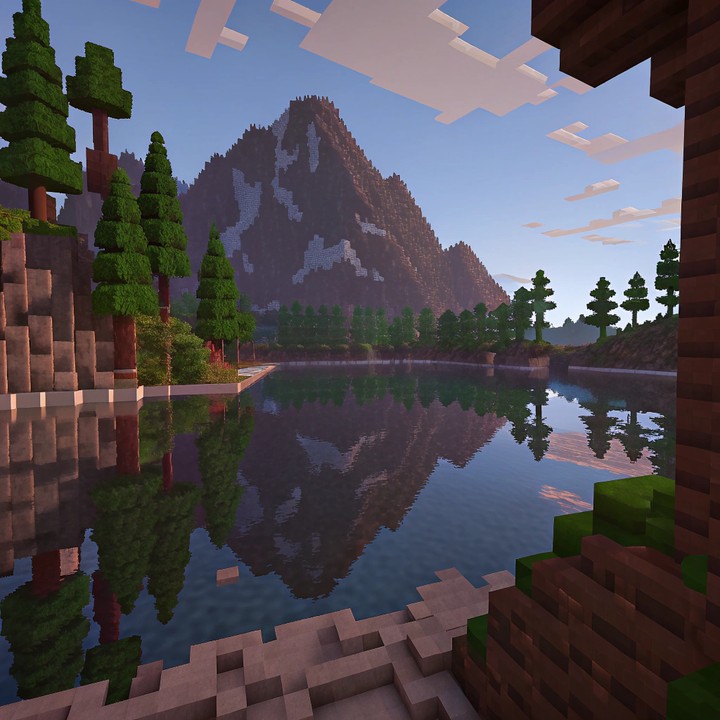
Input image: image_static_stylized_aquatic_landscape_0063
Input image
Input verified · same benchmark case · gap 0.1793

image_static_stylized_aquatic_landscape_0063

Suite: image_staticScene: stylized / outdoor / aquatic_landscape
Benchmark prompt target

Camera move right. A stylized lake with trees, hills, and clouds.

prompt source: prompt_target

Both first frames passed geometric matching against the displayed input; labels compare this metric only.

Model result videos will be available with the ModelScope release. / 模型推理视频将在 ModelScope 方案上线后提供。

Higher metric scoreScore 0.9933Mean adjacent-frame similarity: 0.9933

Model result videos will be available with the ModelScope release. / 模型推理视频将在 ModelScope 方案上线后提供。

Lower metric scoreScore 0.8140Mean adjacent-frame similarity: 0.8140