reconstruction_consistency is the shared compute unit behind the two public metrics geometric_consistency and photometric_consistency. Depth-Anything-3 (DA3) recovers depth and camera poses from prediction frames, builds a colored point cloud, and scores how consistently those points reproject across views. It requires only the prediction itself—no reference video or geometry ground truth.
Unlike the older World-R1 Gaussian-splat + LPIPS S_recon formulation, and unlike the WorldLens novel_view_consistency pipeline that scores pre-rendered reconstruction videos with optical-flow-warped LPIPS, this metric runs DA3 directly on prediction frames (infer_gs = false), builds a point cloud from depth maps, estimated poses, and RGB frames, and checks whether cross-frame reprojection agrees with the predicted depth. It therefore measures geometric self-consistency under a reconstruction path, not prompt following, perceptual quality, or reference-video fidelity.
For each frame, the backend reprojects points observed in other frames into the current view and computes geometric error (median relative depth mismatch between reprojected depth and the predicted depth map) and photometric error (PSNR between z-buffer rendered colors and the original frame). The headline score is geometric consistency:
Three cases each illustrate Geometric Consistency and Photometric Consistency. Every higher-scoring output moves visibly. Scores apply only to the metric named in each case.
Audit manifest: docs/assets/metric_examples/missing_pages_examples_20260824.json.
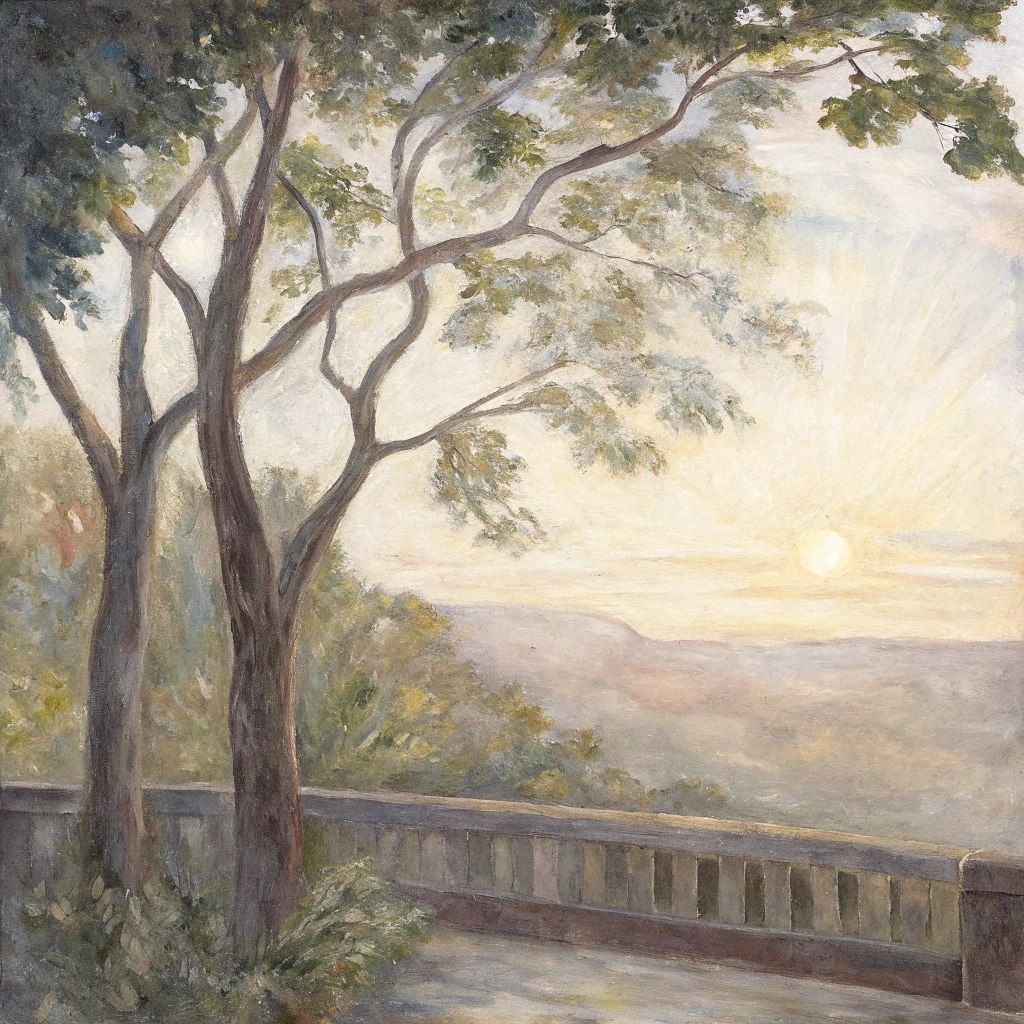
Camera pan left. A verdant landscape with trees, extended terrace, and foliage.
prompt source: report_details
The higher-scoring side has visible camera or scene motion. Both first frames passed geometric matching against the same input. This pair compares geometric_consistency only.
Model result videos will be available with the ModelScope release. / 模型推理视频将在 ModelScope 方案上线后提供。
Higher metric scoreScore 0.9909
Model result videos will be available with the ModelScope release. / 模型推理视频将在 ModelScope 方案上线后提供。
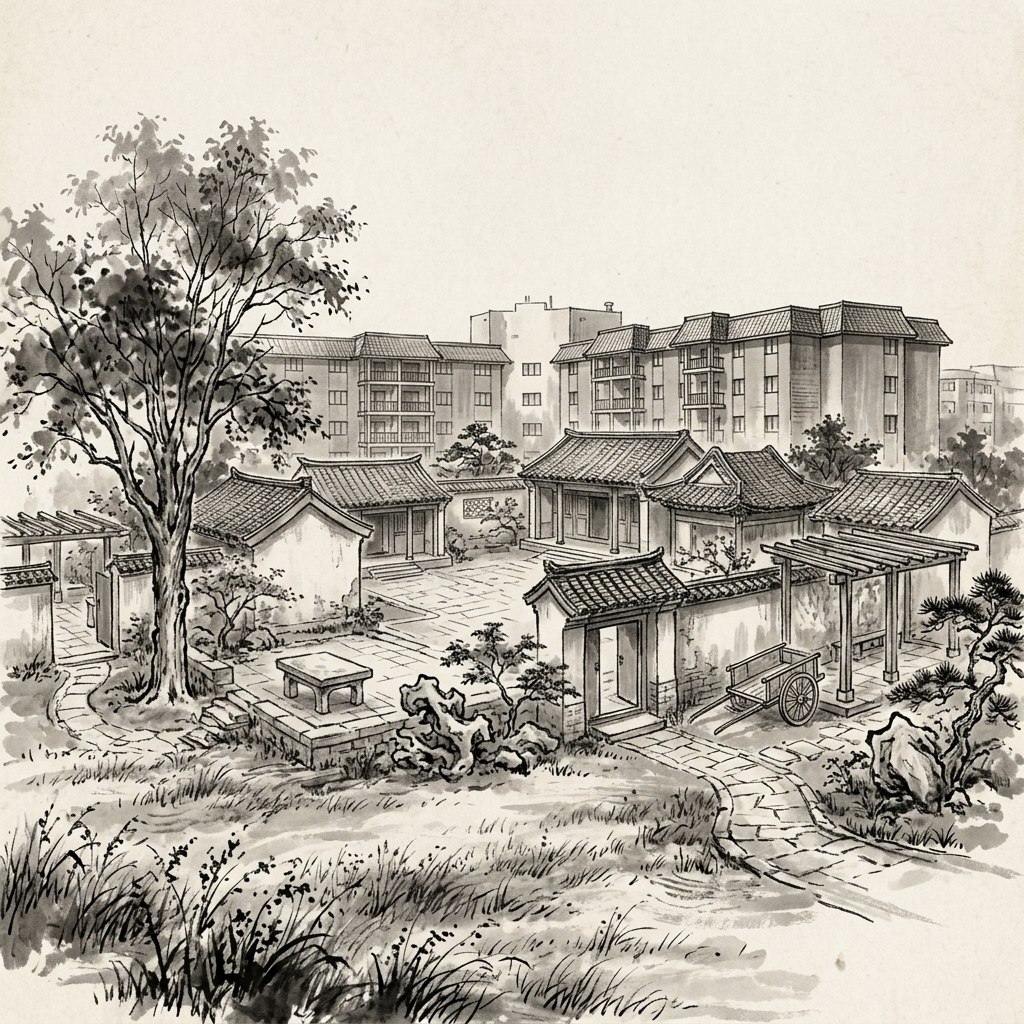
Camera orbit right. A traditional courtyard with stone bench, garden elements, and traditional buildings.
prompt source: report_details
The higher-scoring side has visible camera or scene motion. Both first frames passed geometric matching against the same input. This pair compares geometric_consistency only.
Model result videos will be available with the ModelScope release. / 模型推理视频将在 ModelScope 方案上线后提供。
Higher metric scoreScore 0.9848
Model result videos will be available with the ModelScope release. / 模型推理视频将在 ModelScope 方案上线后提供。
Lower metric scoreScore 0.1952
Input image
Input verified · same benchmark case · gap 0.8076
image_static_photorealistic_city_0047
Suite: image_staticMetric: geometric_consistencyScene: photorealistic / outdoor / city
Benchmark prompt target
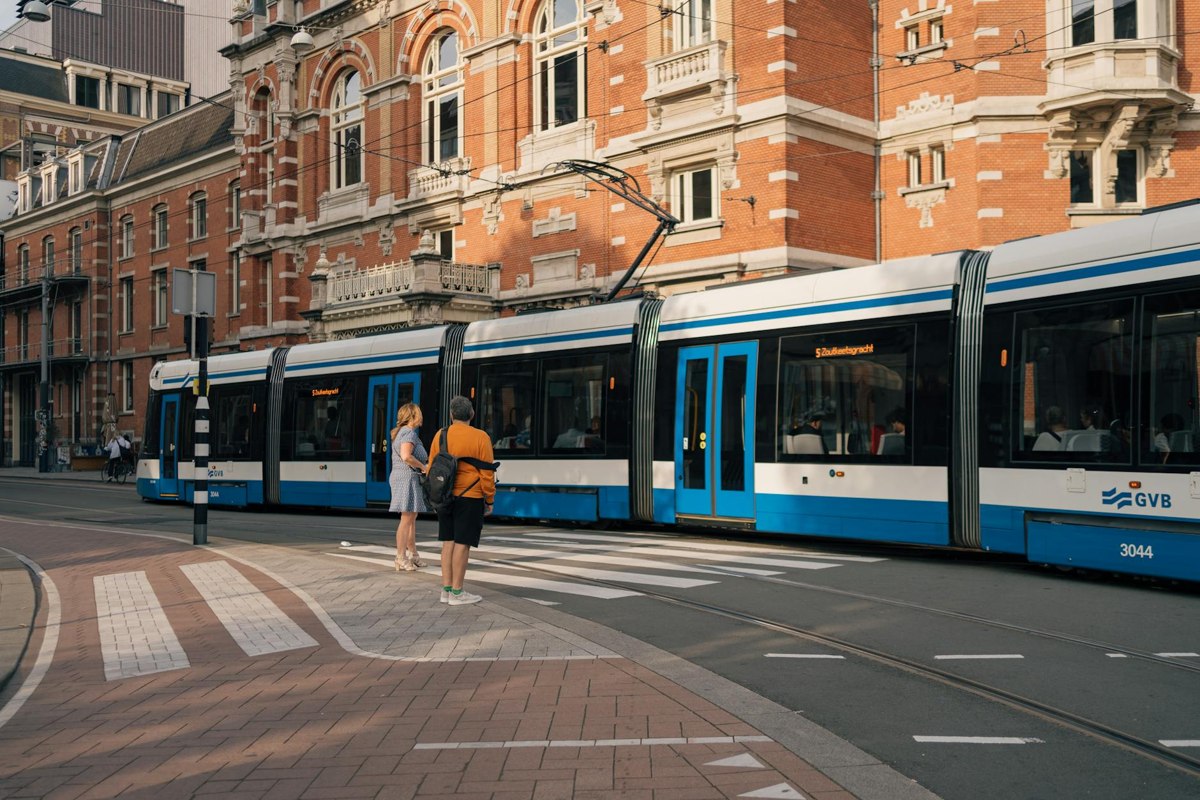
Camera orbit left. A city street with tram, bicycle, and historic building.
prompt source: report_details
The higher-scoring side has visible camera or scene motion. Both first frames passed geometric matching against the same input. This pair compares geometric_consistency only.
Model result videos will be available with the ModelScope release. / 模型推理视频将在 ModelScope 方案上线后提供。
Higher metric scoreScore 0.9894
Model result videos will be available with the ModelScope release. / 模型推理视频将在 ModelScope 方案上线后提供。
Lower metric scoreScore 0.1818
Input image
Input verified · same benchmark case · gap 0.3239
image_static_stylized_city_0123
Suite: image_staticMetric: photometric_consistencyScene: stylized / outdoor / city
Benchmark prompt target
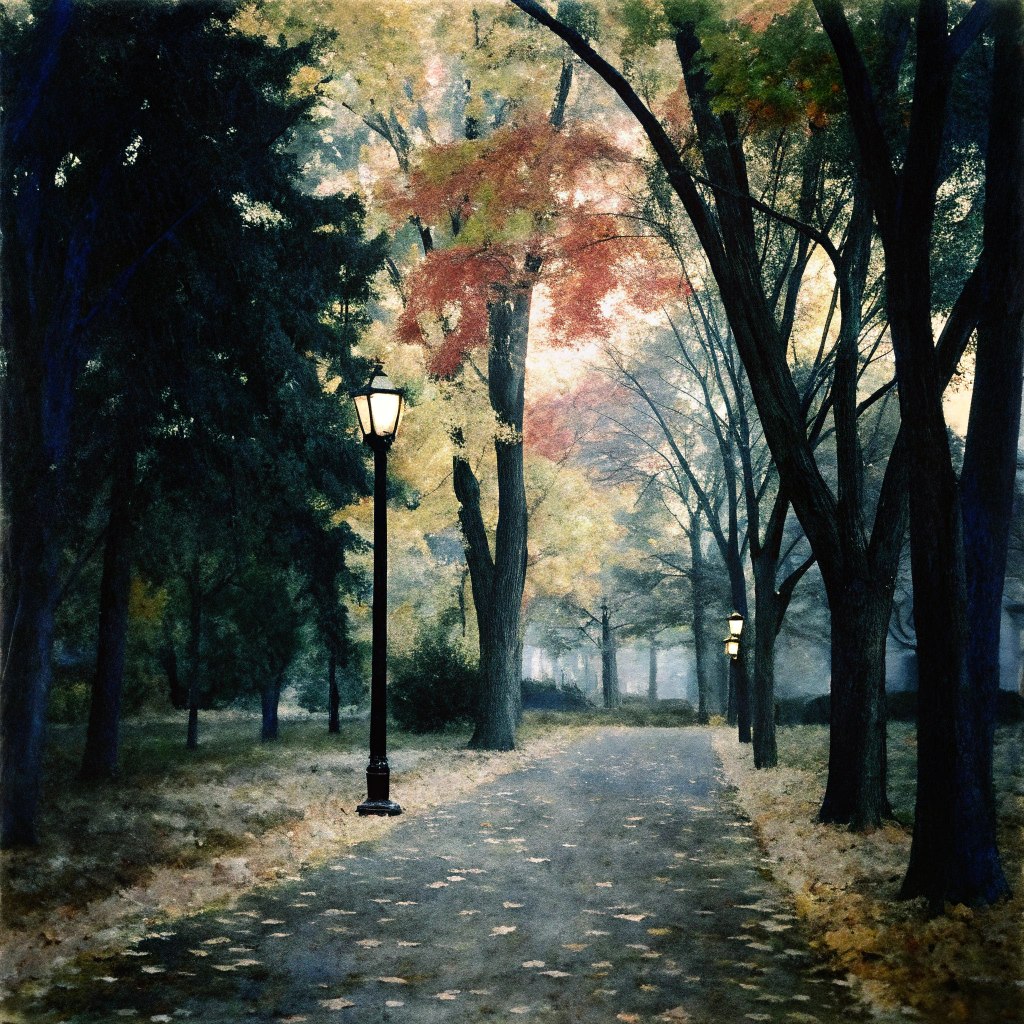
Camera pull out. A park path with benches, trees, and wider path. Camera move right. A city street with buildings, parked cars, and benches. Camera pan right. An urban square with fountain, people, and shops.
prompt source: report_details
The higher-scoring side has visible camera or scene motion. Both first frames passed geometric matching against the same input. This pair compares photometric_consistency only.
Model result videos will be available with the ModelScope release. / 模型推理视频将在 ModelScope 方案上线后提供。
Higher metric scoreScore 0.8311
Model result videos will be available with the ModelScope release. / 模型推理视频将在 ModelScope 方案上线后提供。
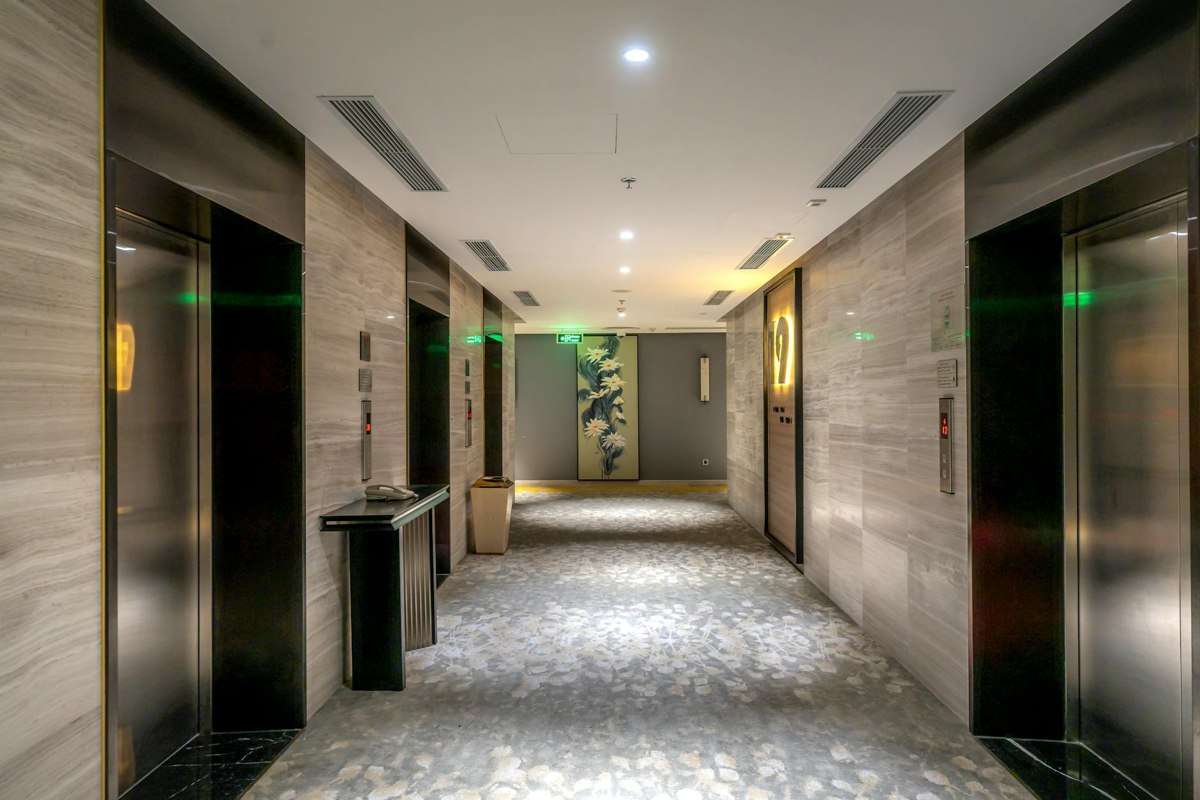
Camera pan right. A modern hotel corridor with elevator doors, emergency exit sign, and wall panels. Camera move right. A lobby area with reception desk, seating area, and decorative plants. Camera pull out. Entrance doors with revolving door and floor mat.
prompt source: report_details
The higher-scoring side has visible camera or scene motion. Both first frames passed geometric matching against the same input. This pair compares photometric_consistency only.
Model result videos will be available with the ModelScope release. / 模型推理视频将在 ModelScope 方案上线后提供。
Higher metric scoreScore 0.9052
Model result videos will be available with the ModelScope release. / 模型推理视频将在 ModelScope 方案上线后提供。
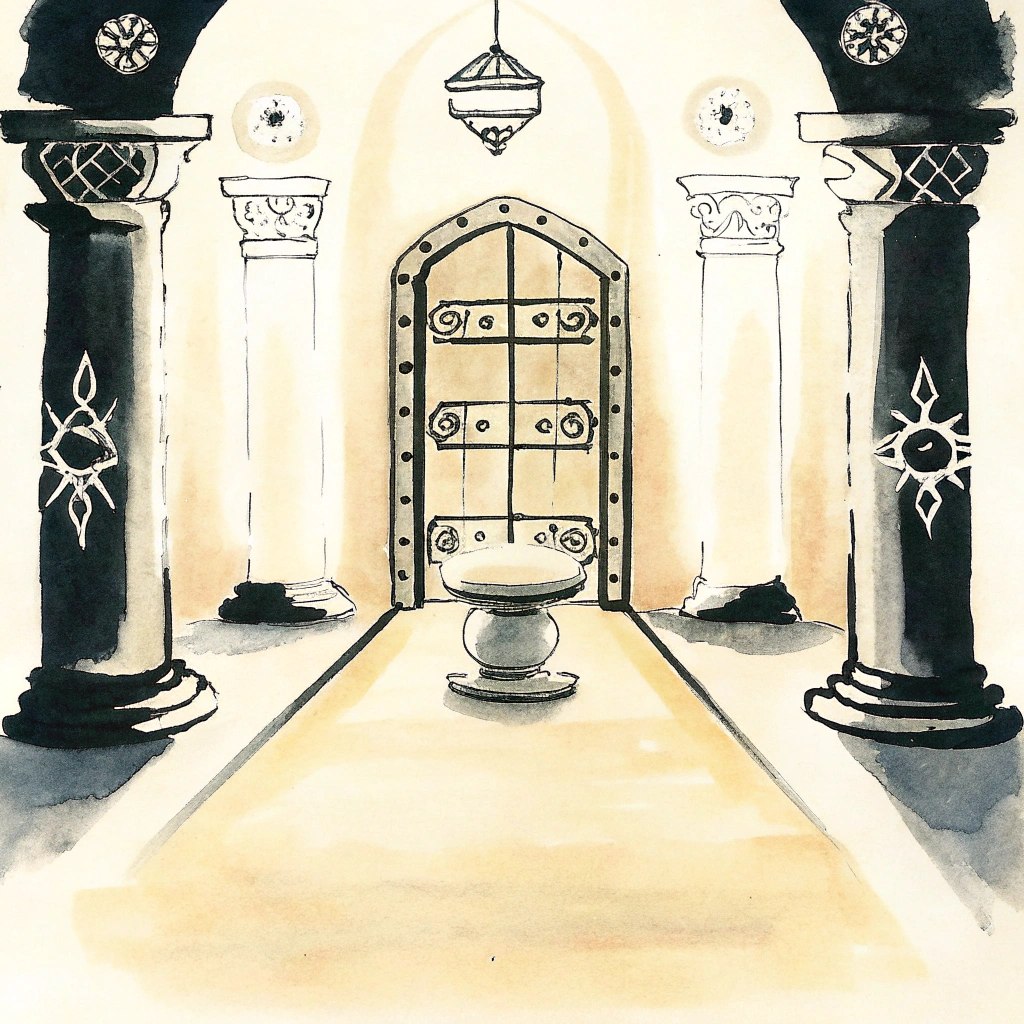
Camera pan right. A stylized passageway with columns, wall sconces, and corridor.
prompt source: report_details
The higher-scoring side has visible camera or scene motion. Both first frames passed geometric matching against the same input. This pair compares photometric_consistency only.
Model result videos will be available with the ModelScope release. / 模型推理视频将在 ModelScope 方案上线后提供。
Higher metric scoreScore 0.8870
Model result videos will be available with the ModelScope release. / 模型推理视频将在 ModelScope 方案上线后提供。