This page defines three official GVGC-style epipolar-geometry metrics [Li et al., 2024 ] that probe whether nearby generated frames admit a stable two-view epipolar explanation [Hartley and Zisserman, 2004 ]. They require only the prediction video—no camera-pose annotations and no reference video. The core question is whether local feature correspondences approximately satisfy the epipolar constraint, indicating that two frames can be explained as projections of the same scene under a pinhole camera model with rigid relative motion.
In classical multiple-view geometry, if two frames observe the same scene under rigid camera motion, a point x x x x ′ x' x ′ l ′ = F x l' = F x l ′ = F x F F F lightweight, interpretable two-view geometry signal; they check sparse-feature epipolar consistency only and do not replace global 3D self-consistency metrics such as MEt3R, reprojection error, or reconstruction-based scores.
In WorldAtlas, the backend builds adjacent (or strided) frame pairs from sampled prediction frames, matches SIFT features with Lowe’s ratio test by default, and estimates F F F
Metric Raw statistic Direction epipolar_errormedian inlier Sampson error after fundamental-matrix RANSAC lower is better epipolar_inlier_rateRANSAC inliers / Lowe-ratio feature matches higher is better feature_match_coverageRANSAC inliers / min keypoint count higher is better
For matched homogeneous points x i , x i ′ x_i, x'_i x i , x i ′
d i = ∣ x i ′ T F x i ∣ ( F x i ) 1 2 + ( F x i ) 2 2 + ( F T x i ′ ) 1 2 + ( F T x i ′ ) 2 2 (1) d_i = \frac{|{x'_i}^{\mathsf T} F x_i|}{\sqrt{(Fx_i)_1^2 + (Fx_i)_2^2 + (F^{\mathsf T}x'_i)_1^2 + (F^{\mathsf T}x'_i)_2^2}}
\tag{1} d i = ( F x i ) 1 2 + ( F x i ) 2 2 + ( F T x i ′ ) 1 2 + ( F T x i ′ ) 2 2 ∣ x i ′ T F x i ∣ ( 1 ) Per valid pair, epipolar_error uses the median d i d_i d i [ 0 , 5 ] [0, 5] [ 0 , 5 ]
Per valid pair, inlier rate and coverage are
r = # i n l i e r s # g o o d m a t c h e s , c = min ( # i n l i e r s min ( # k p l e f t , # k p r i g h t ) , 1 ) (2) r = \frac{\#\mathrm{inliers}}{\#\mathrm{good\ matches}},
\qquad
c = \min\!\left(\frac{\#\mathrm{inliers}}{\min(\#\mathrm{kp}_\mathrm{left}, \#\mathrm{kp}_\mathrm{right})},\, 1\right)
\tag{2} r = # good matches # inliers , c = min ( min ( # kp left , # kp right ) # inliers , 1 ) ( 2 ) Video-level epipolar_inlier_rate and feature_match_coverage average r r r c c c [ 0 , 1 ] [0,1] [ 0 , 1 ] epipolar_error takes the median of per-pair medians and is reverse-normalized from [ 0 , 5 ] [0, 5] [ 0 , 5 ] [ 0 , 1 ] [0, 1] [ 0 , 1 ] not_applicable. All three are official leaderboard metrics , subject to complete coverage and valid measurement checks. They may fail often in weak-texture, strongly non-rigid, or dynamic-prompt regimes and should be read alongside MEt3R and reprojection error.
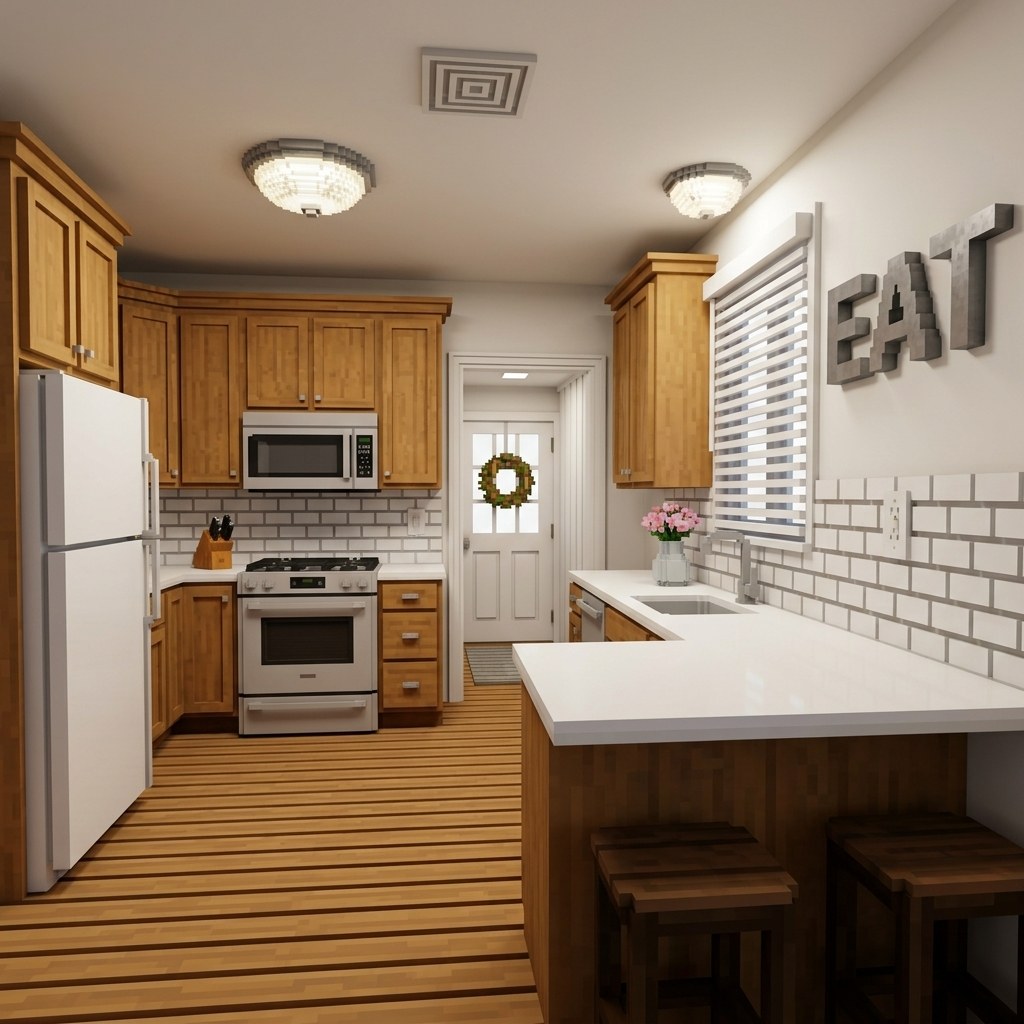
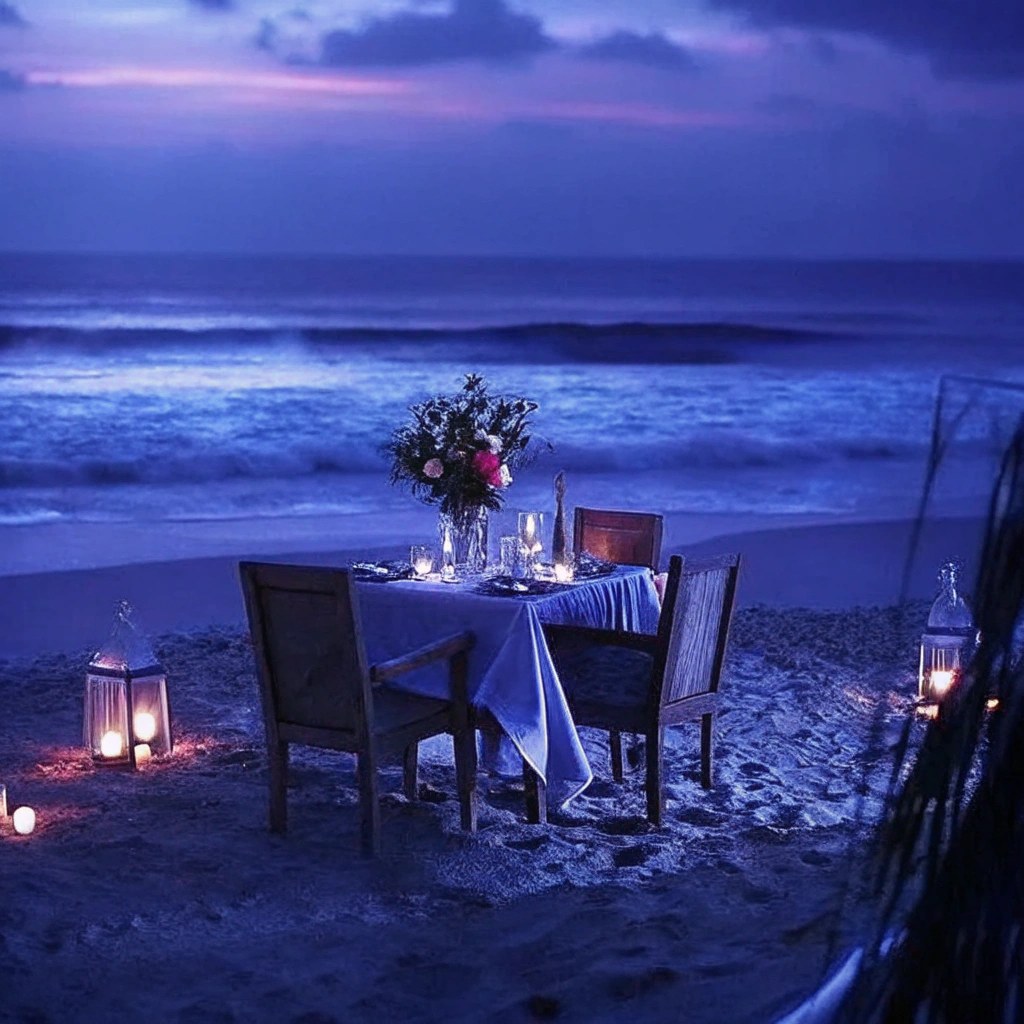
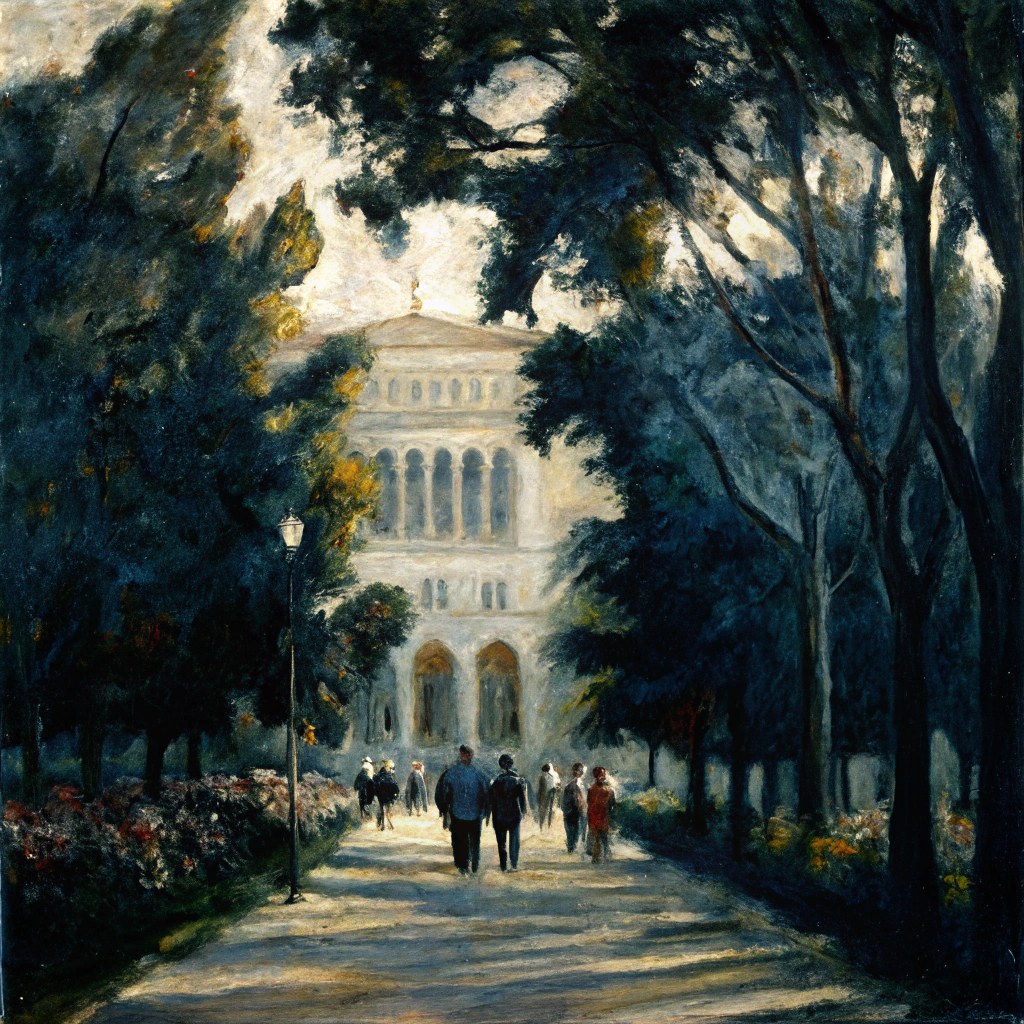
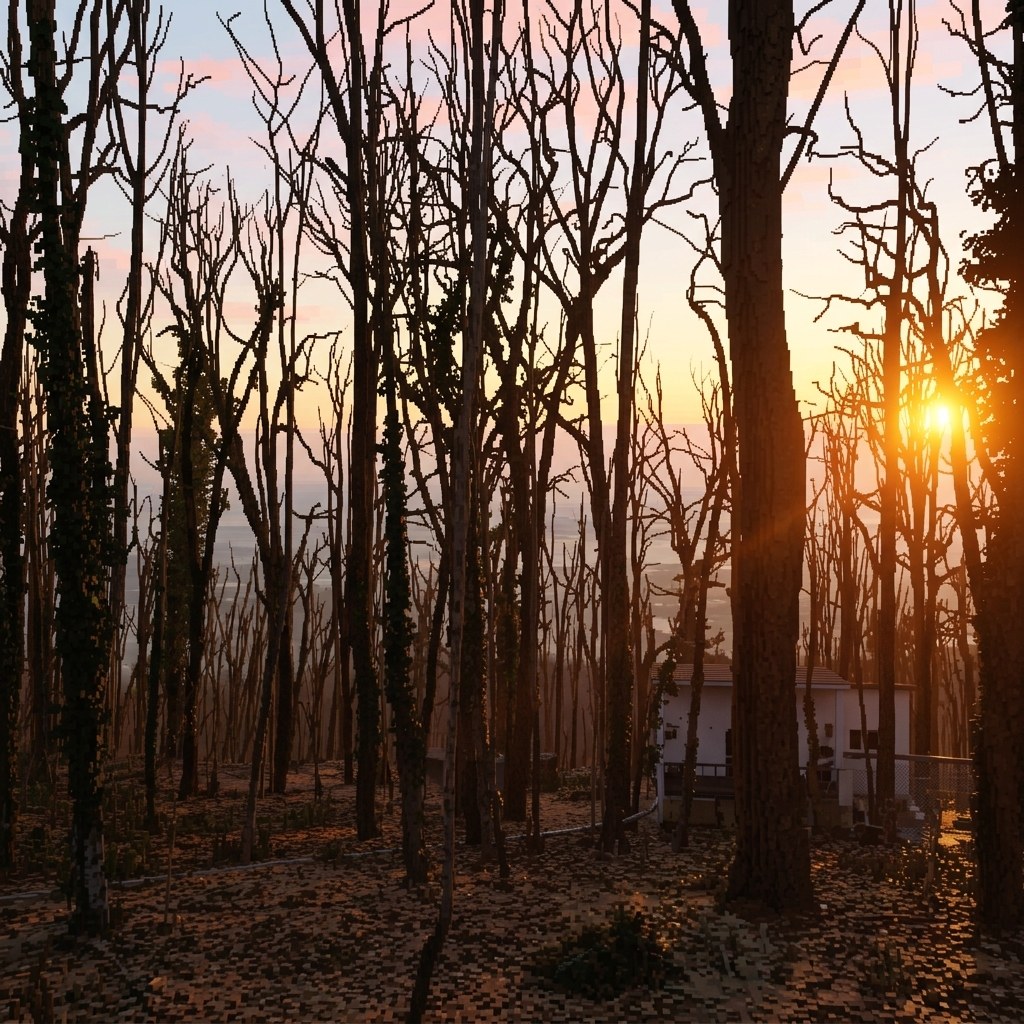
19 image_static pairs are shown below. They are the site-selected same-input comparisons in docs/assets/metric_examples/paired_manifest.json (paired_same_input_prompt, verified_exact) whose example videos were both exported. Order alternates epipolar_error, epipolar_inlier_rate, and feature_match_coverage by each sub-metric’s site case rank. Scores are the normalized scores for the named sub-metric.
Audit manifest: docs/assets/metric_examples/paired_manifest.json.
Input image
Same input and prompt · image_static · gap 0.0593
image_static_photorealistic_workspaces_0016Suite: image_static Metric: epipolar_error Scene: photorealistic / workspaces
Benchmark prompt
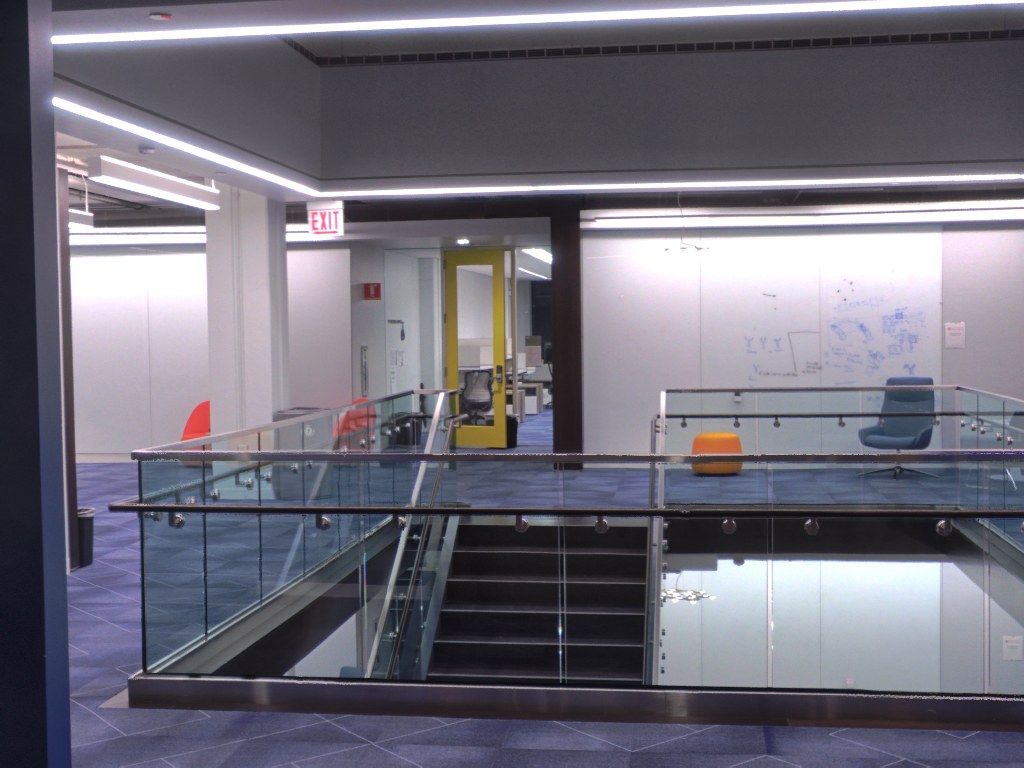
Camera pan right. A modern office with desks, computers, and office chairs. Everything in the scene remains completely motionless.
source: generation_records
Higher: lingbot_world_image_static. Lower: matrix_game2_5s_image_static. Labels compare epipolar_error only.
Higher metric score Score 0.9814 lingbot_world_image_static Median inlier Sampson error 0.0932
Lower metric score Score 0.9221 matrix_game2_5s_image_static Median inlier Sampson error 0.3897
Input image
Same input and prompt · image_static · gap 0.5595
image_static_photorealistic_passageways_0079Suite: image_static Metric: epipolar_inlier_rate Scene: photorealistic / passageways
Benchmark prompt
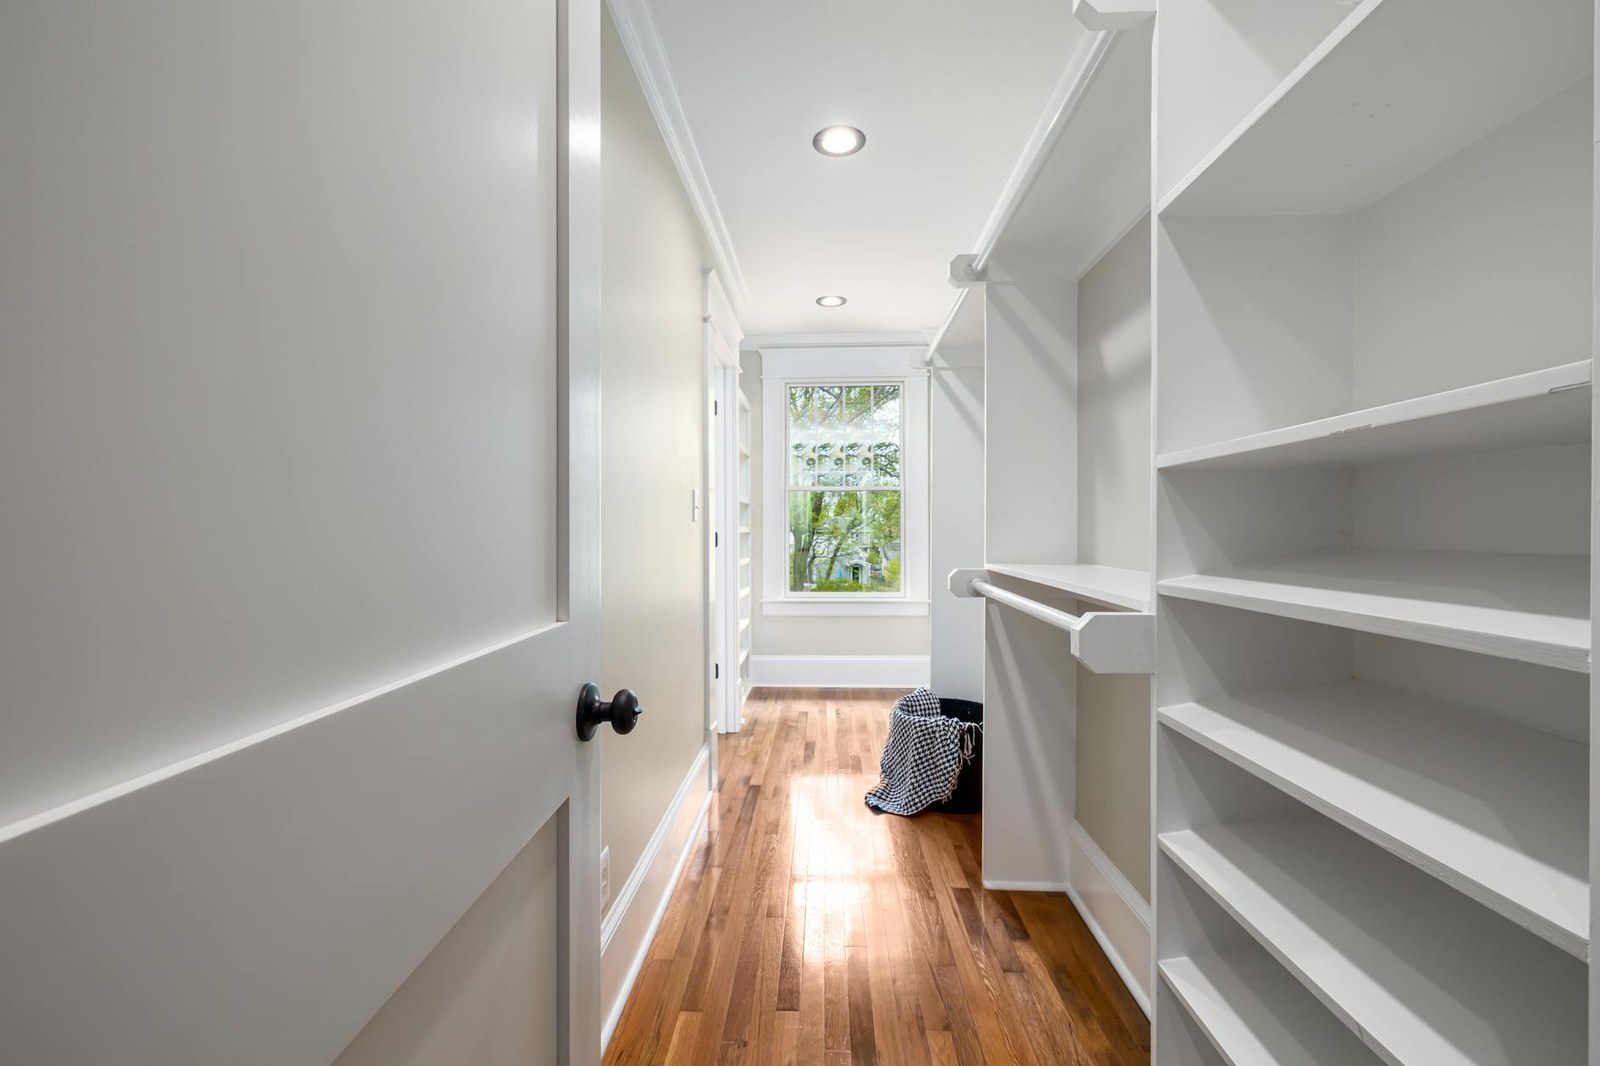
Camera move right. A bright hallway with wooden floor, armchair, and small table. Everything in the scene remains completely motionless.
source: generation_records
Higher: astronex_world_image_static. Lower: matrix_game2_5s_image_static. Labels compare epipolar_inlier_rate only.
Higher metric score Score 0.9745 astronex_world_image_static Inlier rate 97.5%
Lower metric score Score 0.4150 matrix_game2_5s_image_static Inlier rate 41.5%
Input image
Same input and prompt · image_static · gap 0.4021
image_static_photorealistic_workspaces_0074Suite: image_static Metric: feature_match_coverage Scene: photorealistic / workspaces
Benchmark prompt
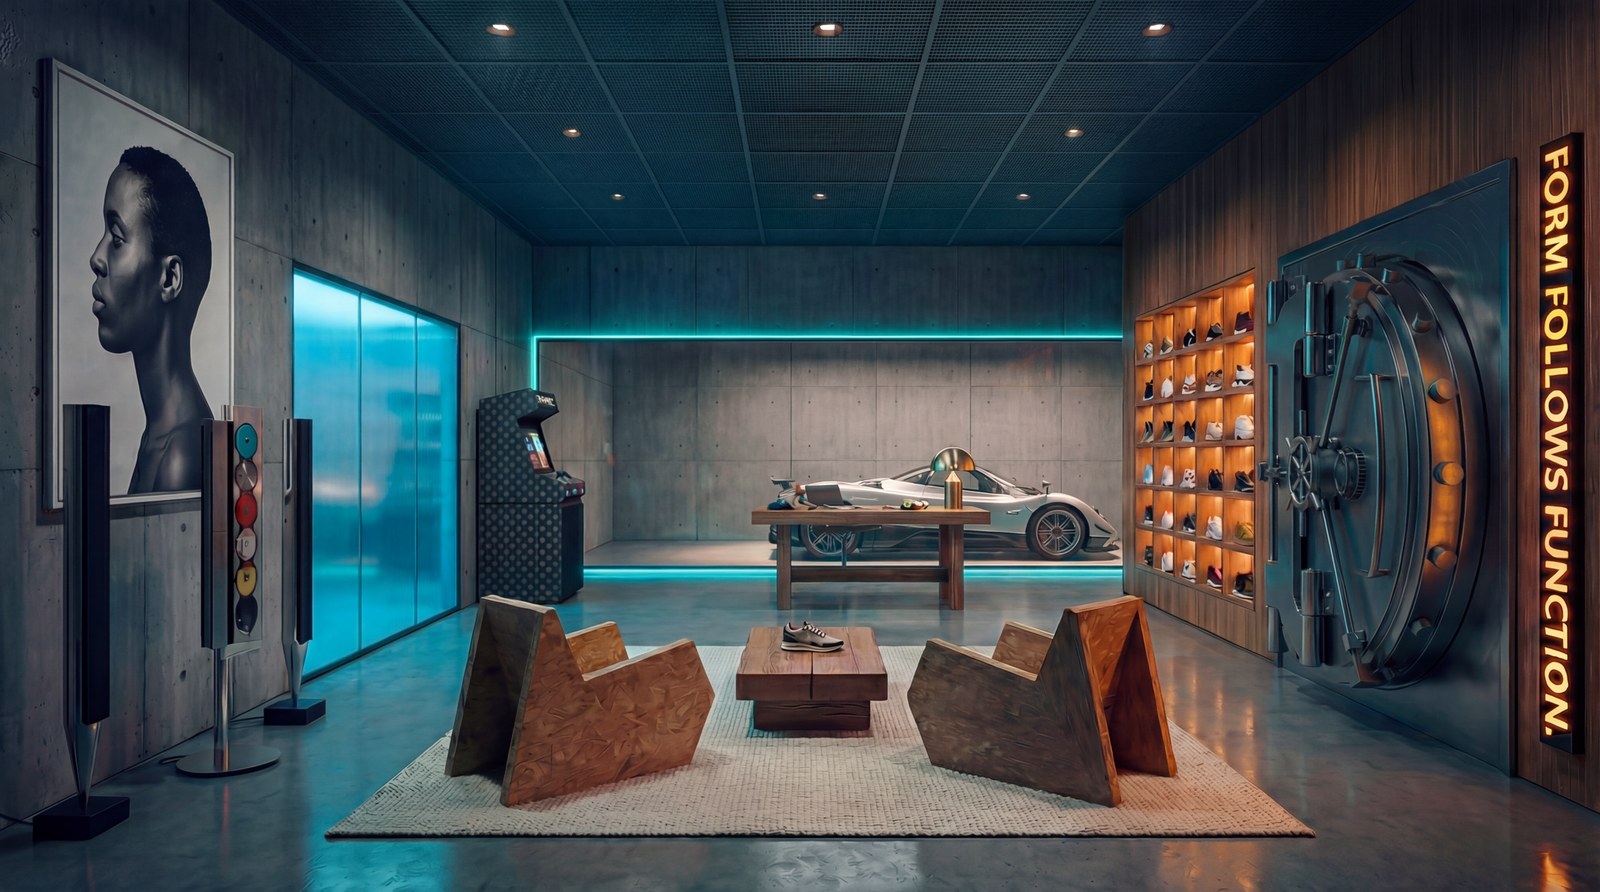
Camera orbit left. A modern workspace with sneaker wall, vault door, and futuristic car. Everything in the scene remains completely motionless.
source: generation_records
Higher: hy_worldplay_ar_distilled_image_test_balanced_5000_5s. Lower: hy_worldplay_ar_rl_image_test_balanced_5000_5s. Labels compare feature_match_coverage only.
Higher metric score Score 0.5724 hy_worldplay_ar_distilled_image_test_balanced_5000_5s Feature-match coverage 57.2%
Lower metric score Score 0.1703 hy_worldplay_ar_rl_image_test_balanced_5000_5s Feature-match coverage 17.0%
Input image
Same input and prompt · image_static · gap 0.0396
image_static_photorealistic_public_spaces_0014Suite: image_static Metric: epipolar_error Scene: photorealistic / public_spaces
Benchmark prompt
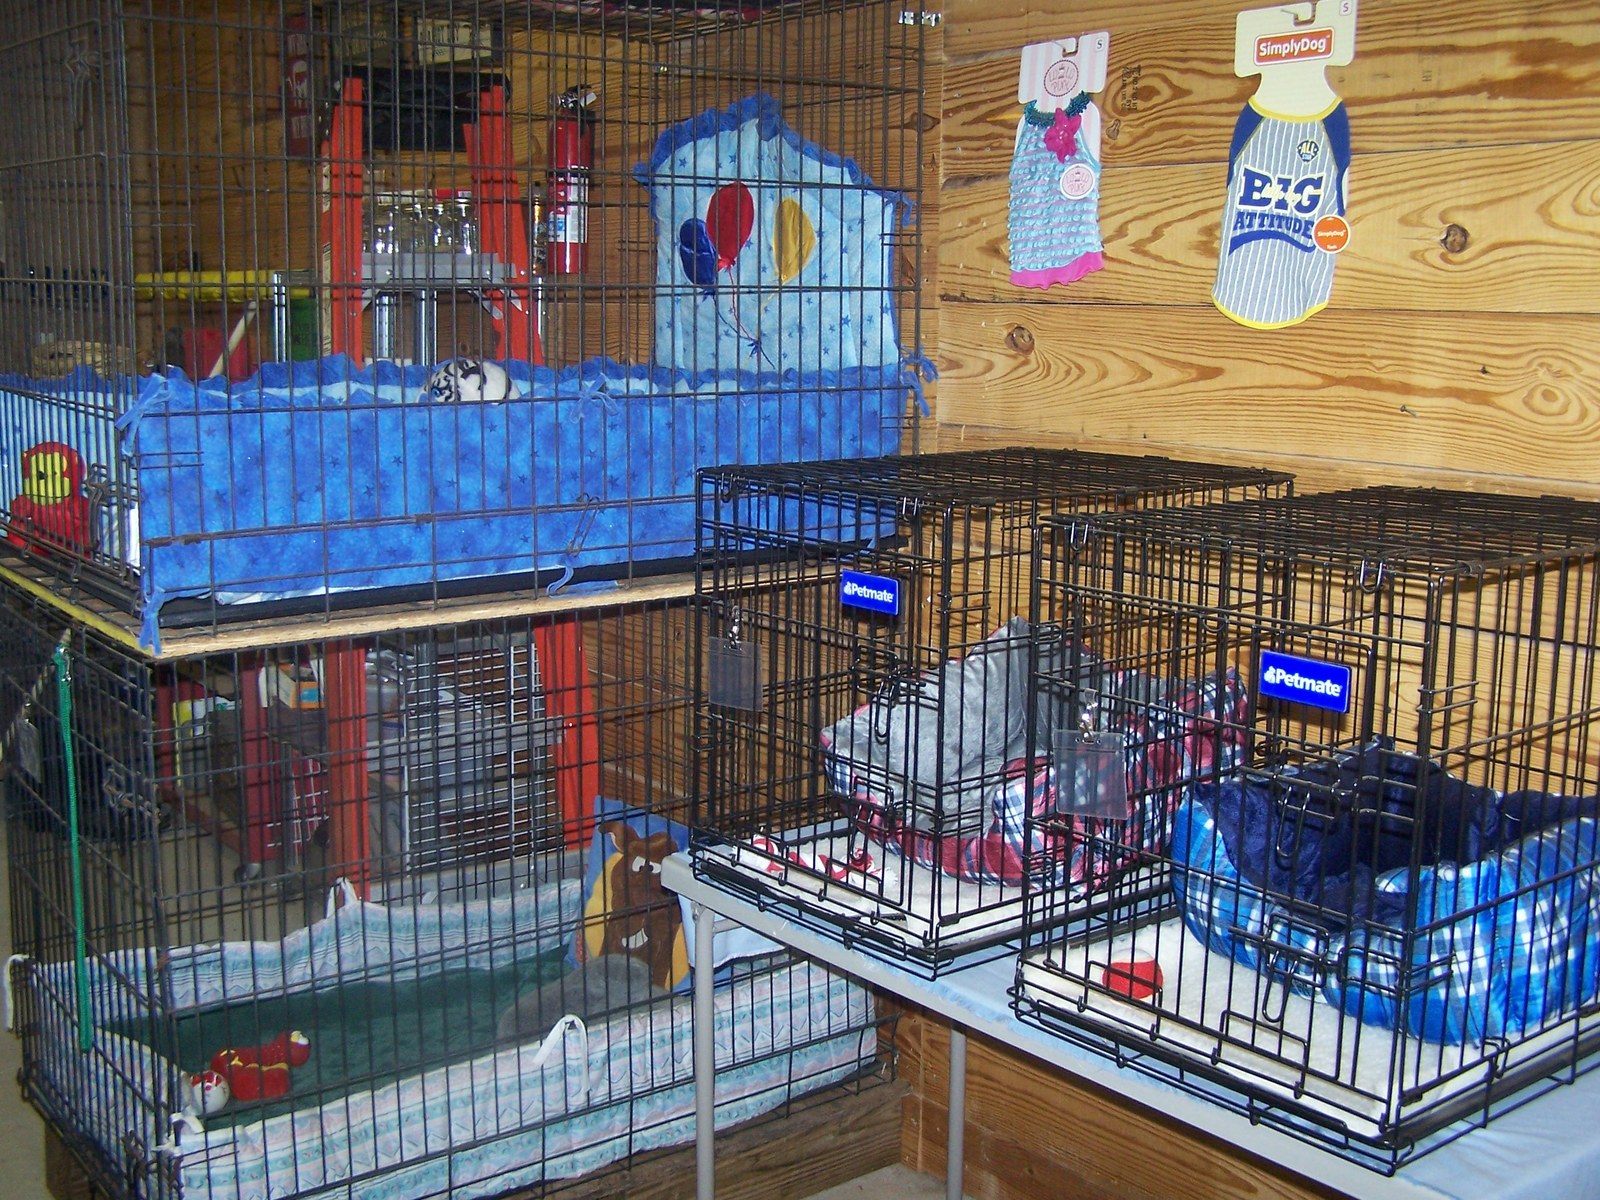
Camera pan right. A pet care room with pet cages, feeding station, and water bowls.
source: generation_records
Higher: hy_worldplay_ar_image_static. Lower: ac3d-image-static. Labels compare epipolar_error only.
Higher metric score Score 0.9725 hy_worldplay_ar_image_static Median inlier Sampson error 0.1375
Lower metric score Score 0.9329 ac3d-image-static Median inlier Sampson error 0.3357
Input image
Same input and prompt · image_static · gap 0.2254
image_static_photorealistic_public_spaces_0150Suite: image_static Metric: epipolar_inlier_rate Scene: photorealistic / public_spaces
Benchmark prompt
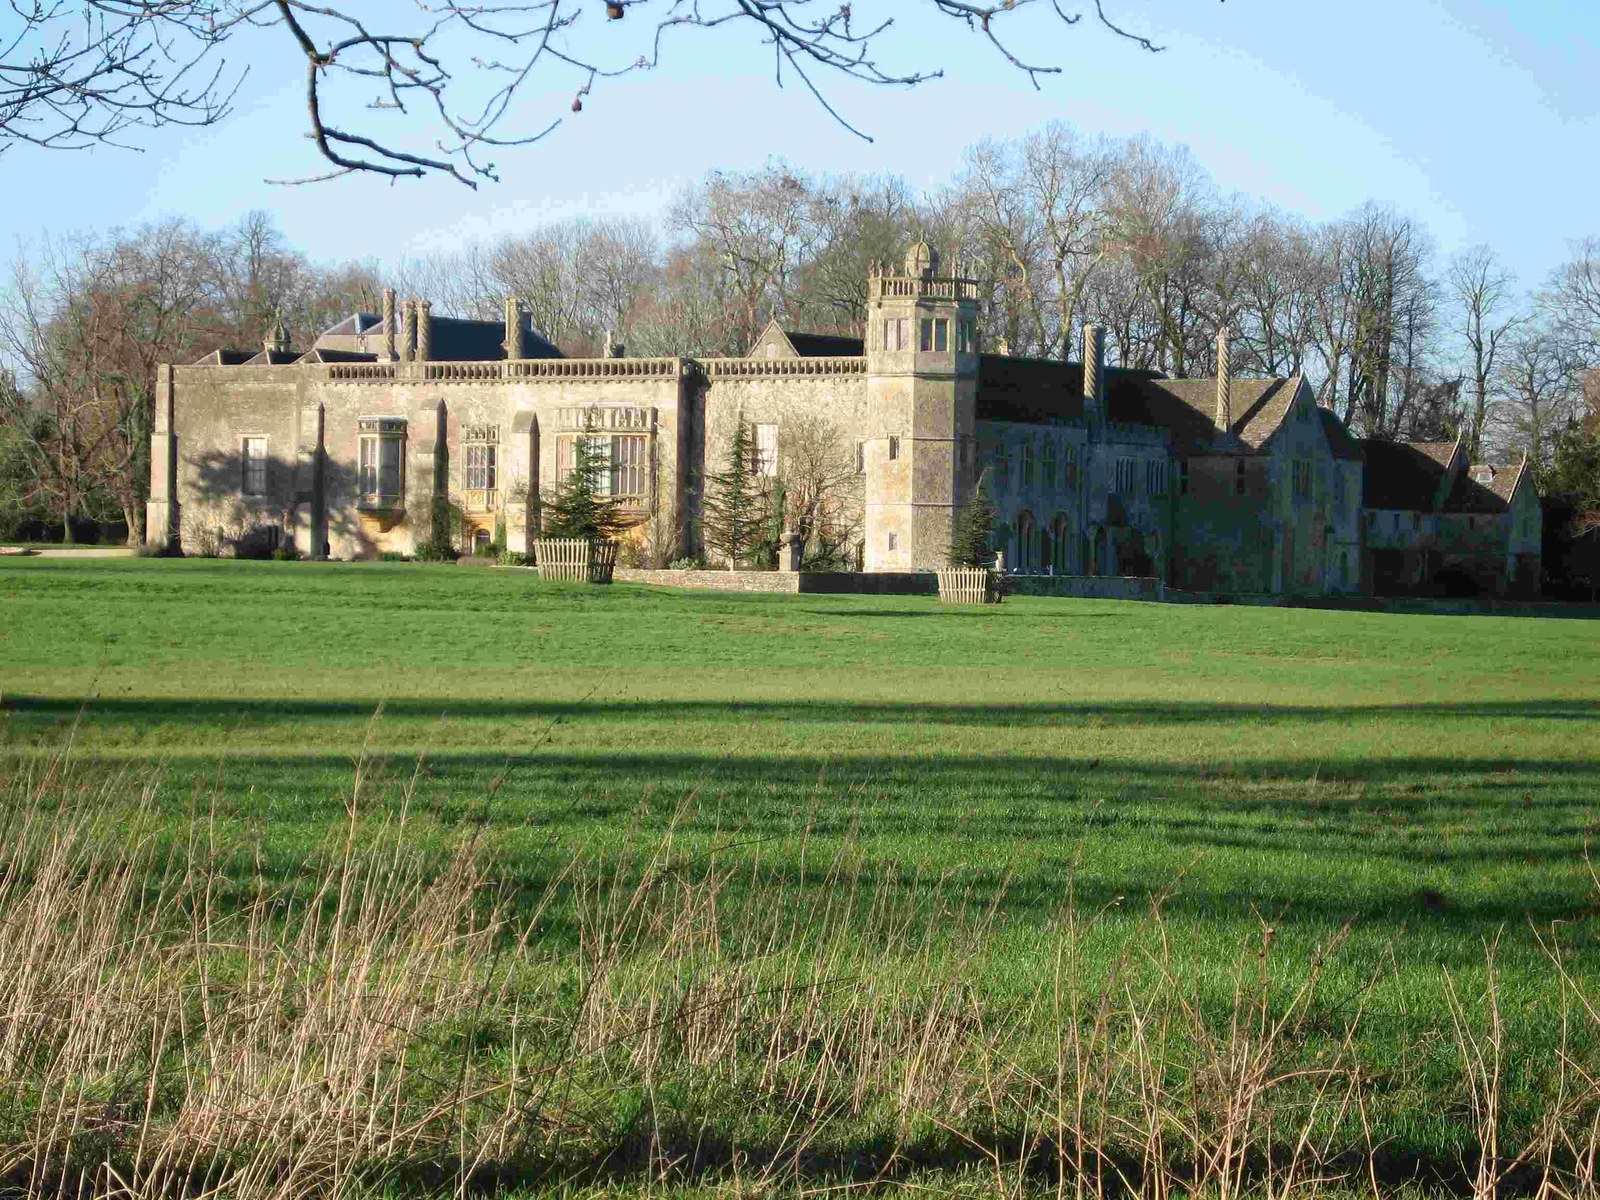
Camera pan left. A historic building with flower beds, stone path, and hedges. Everything in the scene remains completely motionless.
source: generation_records
Higher: dreamx_world_image_static. Lower: matrix_game2_5s_image_static. Labels compare epipolar_inlier_rate only.
Higher metric score Score 0.9759 dreamx_world_image_static Inlier rate 97.6%
Lower metric score Score 0.7505 matrix_game2_5s_image_static Inlier rate 75.0%
Input image
Same input and prompt · image_static · gap 0.3860
image_static_photorealistic_terrestrial_landscape_0067Suite: image_static Metric: feature_match_coverage Scene: photorealistic / terrestrial_landscape
Benchmark prompt
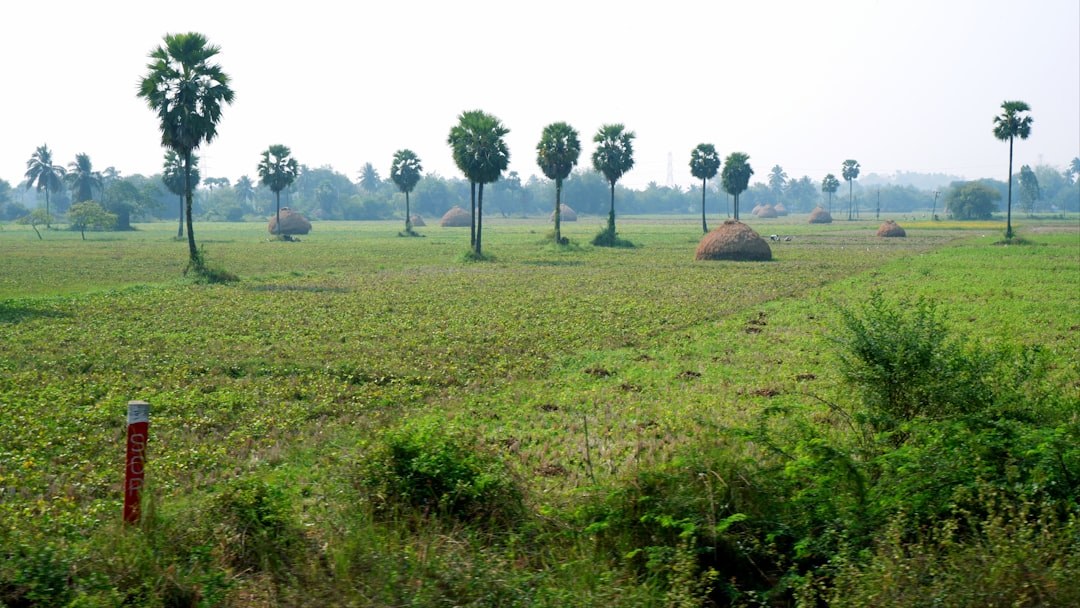
Camera pan left. A rural field with palm trees, haystacks, and green field. Everything in the scene remains completely motionless.
source: generation_records
Higher: lyra-2-image-static-openenvision. Lower: matrix_game3_5s_image_static_dynamic. Labels compare feature_match_coverage only.
Higher metric score Score 0.4469 lyra-2-image-static-openenvision Feature-match coverage 44.7%
Lower metric score Score 0.0609 matrix_game3_5s_image_static_dynamic Feature-match coverage 6.1%
Input image
Same input and prompt · image_static · gap 0.0704
image_static_stylized_living_spaces_0037Suite: image_static Metric: epipolar_error Scene: stylized / living_spaces
Benchmark prompt
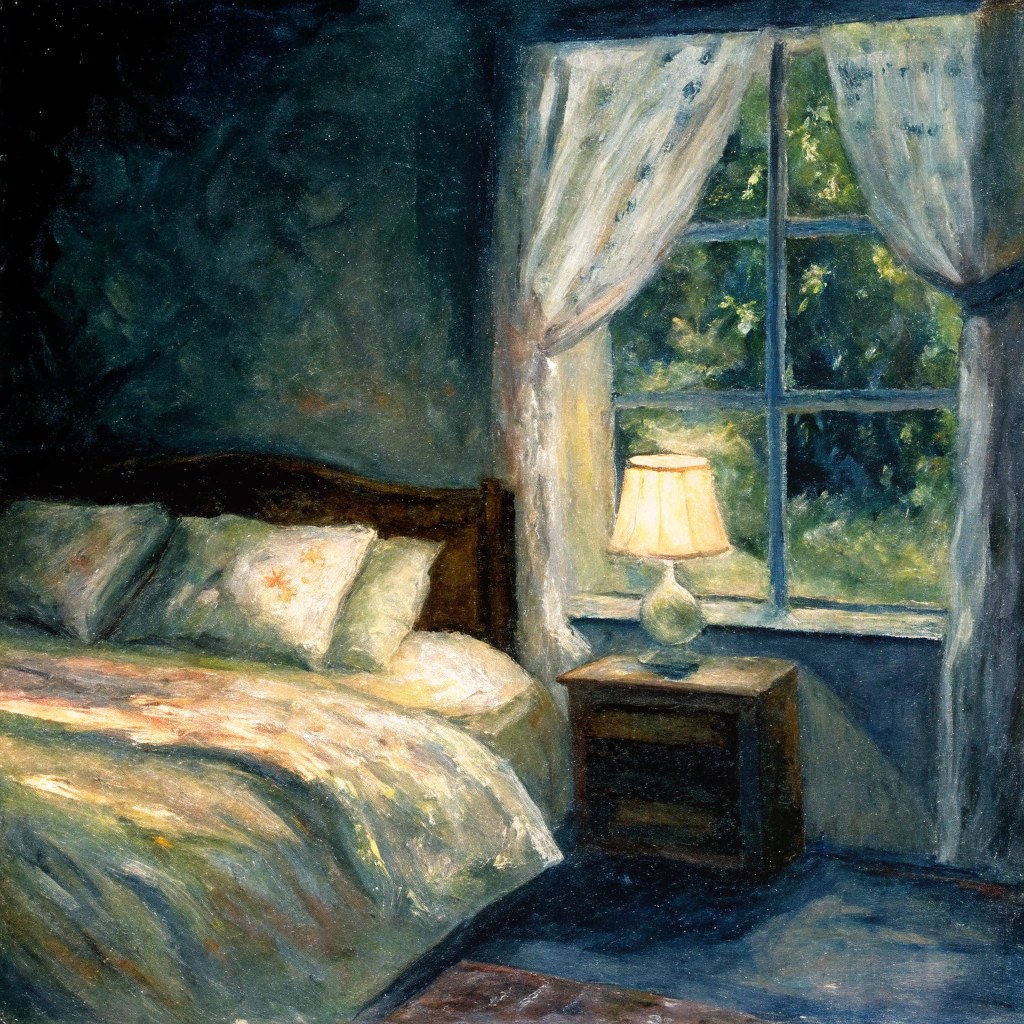
Camera pan right. A bedroom corner with wardrobe, chair, and rug. Everything in the scene remains completely motionless.
source: generation_records
Higher: dreamx_world_image_static. Lower: matrix_game2_5s_image_static. Labels compare epipolar_error only.
Higher metric score Score 0.9715 dreamx_world_image_static Median inlier Sampson error 0.1424
Lower metric score Score 0.9011 matrix_game2_5s_image_static Median inlier Sampson error 0.4946
Input image
Same input and prompt · image_static · gap 0.1651
image_static_photorealistic_terrestrial_landscape_0006Suite: image_static Metric: epipolar_inlier_rate Scene: photorealistic / terrestrial_landscape
Benchmark prompt
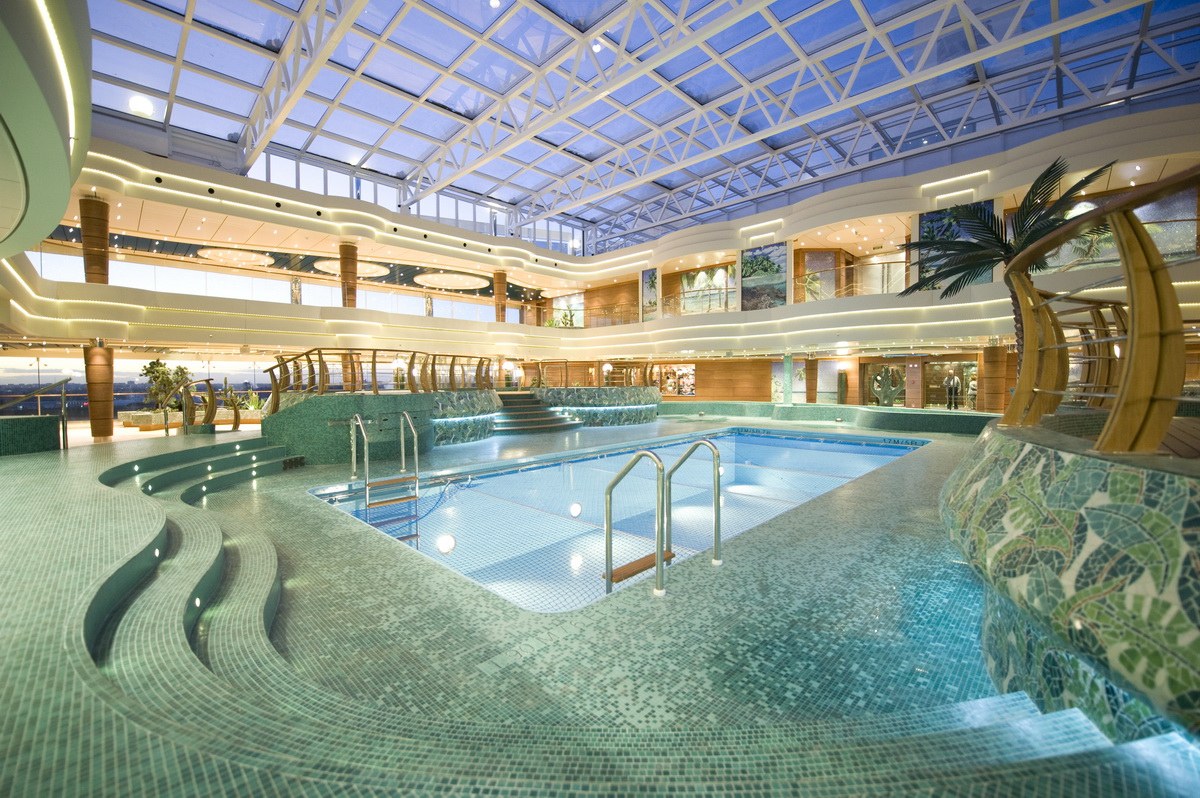
Camera orbit left. An indoor pool with wooden railings, decorative plants, and upper level. Everything in the scene remains completely motionless.
source: generation_records
Higher: hy_worldplay_ar_distilled_image_test_balanced_5000_5s. Lower: matrix_game3_image_static. Labels compare epipolar_inlier_rate only.
Higher metric score Score 0.9675 hy_worldplay_ar_distilled_image_test_balanced_5000_5s Inlier rate 96.7%
Lower metric score Score 0.8024 matrix_game3_image_static Inlier rate 80.2%
Input image
Same input and prompt · image_static · gap 0.8906
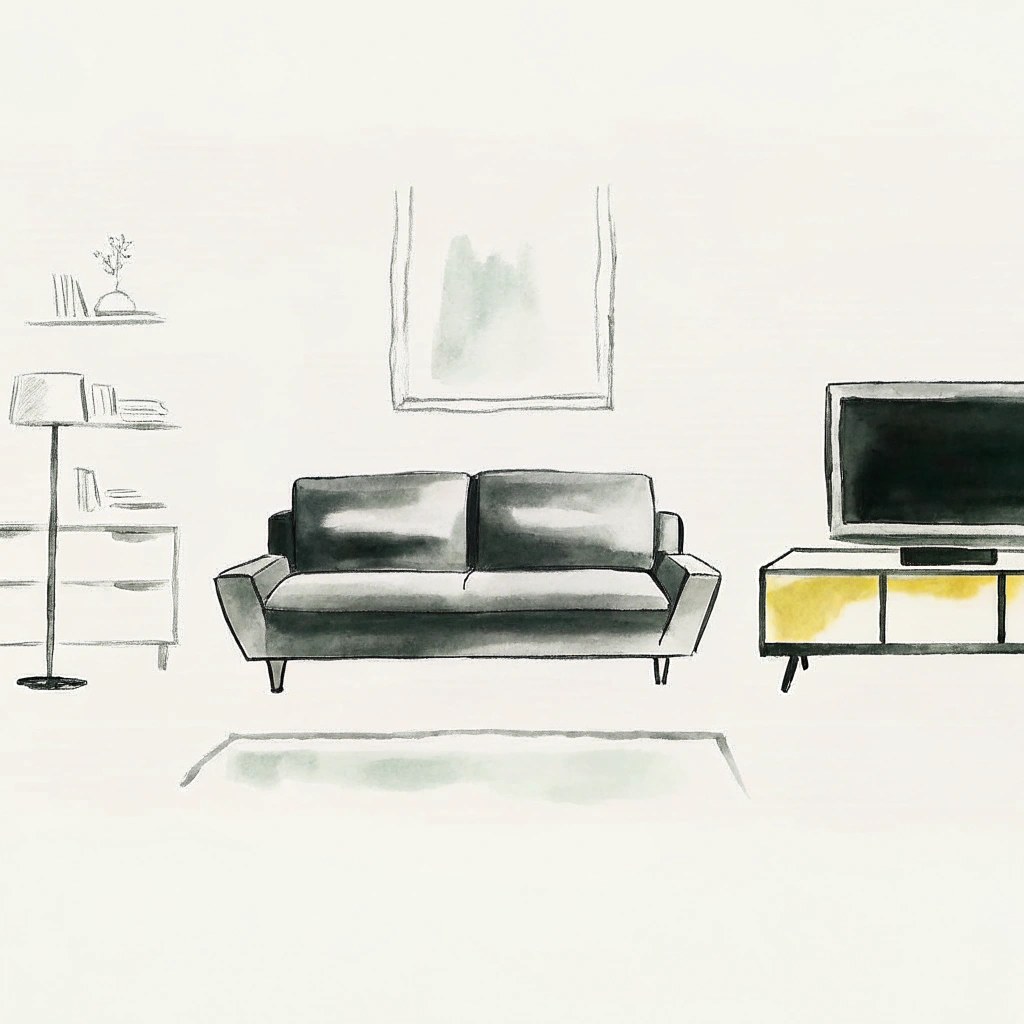
image_static_stylized_living_spaces_0034Suite: image_static Metric: feature_match_coverage Scene: stylized / living_spaces
Benchmark prompt
Camera move left. A minimalist living room with bookshelf, window, and armchair. Everything in the scene remains completely motionless.
source: generation_records
Higher: cameractrl_image_static. Lower: astra_image_static. Labels compare feature_match_coverage only.
Higher metric score Score 1.0000 cameractrl_image_static Feature-match coverage 100.0%
Lower metric score Score 0.1094 astra_image_static Feature-match coverage 10.9%
Input image
Same input and prompt · image_static · gap 0.0545
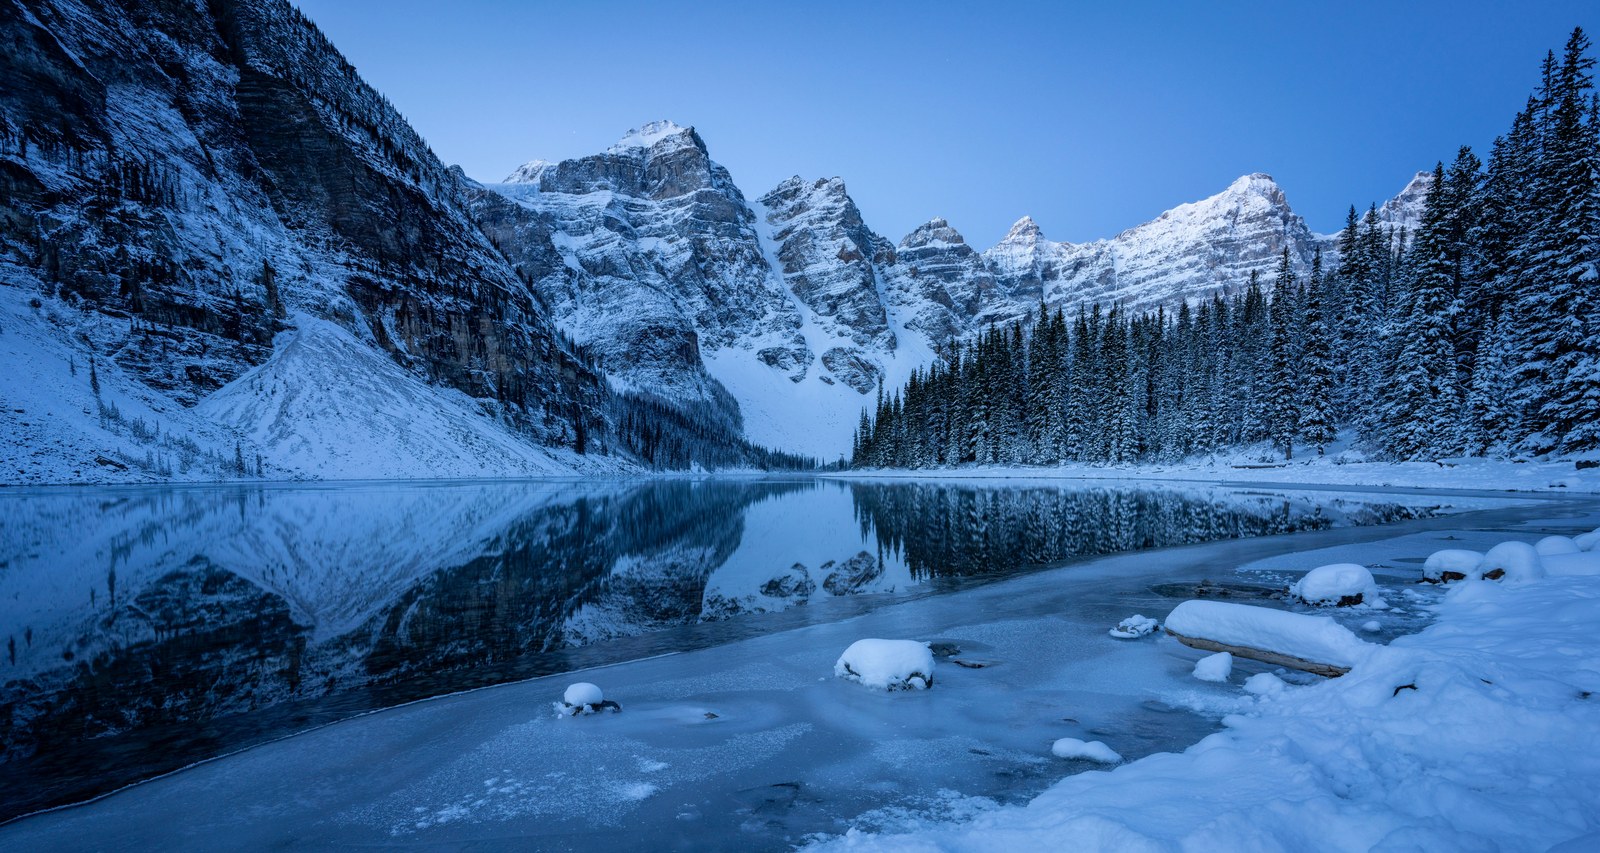
image_static_photorealistic_aquatic_landscape_0070Suite: image_static Metric: epipolar_error Scene: photorealistic / aquatic_landscape
Benchmark prompt
Camera pan left. A frozen lake with snow-covered mountains, evergreen trees, and distant peak. Everything in the scene remains completely motionless.
source: generation_records
Higher: hy_worldplay_ar_image_test_balanced_5000_5s. Lower: motionctrl_image_static_official_default_tmp2. Labels compare epipolar_error only.
Higher metric score Score 0.9875 hy_worldplay_ar_image_test_balanced_5000_5s Median inlier Sampson error 0.0625
Lower metric score Score 0.9330 motionctrl_image_static_official_default_tmp2 Median inlier Sampson error 0.3351
Input image
Same input and prompt · image_static · gap 0.5392
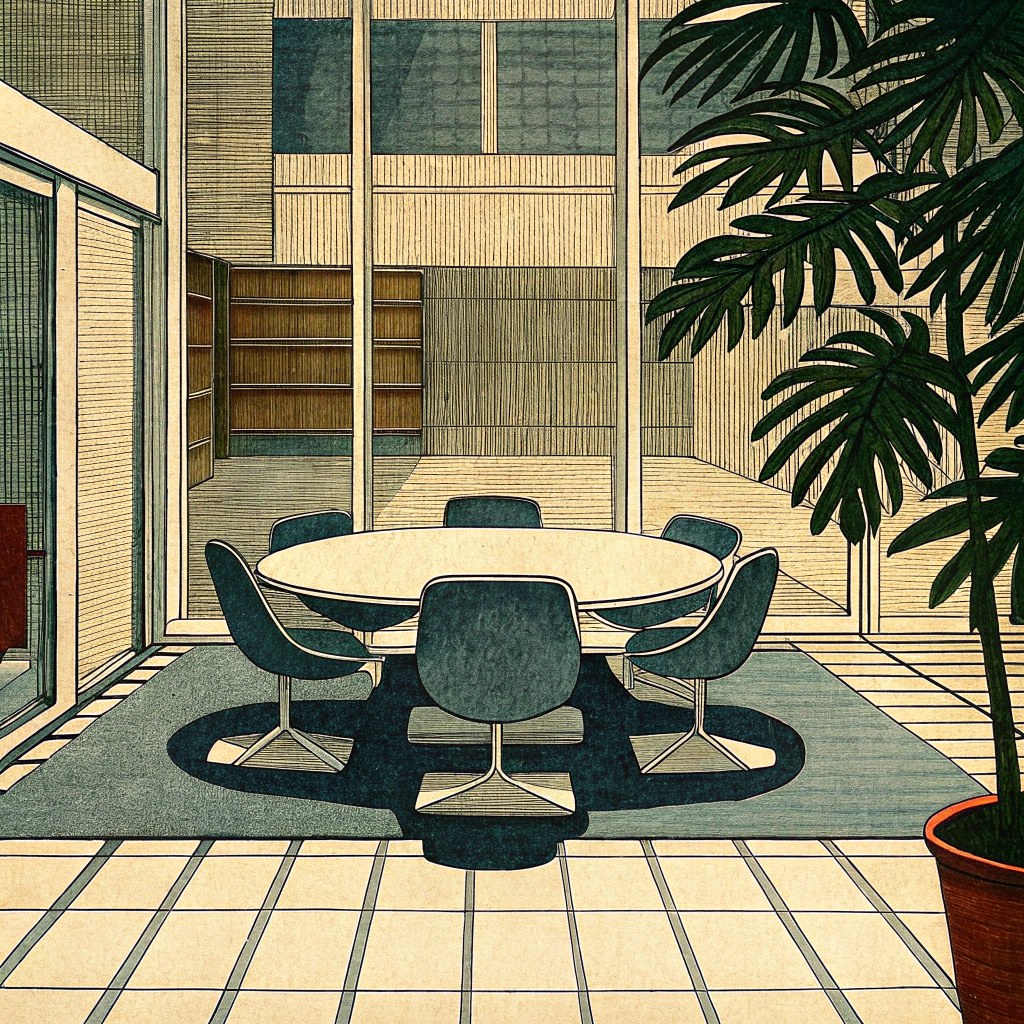
image_static_stylized_workspaces_0008Suite: image_static Metric: epipolar_inlier_rate Scene: stylized / workspaces
Benchmark prompt
Camera orbit left. A modern conference room with bookshelves, glass walls, and modern chairs. Everything in the scene remains completely motionless.
source: generation_records
Higher: hy_worldplay_ar_distilled_image_test_balanced_5000_5s. Lower: matrix_game3_5s_image_static_dynamic. Labels compare epipolar_inlier_rate only.
Higher metric score Score 0.9507 hy_worldplay_ar_distilled_image_test_balanced_5000_5s Inlier rate 95.1%
Lower metric score Score 0.4115 matrix_game3_5s_image_static_dynamic Inlier rate 41.1%
Input image
Same input and prompt · image_static · gap 0.3882
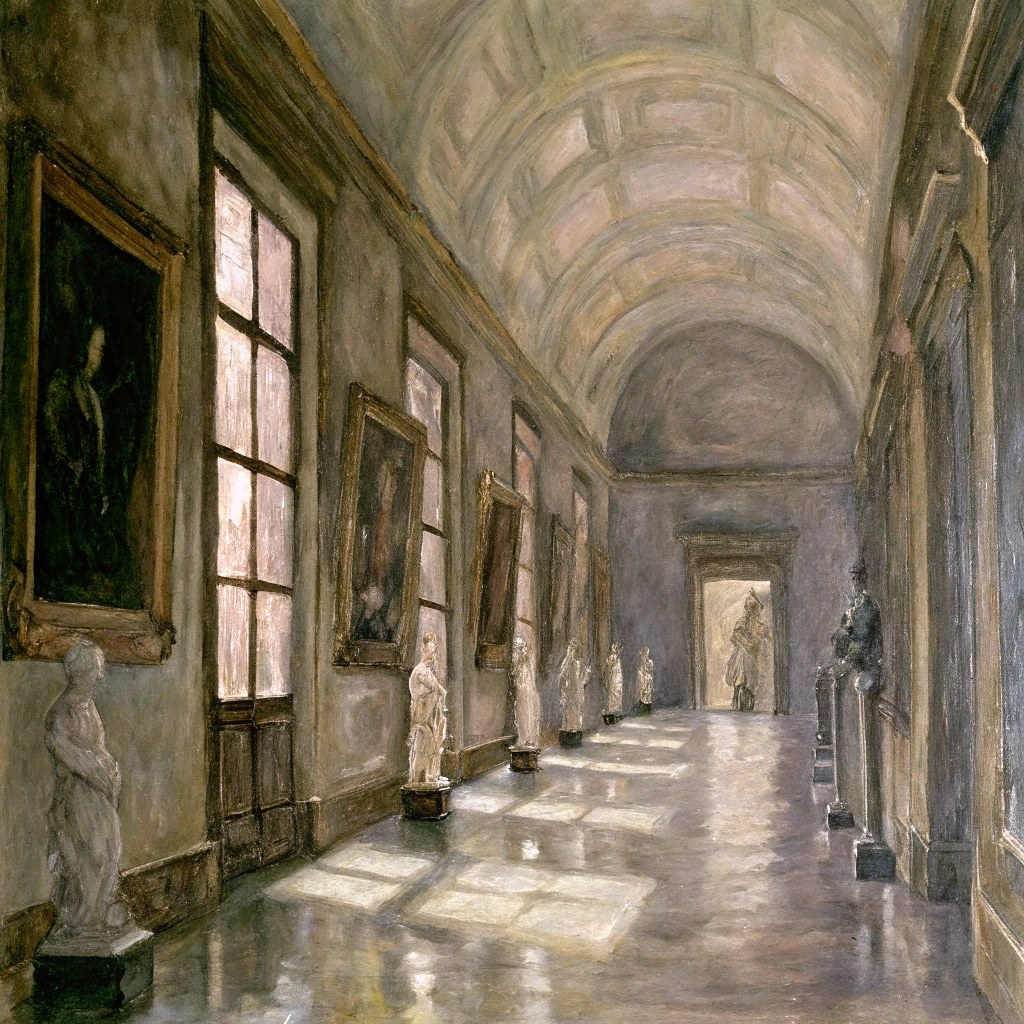
image_static_stylized_public_spaces_0008Suite: image_static Metric: feature_match_coverage Scene: stylized / public_spaces
Benchmark prompt
Camera orbit left. A gallery corridor with statues, paintings, and windows. Everything in the scene remains completely motionless.
source: generation_records
Higher: astra_image_static. Lower: matrix_game3_5s_image_static_dynamic. Labels compare feature_match_coverage only.
Higher metric score Score 0.4870 astra_image_static Feature-match coverage 48.7%
Lower metric score Score 0.0988 matrix_game3_5s_image_static_dynamic Feature-match coverage 9.9%
Input image
Same input and prompt · image_static · gap 0.0532
image_static_stylized_dining_spaces_0097Suite: image_static Metric: epipolar_error Scene: stylized / dining_spaces
Benchmark prompt
Camera pull out. Dining spaces with wooden table, chairs, and window with curtains. Everything in the scene remains completely motionless.
source: generation_records
Higher: cameractrl_image_static. Lower: dreamx_world_image_static. Labels compare epipolar_error only.
Higher metric score Score 0.9890 cameractrl_image_static Median inlier Sampson error 0.0549
Lower metric score Score 0.9358 dreamx_world_image_static Median inlier Sampson error 0.3209
Input image
Same input and prompt · image_static · gap 0.2484
image_static_stylized_dining_spaces_0041Suite: image_static Metric: epipolar_inlier_rate Scene: stylized / dining_spaces
Benchmark prompt
Camera pull out. A beachside path with sand, lanterns, and ocean. Camera pan left. A beachfront lounge with lounge chairs, palm trees, and ocean. Camera move left. A beach bar with bar counter, stools, and string lights.
source: generation_records
Higher: luciddreamer-image-static-8gpu-20260613_151844. Lower: longcat-video-image-static-8gpu-20260612_133950. Labels compare epipolar_inlier_rate only.
Higher metric score Score 0.9290 luciddreamer-image-static-8gpu-20260613_151844 Inlier rate 92.9%
Lower metric score Score 0.6806 longcat-video-image-static-8gpu-20260612_133950 Inlier rate 68.1%
Input image
Same input and prompt · image_static · gap 0.4055
image_static_stylized_suburb_0007Suite: image_static Metric: feature_match_coverage Scene: stylized / suburb
Benchmark prompt
Camera pull out. A path intersection with trees, benches, and people. Everything in the scene remains completely motionless.
source: generation_records
Higher: hy_worldplay_ar_image_test_balanced_5000_5s. Lower: dreamx_world_image_static. Labels compare feature_match_coverage only.
Higher metric score Score 0.4402 hy_worldplay_ar_image_test_balanced_5000_5s Feature-match coverage 44.0%
Lower metric score Score 0.0348 dreamx_world_image_static Feature-match coverage 3.5%
Input image
Same input and prompt · image_static · gap 0.0705
image_static_stylized_verdant_landscape_0087Suite: image_static Metric: epipolar_error Scene: stylized / verdant_landscape
Benchmark prompt
Camera pan left. A forest at sunset with trees, open field, and forest edge.
source: generation_records
Higher: longcat-video-image-static-8gpu-20260612_133950. Lower: ac3d-image-static. Labels compare epipolar_error only.
Higher metric score Score 1.0000 longcat-video-image-static-8gpu-20260612_133950 Median inlier Sampson error 0.0001
Lower metric score Score 0.9295 ac3d-image-static Median inlier Sampson error 0.3527
Input image
Same input and prompt · image_static · gap 0.4548
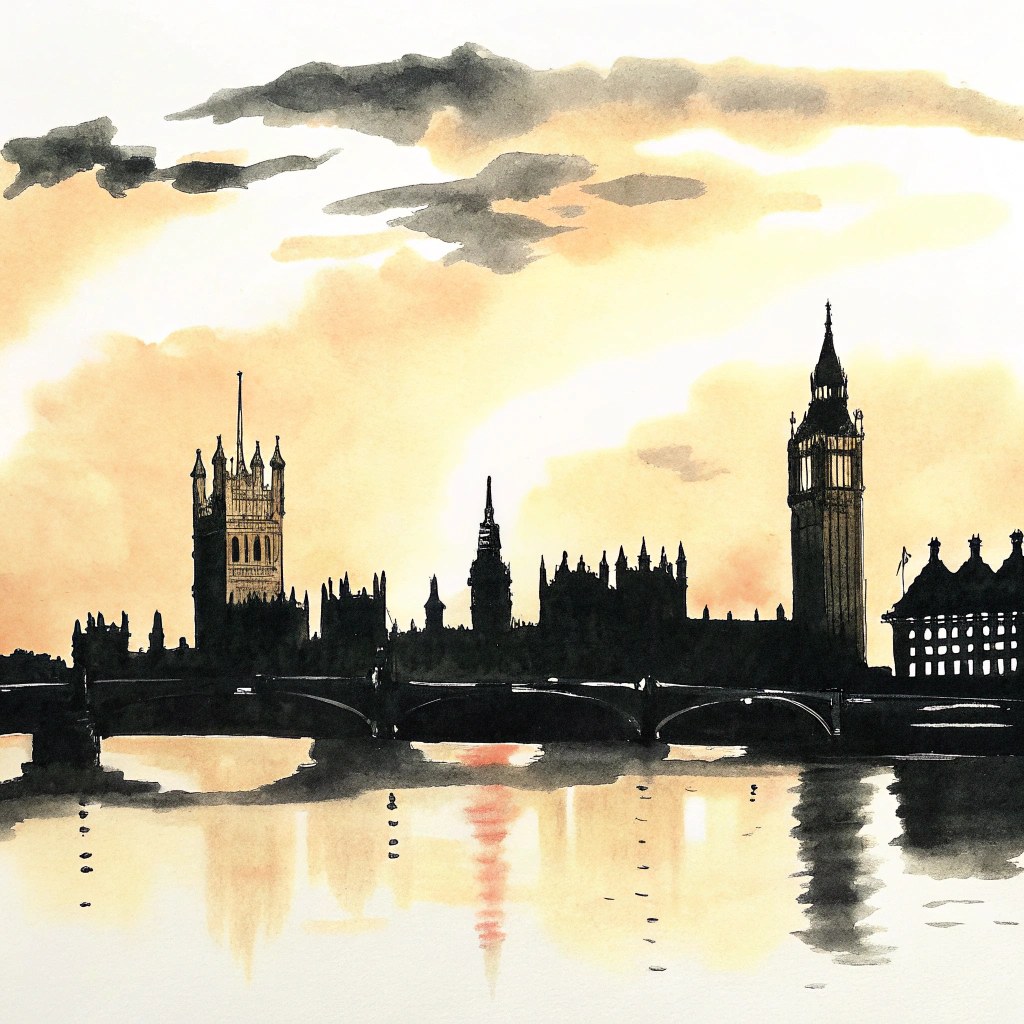
image_static_stylized_city_0021Suite: image_static Metric: epipolar_inlier_rate Scene: stylized / city
Benchmark prompt
Camera move right. A cityscape silhouette with towers, buildings, and bridge. Everything in the scene remains completely motionless.
source: generation_records
Higher: motionctrl_image_static_official_default_tmp2. Lower: astra_image_static. Labels compare epipolar_inlier_rate only.
Higher metric score Score 0.9696 motionctrl_image_static_official_default_tmp2 Inlier rate 97.0%
Lower metric score Score 0.5148 astra_image_static Inlier rate 51.5%
Input image
Same input and prompt · image_static · gap 0.0537
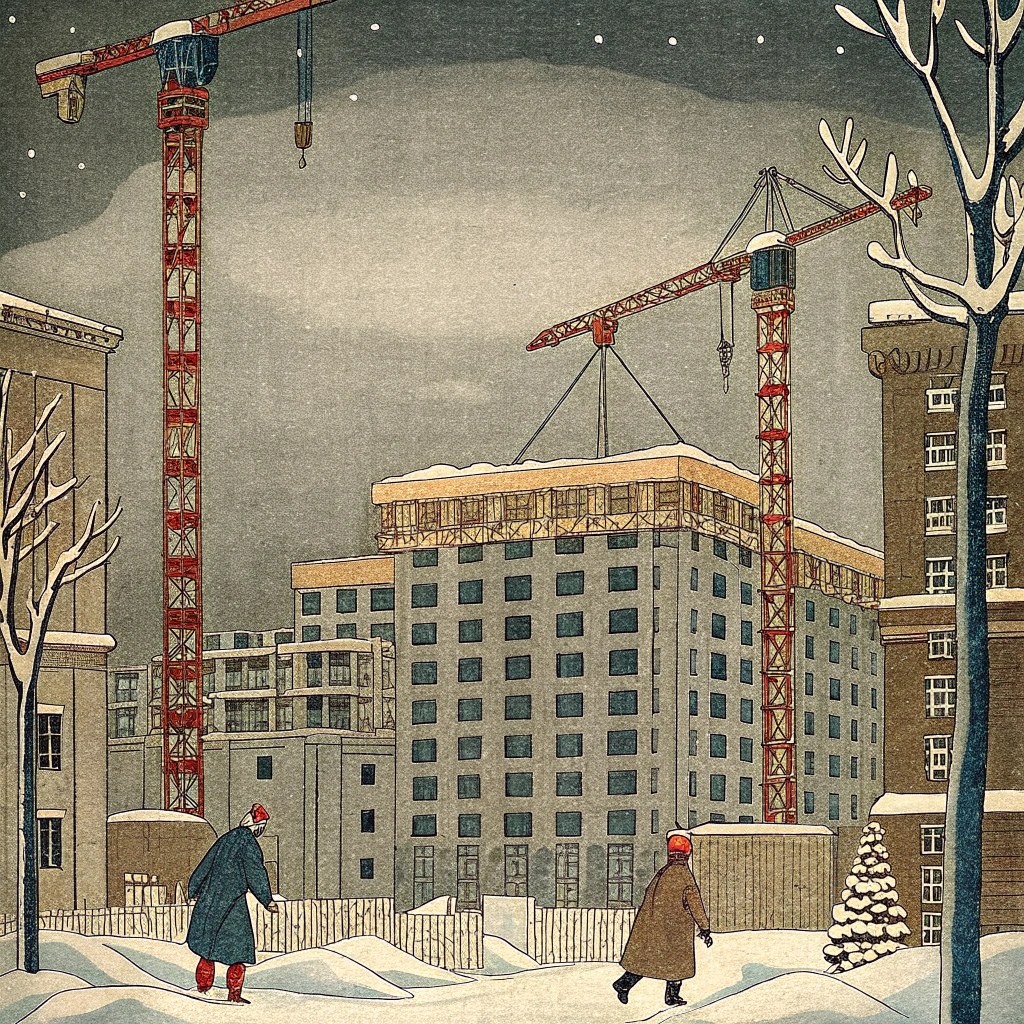
image_static_stylized_city_0051Suite: image_static Metric: epipolar_error Scene: stylized / city
Benchmark prompt
Camera pan right. A city construction site with street, snow, and cars.
source: generation_records
Higher: longcat-video-image-static-8gpu-20260612_133950. Lower: warp-as-history-image-static-8gpu-20260612_152000. Labels compare epipolar_error only.
Higher metric score Score 0.9920 longcat-video-image-static-8gpu-20260612_133950 Median inlier Sampson error 0.0399
Lower metric score Score 0.9383 warp-as-history-image-static-8gpu-20260612_152000 Median inlier Sampson error 0.3087
Input image
Same input and prompt · image_static · gap 0.2243
image_static_stylized_aquatic_landscape_0123Suite: image_static Metric: epipolar_inlier_rate Scene: stylized / aquatic_landscape
Benchmark prompt
Camera pan left. Dense trees with stone pathway and lake. Everything in the scene remains completely motionless.
source: generation_records
Higher: hy_worldplay_ar_distilled_image_test_balanced_5000_5s. Lower: motionctrl_image_static_official_default_tmp2. Labels compare epipolar_inlier_rate only.
Higher metric score Score 0.9741 hy_worldplay_ar_distilled_image_test_balanced_5000_5s Inlier rate 97.4%
Lower metric score Score 0.7498 motionctrl_image_static_official_default_tmp2 Inlier rate 75.0%
Sora Generates Videos with Stunning Geometrical Consistency
Xuanyi Li, Daquan Zhou, Chenxu Zhang, Shaodong Wei, Qibin Hou, and Ming-Ming Cheng.https://arxiv.org/abs/2402.17403
BibTeX @article { XuanyiLI2024Sora ,
title = { Sora Generates Videos with Stunning Geometrical Consistency } ,
author = { Xuanyi Li and Daquan Zhou and Chenxu Zhang and Shaodong Wei and Qibin Hou and Ming-Ming Cheng } ,
journal = { arXiv preprint arXiv:2402.17403 } ,
url = { https://arxiv.org/abs/2402.17403 } ,
Multiple View Geometry in Computer Vision
Hartley & Zisserman, Cambridge University Press, 2004.