An official time-aligned trajectory-shape metric with activity penalties. Constant-action segments are split at observation gaps; native interval errors are time weighted. Evaluation uses neither arc-length resampling nor whole-track time stretching.
S t r a j = 1 − n A T E ‾ { commanded or observed axes } (1) S_{\mathrm{traj}}
=
1 - \overline{\mathrm{nATE}}_{\{\text{commanded or observed axes}\}}
\tag{1} S traj = 1 − nATE { commanded or observed axes } ( 1 ) The component errors are nATEt and nATEr . Excluding an uncommanded stationary axis prevents it from diluting failure on an active axis. A completely idle trajectory has a value of 1; that is not evidence of active motion control.
Higher is better. Targets use the prediction’s segment amplitude (amplitude_calibrated=false), so this is not independent target-trajectory accuracy: a direction-correct half-speed rollout can score well. Freezes and delays are penalized using native-time shape and activity errors. Backend: pose_action; official metric.
Audit manifest: docs/assets/metric_examples/longseq_memory_60s_examples_20260909.json.
Input image
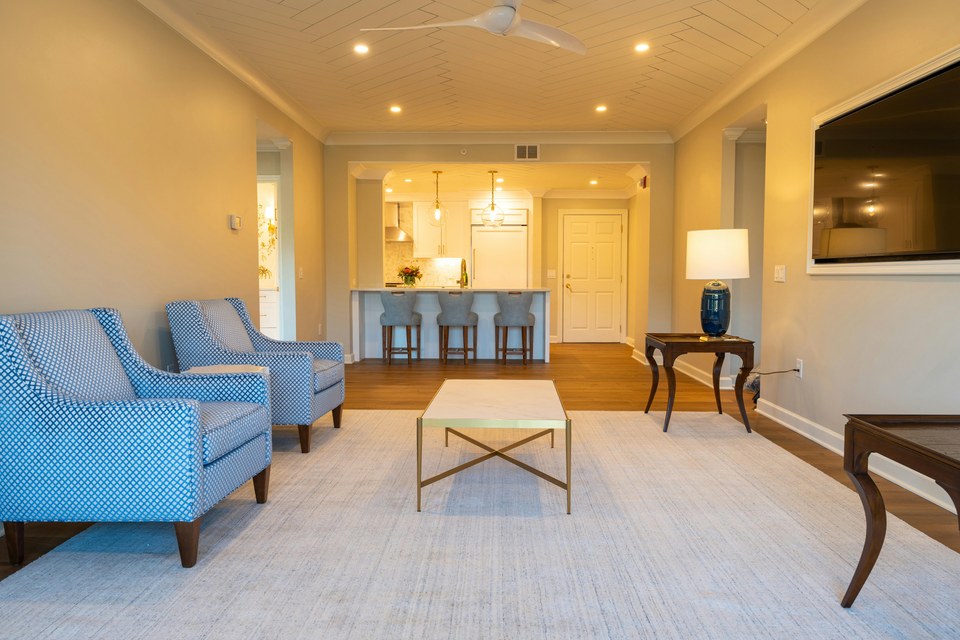
60s memory_loop · illustrative same input
memory-dolly_loop-memory_pool_408Suite: memory_loop Scene: photorealistic / indoor / living_spaces
Benchmark prompt target
Move the camera forward through the scene, then back to where it started.
prompt source: memory_loop_prompt
Compare each 60s output with the requested path. These same-input videos illustrate motion behavior; this case has no official trajectory score.
Output A keystroke_traj_score
Output B keystroke_traj_score
Input image
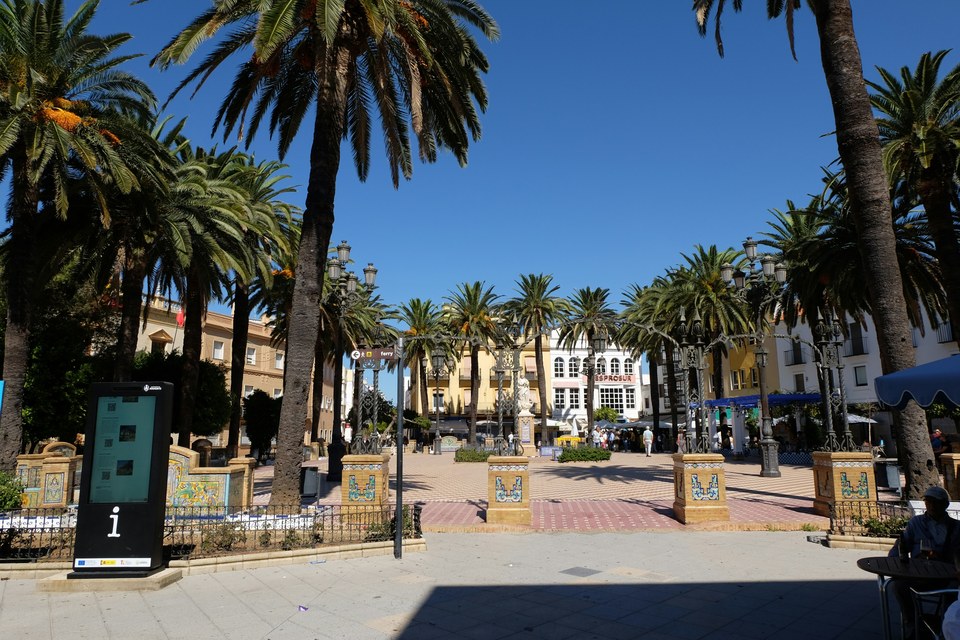
60s memory_loop · illustrative same input
memory-yaw_loop_360-memory_pool_028Suite: memory_loop Scene: photorealistic / outdoor / city
Benchmark prompt target
Rotate the camera a full turn in place and come back to the starting view.
prompt source: memory_loop_prompt
Compare each 60s output with the requested path. These same-input videos illustrate motion behavior; this case has no official trajectory score.
Output A keystroke_traj_score
Output B keystroke_traj_score
Input image
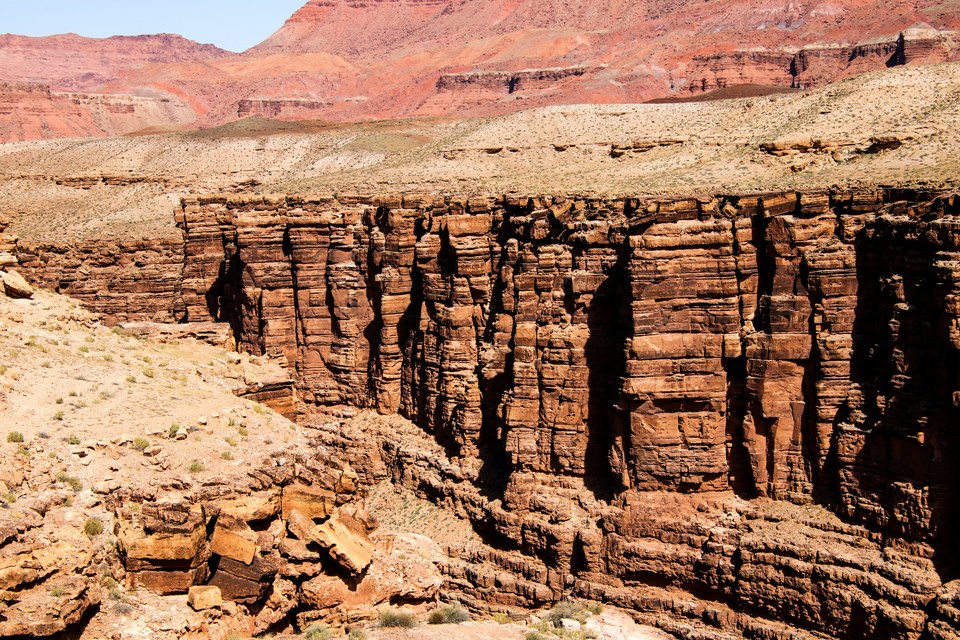
60s memory_loop · illustrative same input
memory-palindrome_loop-memory_pool_003Suite: memory_loop Scene: photorealistic / outdoor / terrestrial_landscape
Benchmark prompt target
Move forward, turn and continue, then retrace the whole path back.
prompt source: memory_loop_prompt
Compare each 60s output with the requested path. These same-input videos illustrate motion behavior; this case has no official trajectory score.
Output A keystroke_traj_score
Output B keystroke_traj_score
Input image
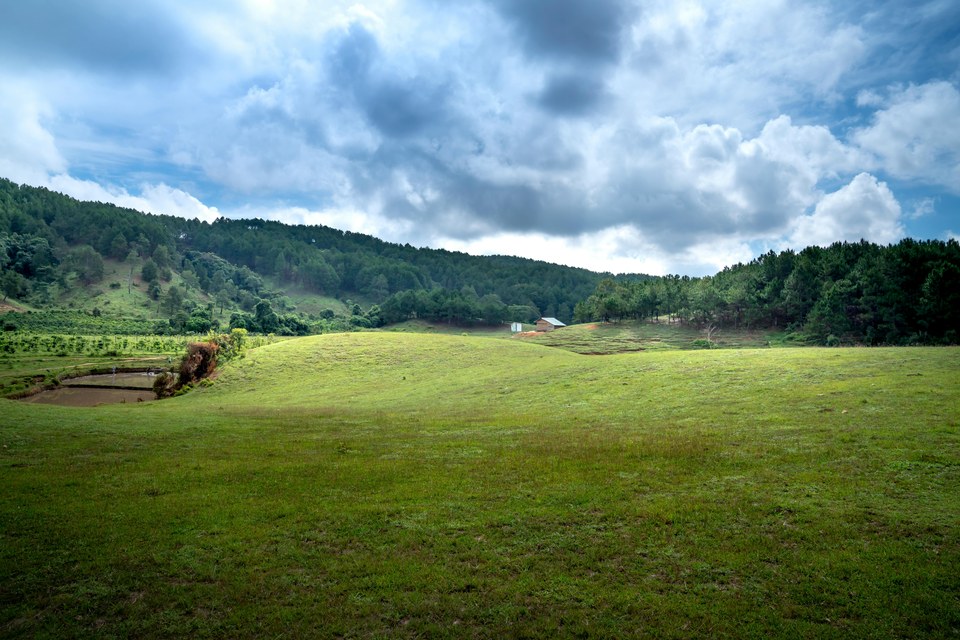
60s memory_loop · illustrative same input
memory-yaw_loop_180-memory_pool_249Suite: memory_loop Scene: photorealistic / outdoor / verdant_landscape
Benchmark prompt target
Turn the camera to the right, then turn back to the starting view.
prompt source: memory_loop_prompt
Compare each 60s output with the requested path. These same-input videos illustrate motion behavior; this case has no official trajectory score.
Output A keystroke_traj_score
Output B keystroke_traj_score
Input image
60s memory_loop · illustrative same input
memory-dolly_loop-memory_pool_463Suite: memory_loop Scene: photorealistic / outdoor / terrestrial_landscape
Benchmark prompt target
Move the camera forward through the scene, then back to where it started.
prompt source: memory_loop_prompt
Compare each 60s output with the requested path. These same-input videos illustrate motion behavior; this case has no official trajectory score.
Output A keystroke_traj_score
Output B keystroke_traj_score