Skip to content

Optical Flow AEPE

Leaderboard scoring is 100 × mean(clip(1 - raw_i / 1.192, 0, 1)): clip and score each video before averaging. Report error_ref values remain compatibility inputs; their mean is never inverted to recover raw measurements. Historical published summaries without matching per-video evidence are identified in score tooltips.

Optical Flow AEPE quantifies short-horizon photometric consistency in a generated video via forward–backward optical-flow round trips. It measures whether local appearance remains stable across consecutive frames—not whether motion matches ground truth.

For adjacent frames AA and BB, sample points pA,ip_{A,i} in a center crop. Forward flow FA→BF_{A\to B} tracks each point to pB,i=pA,i+FA→B(pA,i)p_{B,i} = p_{A,i} + F_{A\to B}(p_{A,i}); backward flow returns pA,i′=pB,i+FB→A(pB,i)p'_{A,i} = p_{B,i} + F_{B\to A}(p_{B,i}). The per-pair average end-point error is

eAEPE=1N∑i=1N∥pA,i−pA,i′∥2(1)e_{\mathrm{AEPE}} = \frac{1}{N}\sum_{i=1}^{N} \left\| p_{A,i} - p'_{A,i} \right\|_2 \tag{1}

The raw score averages eAEPEe_{\mathrm{AEPE}} over all consecutive frame pairs. WorldAtlas reverse-normalizes with empirical range [0,1.192][0, 1.192]. Lower error (higher normalized score) indicates more stable local appearance. The metric is official when SEA-RAFT computation succeeds.

Audit manifest: docs/assets/metric_examples/curated_same_case_manifest.json.

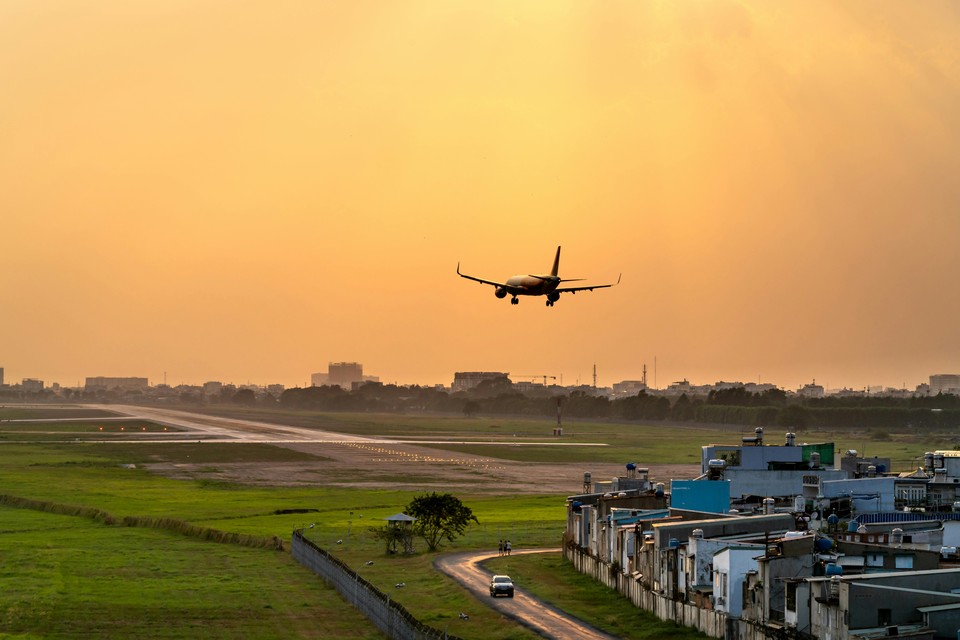
Input image: image_dynamic_photorealistic_rigid_0077
Input image
Input verified · same benchmark case · gap 0.3208

image_dynamic_photorealistic_rigid_0077

Suite: image_dynamicScene: photorealistic / rigid
Benchmark prompt target

An airplane descends toward the runway under a warm orange sunset sky, its landing gear extended and body steady.

prompt source: prompt_target

Both first frames passed geometric matching against the displayed input; labels compare this metric only.

Model result videos will be available with the ModelScope release. / 模型推理视频将在 ModelScope 方案上线后提供。

Higher metric scoreScore 0.9362

Model result videos will be available with the ModelScope release. / 模型推理视频将在 ModelScope 方案上线后提供。

Lower metric scoreScore 0.6154
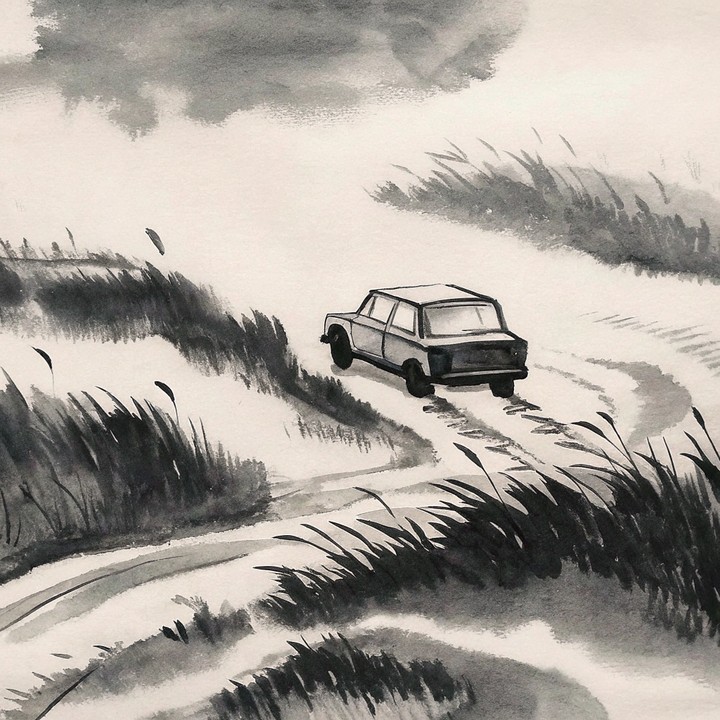
Input image: image_dynamic_stylized_multi_motion_0114
Input image
Input verified · same benchmark case · gap 0.3204

image_dynamic_stylized_multi_motion_0114

Suite: image_dynamicScene: stylized / multi_motion
Benchmark prompt target

The car drives away along the winding dirt road, its stable body following the curve and leaving tire tracks behind. Tall grass on both sides sways gently under the overcast sky.

prompt source: prompt_target

Both first frames passed geometric matching against the displayed input; labels compare this metric only.

Model result videos will be available with the ModelScope release. / 模型推理视频将在 ModelScope 方案上线后提供。

Higher metric scoreScore 0.9341

Model result videos will be available with the ModelScope release. / 模型推理视频将在 ModelScope 方案上线后提供。


Lower metric scoreScore 0.6138
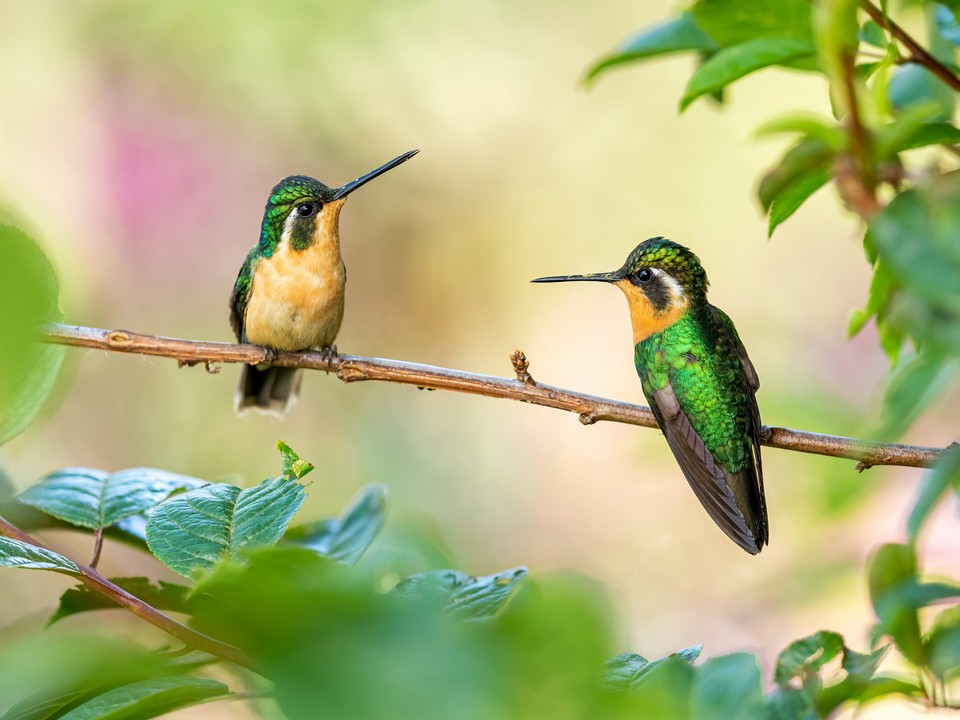
Input image: image_dynamic_photorealistic_articulated_0009
Input image
Input verified · same benchmark case · gap 0.3211

image_dynamic_photorealistic_articulated_0009

Suite: image_dynamicScene: photorealistic / articulated
Benchmark prompt target

Two hummingbirds perch facing each other on the slender branch, making tiny head turns and body adjustments.

prompt source: prompt_target

Both first frames passed geometric matching against the displayed input; labels compare this metric only.

Model result videos will be available with the ModelScope release. / 模型推理视频将在 ModelScope 方案上线后提供。
Higher metric scoreScore 0.8819

Model result videos will be available with the ModelScope release. / 模型推理视频将在 ModelScope 方案上线后提供。
Lower metric scoreScore 0.5608